
Minimum-Snap Trajectory
Problem Statement
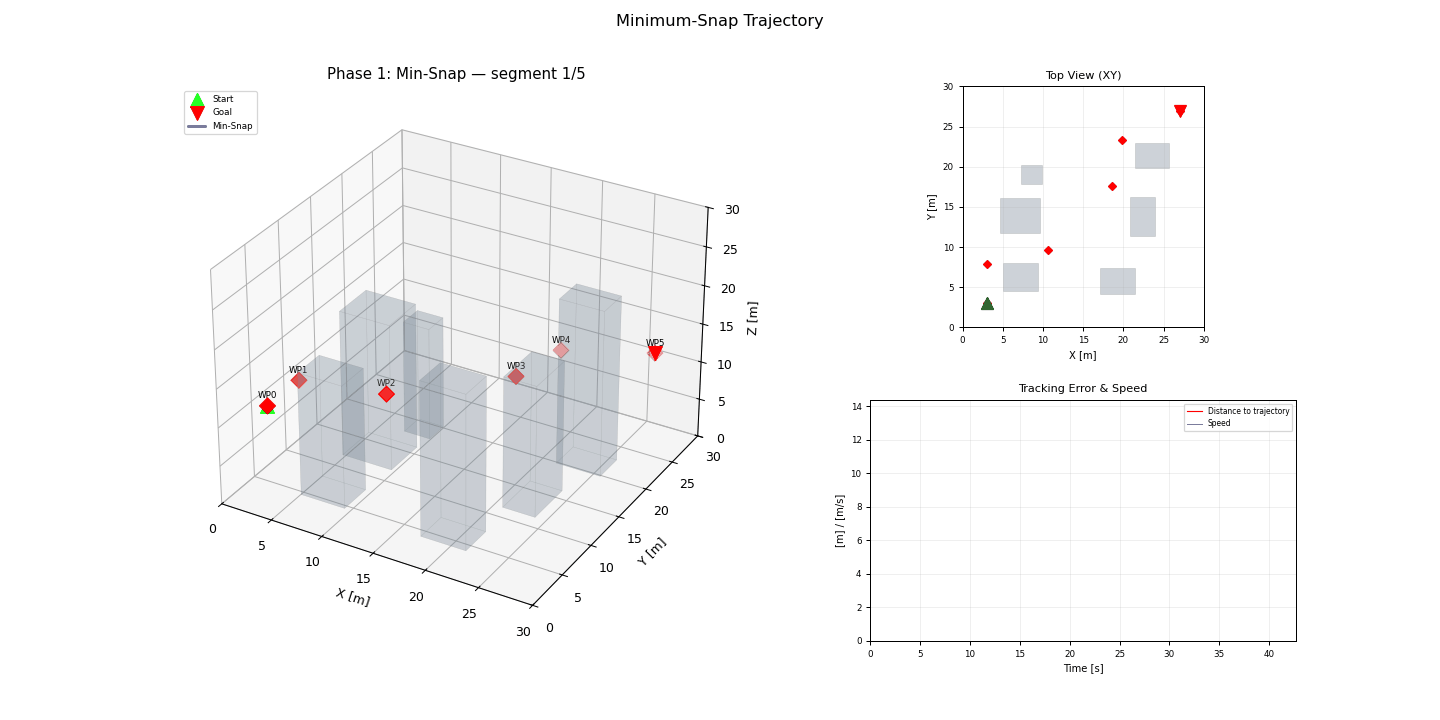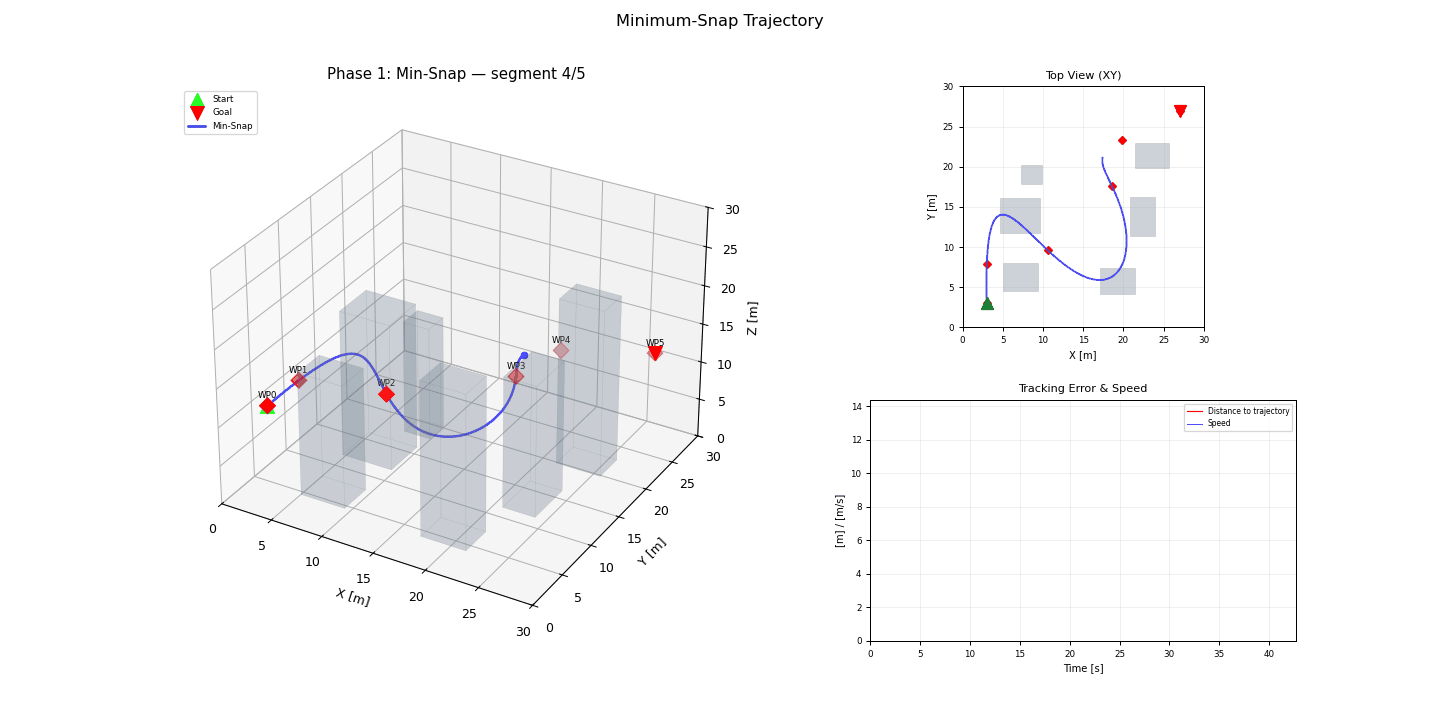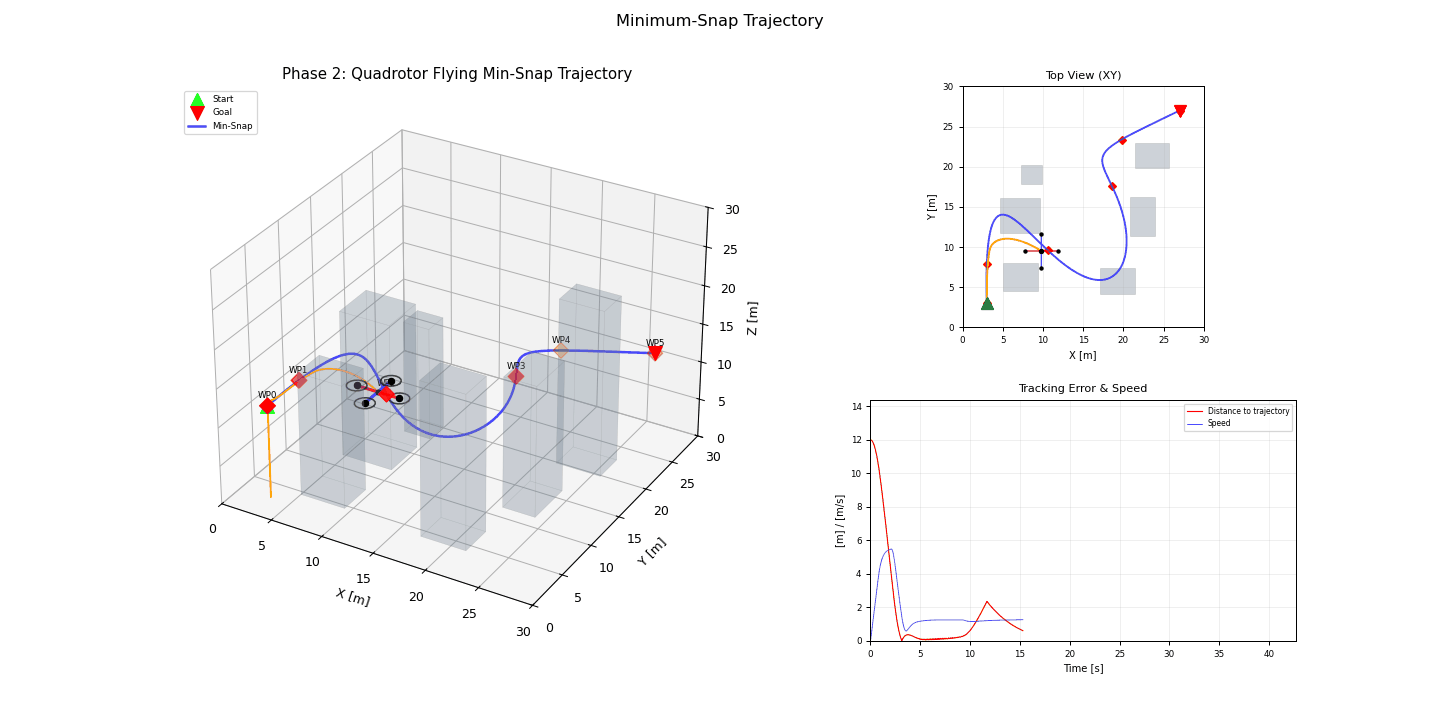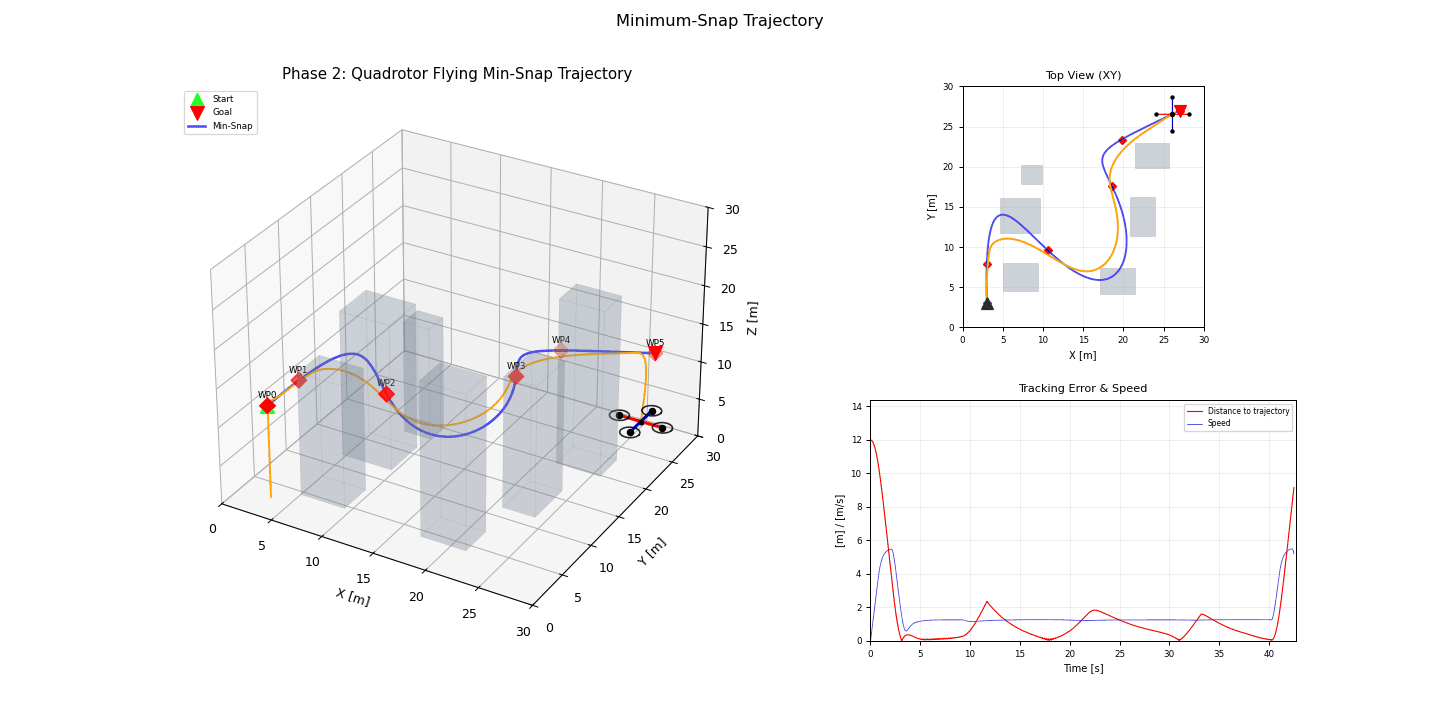
Waypoint-only paths are not directly flyable because they ignore high-order dynamic smoothness. Minimum-snap planning computes polynomial trajectories that reduce aggressive jerk/snap behavior and improve tracking performance.
Model and Formulation
Each segment is represented by a polynomial:
The optimization minimizes integrated snap:
subject to waypoint and continuity constraints for position, velocity, acceleration, and jerk.
Algorithm Procedure
- Allocate segment times across waypoints.
- Build quadratic cost matrix for snap objective.
- Apply boundary and continuity equality constraints.
- Solve constrained QP for polynomial coefficients.
Tuning Guidance
- Time allocation dominates smoothness-quality trade-offs.
- Enforce corridor constraints for cluttered environments.
- Increase continuity order for aggressive maneuvers with tight tracking budgets.
Failure Modes and Diagnostics
A min-snap trajectory through sparse waypoints can loop back close to itself. That is fine for the trajectory and hostile to a naive tracker: the look-ahead sphere keeps intersecting an earlier segment and the vehicle circles behind its own carrot forever. See pure pursuit for the arc-length progress window that fixes it.
Segment times that are too short for the distance demand accelerations the vehicle cannot produce; the polynomial is still optimal, just infeasible.
Unrealistic segment times create numerically stiff trajectories.
Sparse waypoints can violate obstacle-clearance assumptions.
Overly smooth trajectories may become too conservative for time-critical tasks.
Implementation and Execution
python -m flybots.simulations.trajectory_planning.min_snapEvidence
References
- Mellinger and Kumar, Minimum Snap Trajectory Generation and Control for Quadrotors (2011)
- Richter, Bry, Roy, Polynomial Trajectory Planning for Aggressive Quadrotor Flight (2016)