Flight Operations Demo
Problem Statement
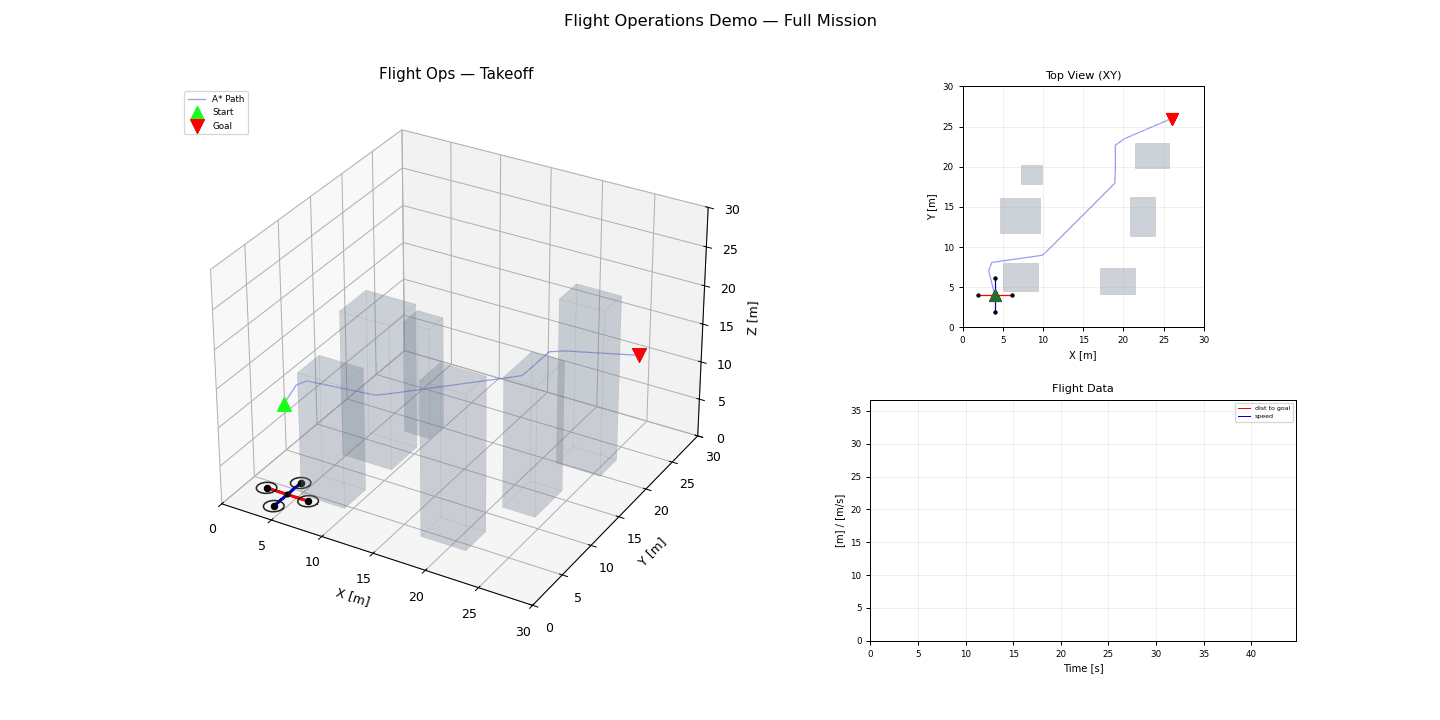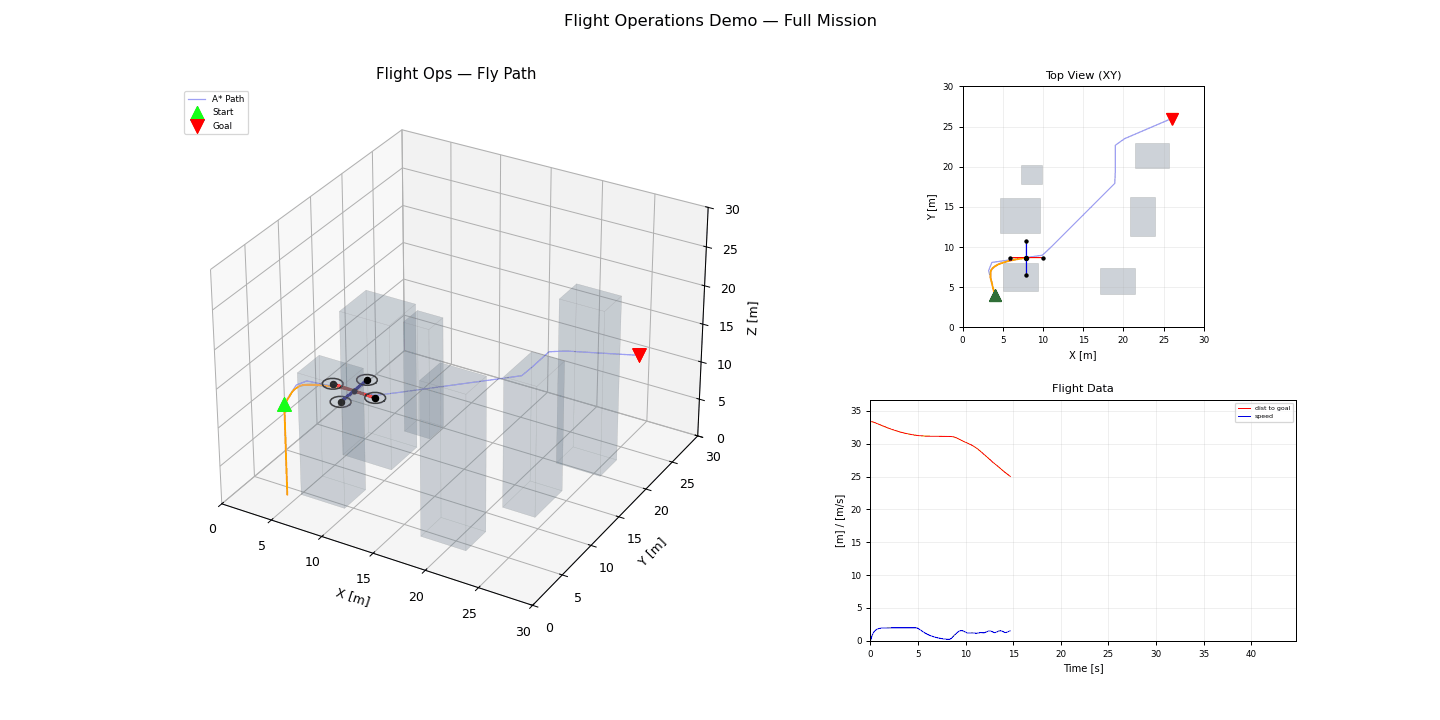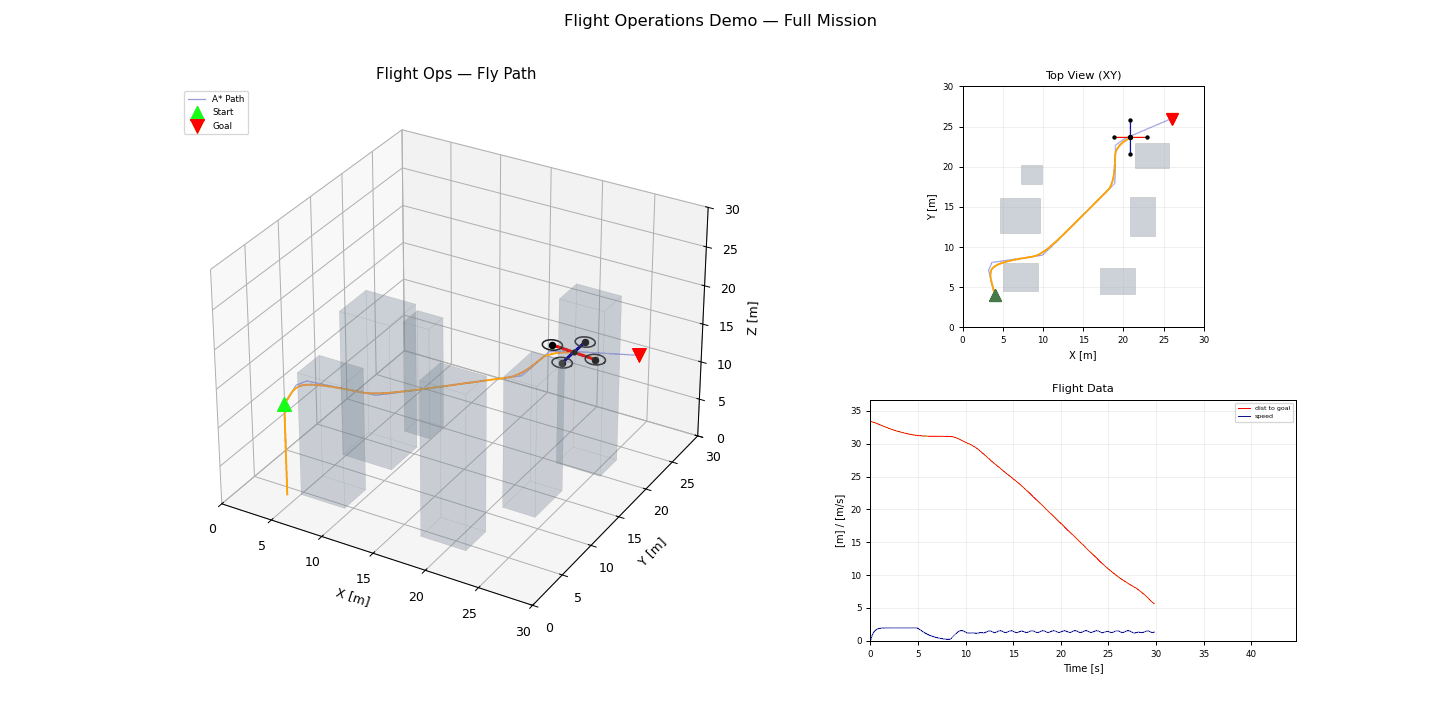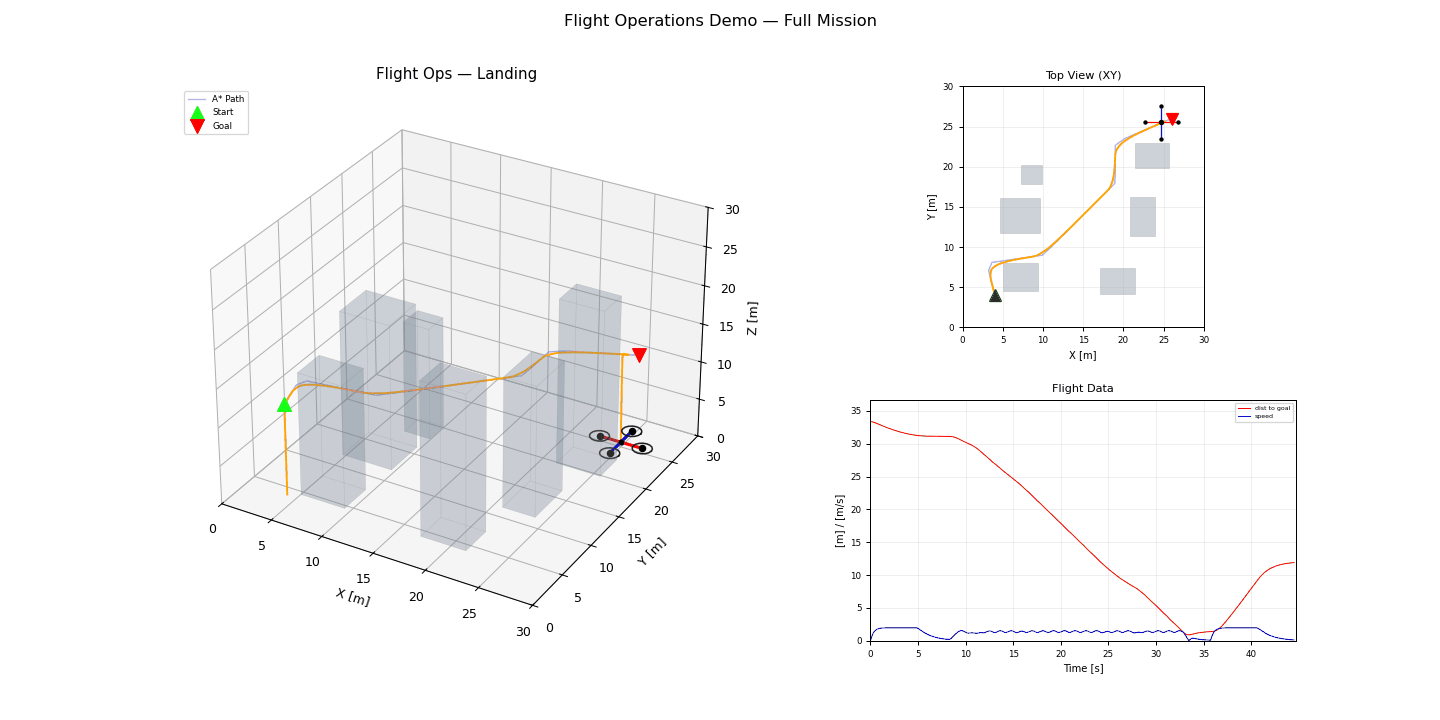
This article documents a mission-level execution chain where multiple algorithms are composed into a complete sortie: arming, takeoff, offboard navigation, loiter, and landing.
System Composition
The workflow combines:
- state-estimation updates for localization
- path planning for global route generation
- path tracking for local command execution
- state machine transitions for operation safety
Mission-State Formulation
The behavior is modeled as a finite-state machine:
Transition guards depend on altitude thresholds, waypoint completion, and velocity limits.
Operational Procedure
- Verify arming and estimator health checks.
- Execute controlled takeoff to mission altitude.
- Follow planned route in OFFBOARD mode.
- Hold terminal position in LOITER.
- Execute descent and disarm sequence.
Failure Modes and Diagnostics
- Mode thrashing can occur if transition guards are too loose.
- Offboard timeout protection must override stale commands.
- Landing requires robust vertical-speed limits to avoid hard touchdown.
Implementation and Execution
bash
python -m flybots.simulations.path_tracking.flight_ops_demoEvidence