Geofence and Floor
Problem Statement
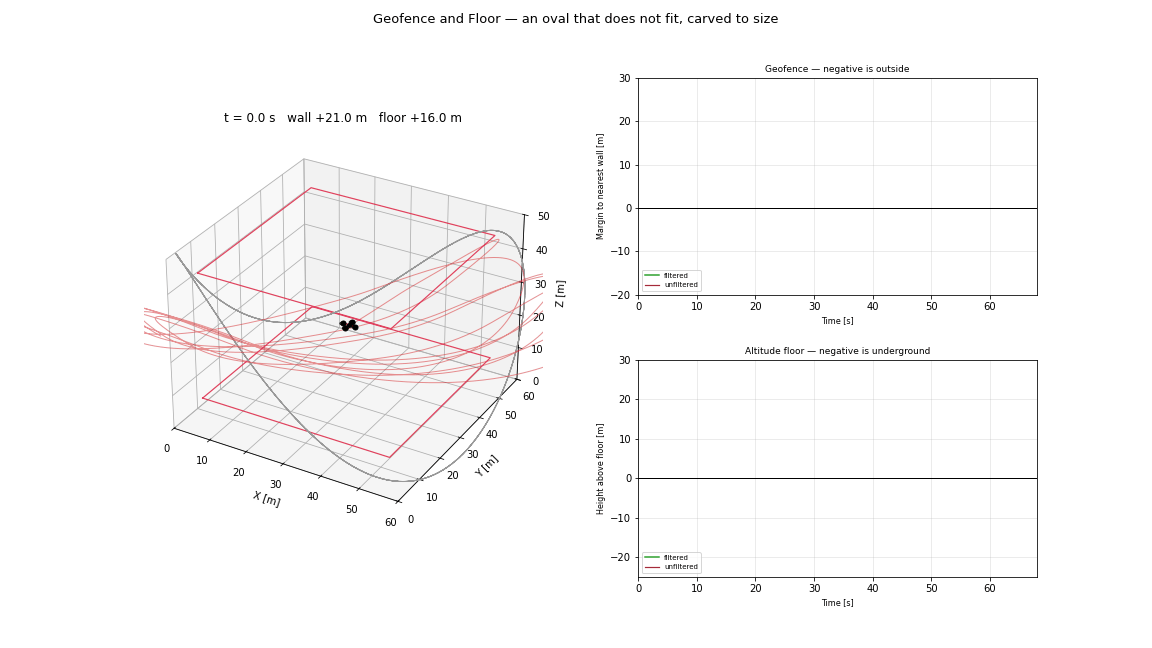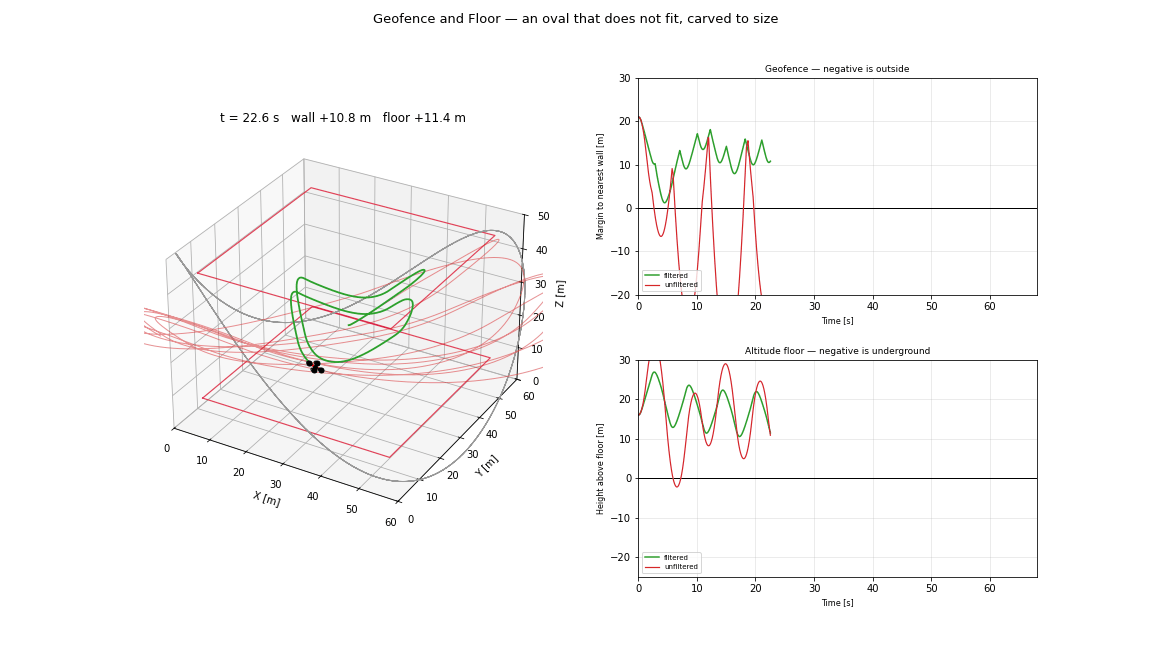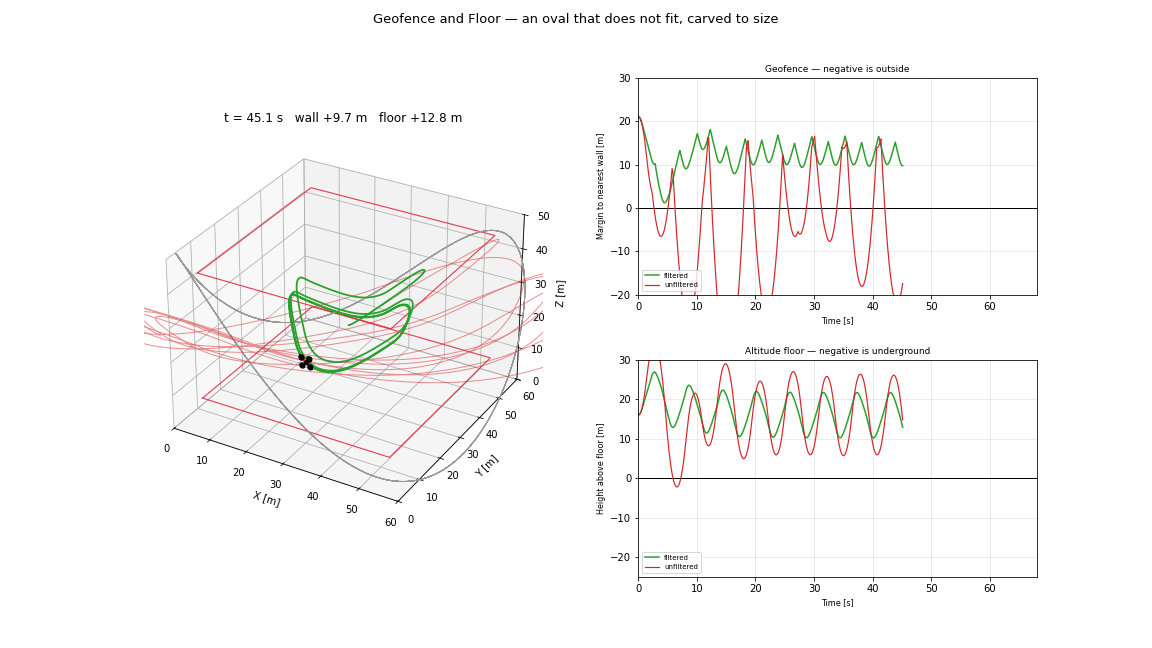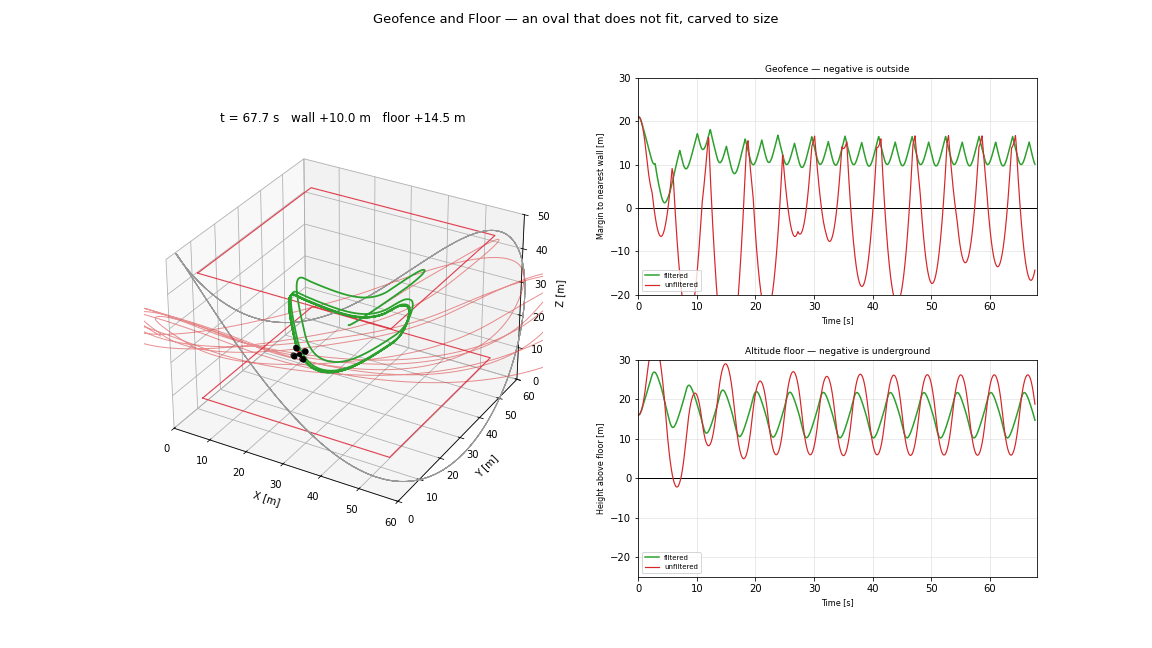
The nominal command does the two things a geofence exists to prevent: flat out at the boundary, then a dive at the ground. Two barriers refuse it.
Model and Formulation
Each box face and the altitude floor is its own barrier on position, so the input reaches them only through the second derivative. The filter therefore begins decelerating well before the limit rather than clamping at it.
A clamp is not a safety guarantee. It is a report that safety was already lost, and the unfiltered run shows what that looks like.
Tuning and Failure Modes
- Do not post-clip. Clipping a solved command can push it back across a barrier the QP had just satisfied; actuator limits belong in the QP.
- The class-K gains set how early the deceleration starts. Too soft and the vehicle overshoots on a fast approach; too stiff and it refuses to approach the boundary at all.
Evidence
| run | min wall margin | min floor margin |
|---|---|---|
| filtered | +0.00 m | +0.00 m |
| unfiltered | −13463 m | −4481 m |