
RRT* 3D
Problem Statement
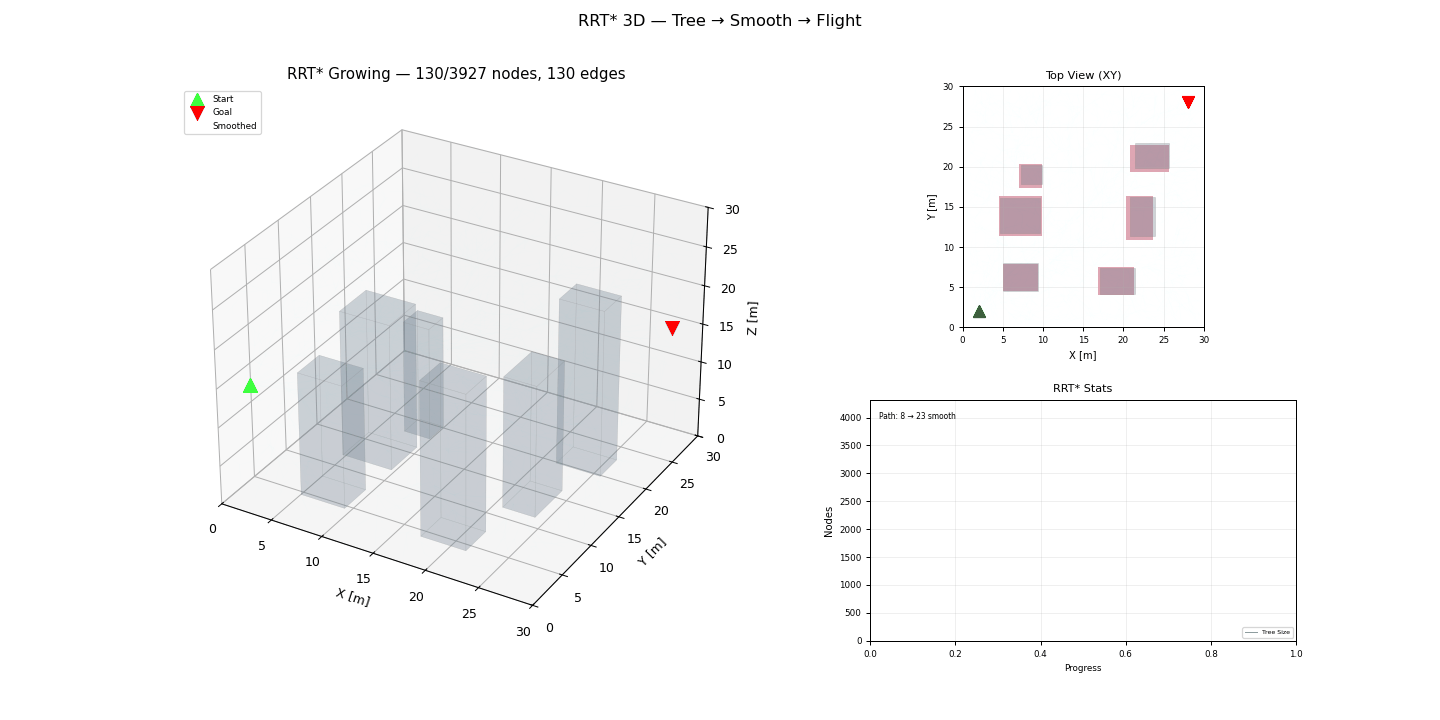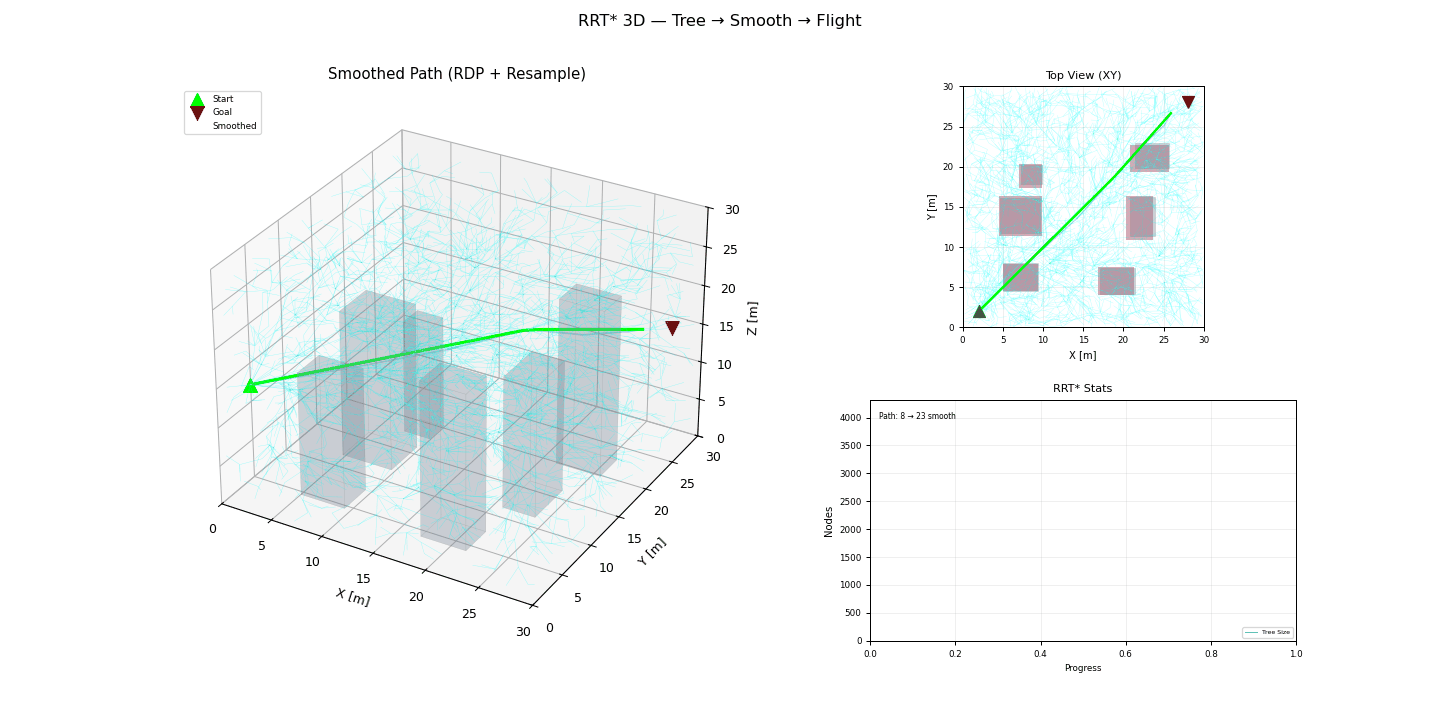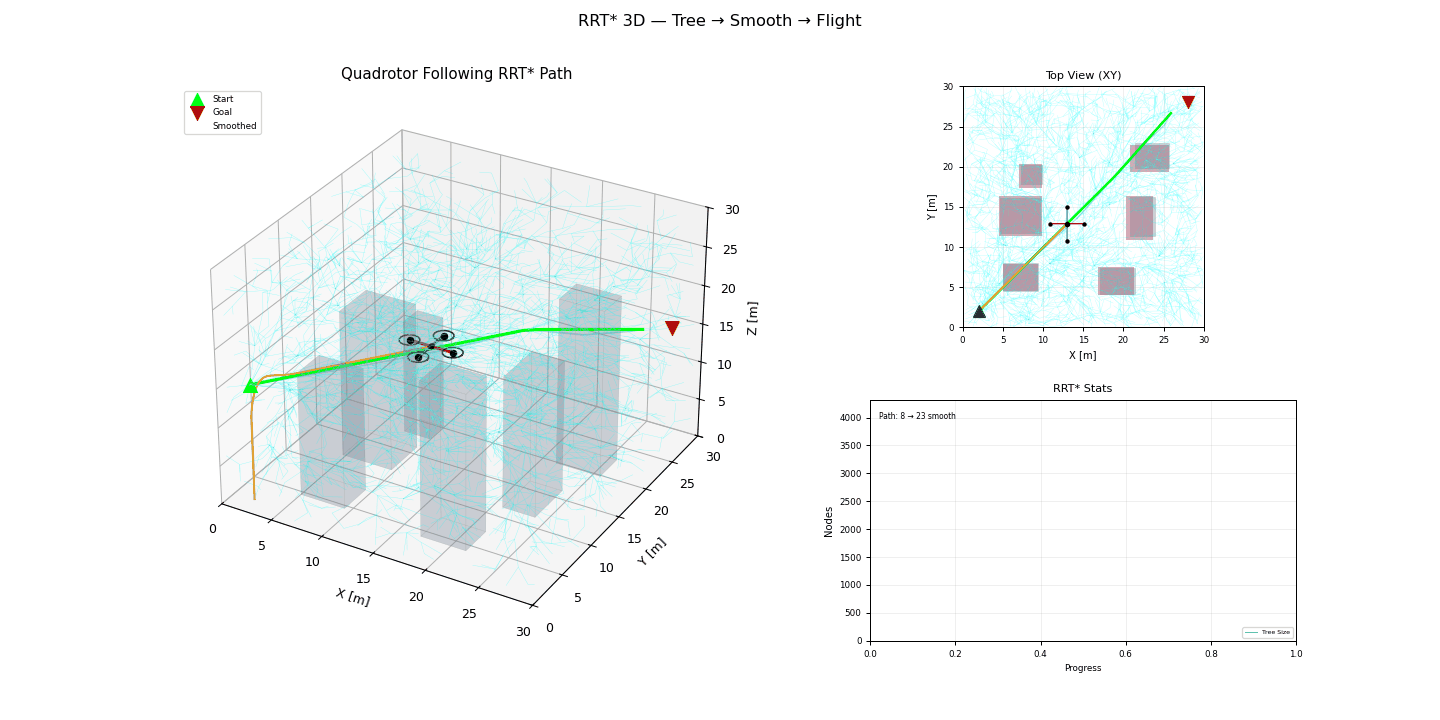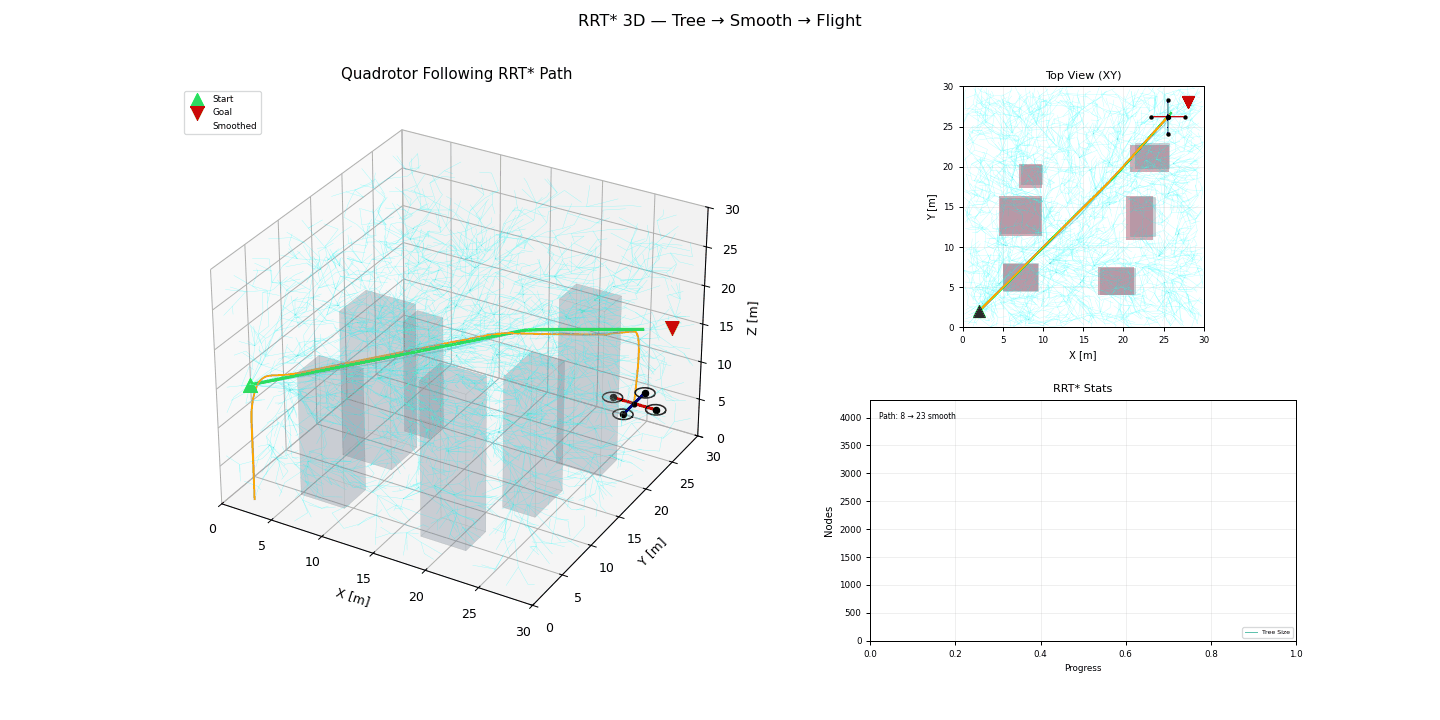
RRT* incrementally builds a tree in continuous space and asymptotically improves path cost through rewiring.
Model and Formulation
At each iteration:
- Sample random state
x_rand - Extend nearest node toward sample
- Choose parent minimizing local cost
- Rewire neighbors if new path improves their cost
As iterations grow, solution cost converges toward optimal.
Practical Notes
- Goal bias improves convergence speed.
- Step size controls exploration granularity.
- Collision checks dominate runtime.
Implementation and Execution
bash
python -m flybots.simulations.path_planning.rrt_star_3dEvidence
References
- Karaman and Frazzoli, Sampling-based Algorithms for Optimal Motion Planning (2011)
- Lavalle and Kuffner, Rapidly-exploring Random Trees