
Algorithm atlas
Every algorithm in the library has a runnable simulation that renders a three-panel animation, writes a JSON log, and cites its source.
flybots list                 # browse the catalogue
flybots info astar_3d        # references and usage for one
flybots run astar_3d         # render it
Or as a module: python -m flybots.simulations.<category>.<name>.
Reading order
Estimation → control and tracking → planning → perception → swarm. Each builds on the state representation the previous one establishes.
Vehicles
| Algorithm | Article | Preview |
|---|---|---|
| Quadrotor dynamics | Open |  |
| Fixed-wing flight | Open |  |
| VTOL transition | Open |  |
See also the model documentation: quadrotor, fixed-wing, VTOL.
Estimation
| Algorithm | Article | Preview |
|---|---|---|
| Complementary filter | Open |  |
| Extended Kalman filter | Open | 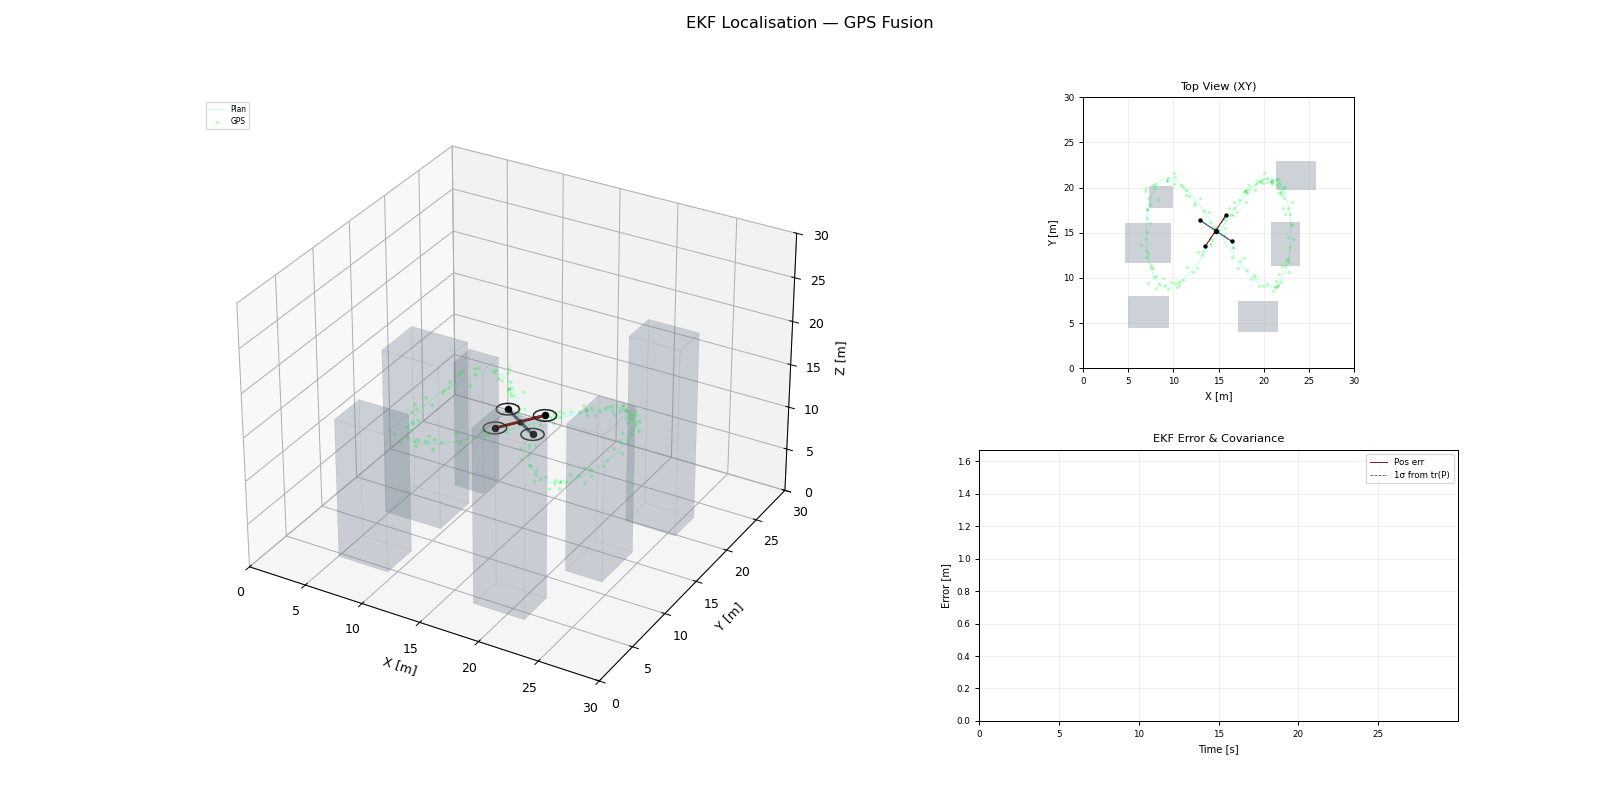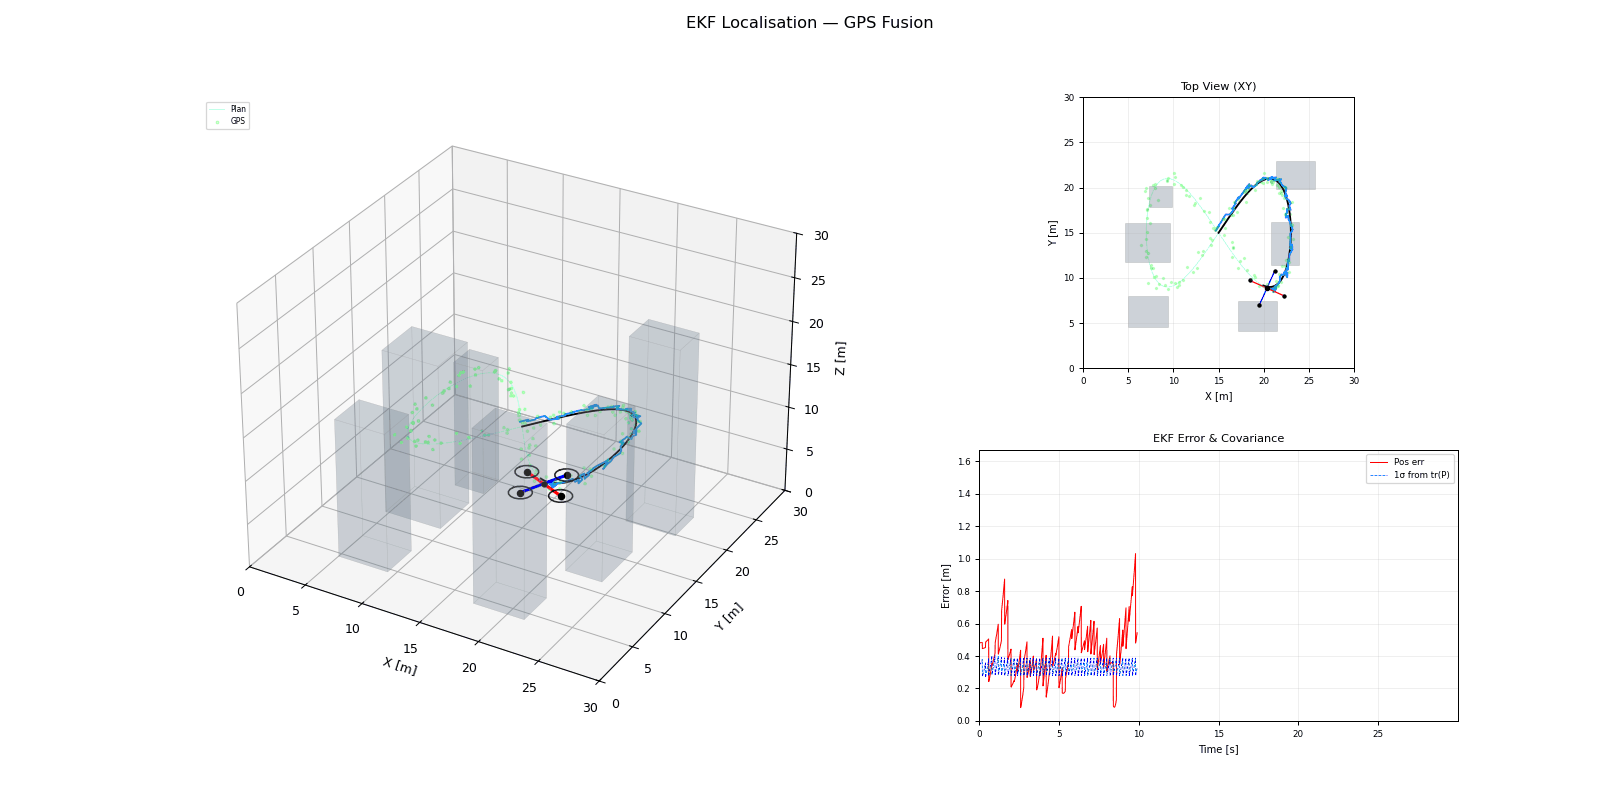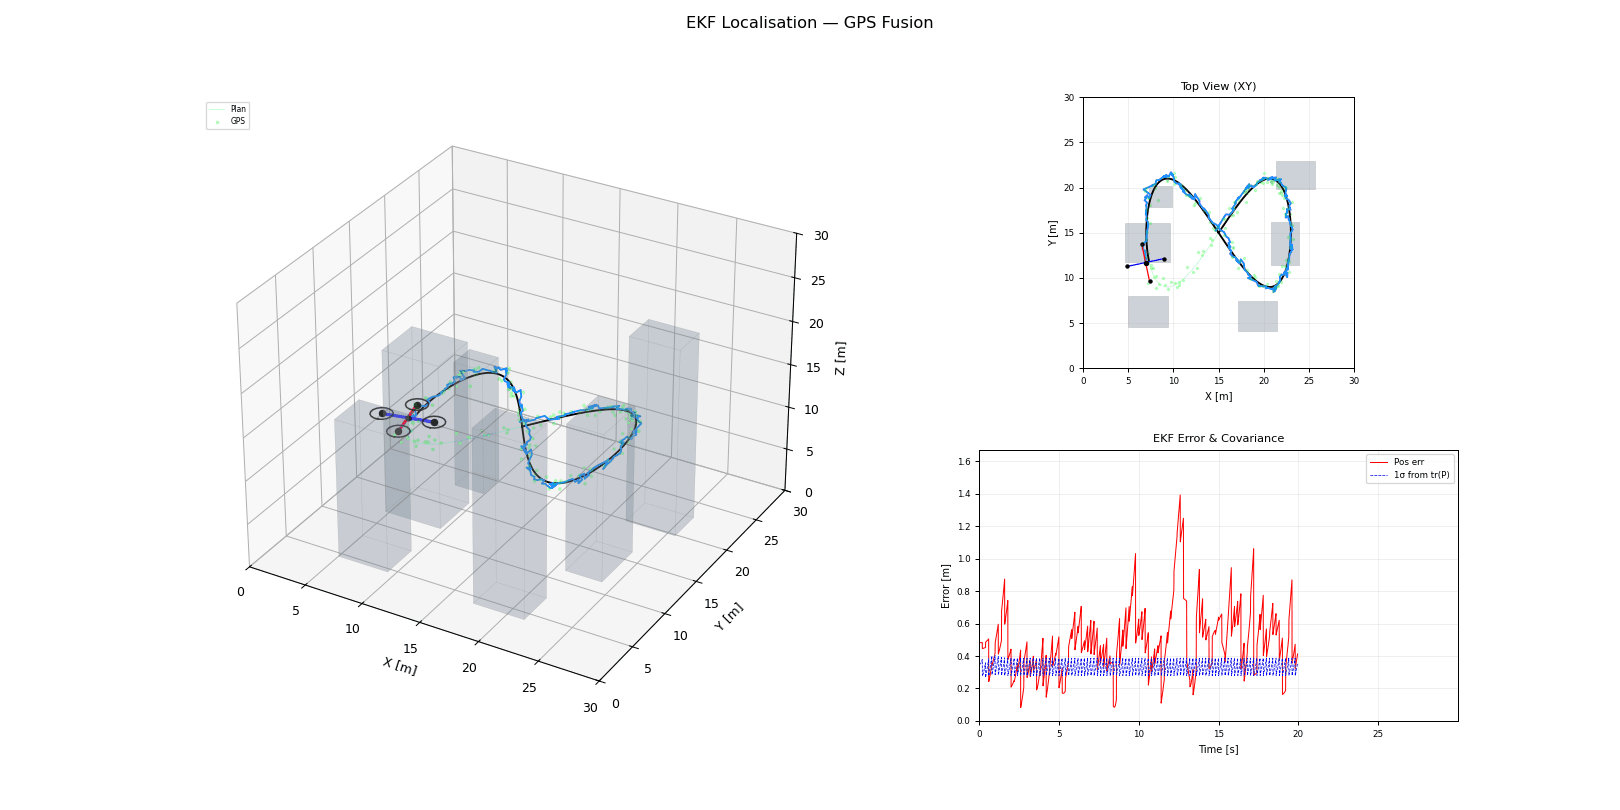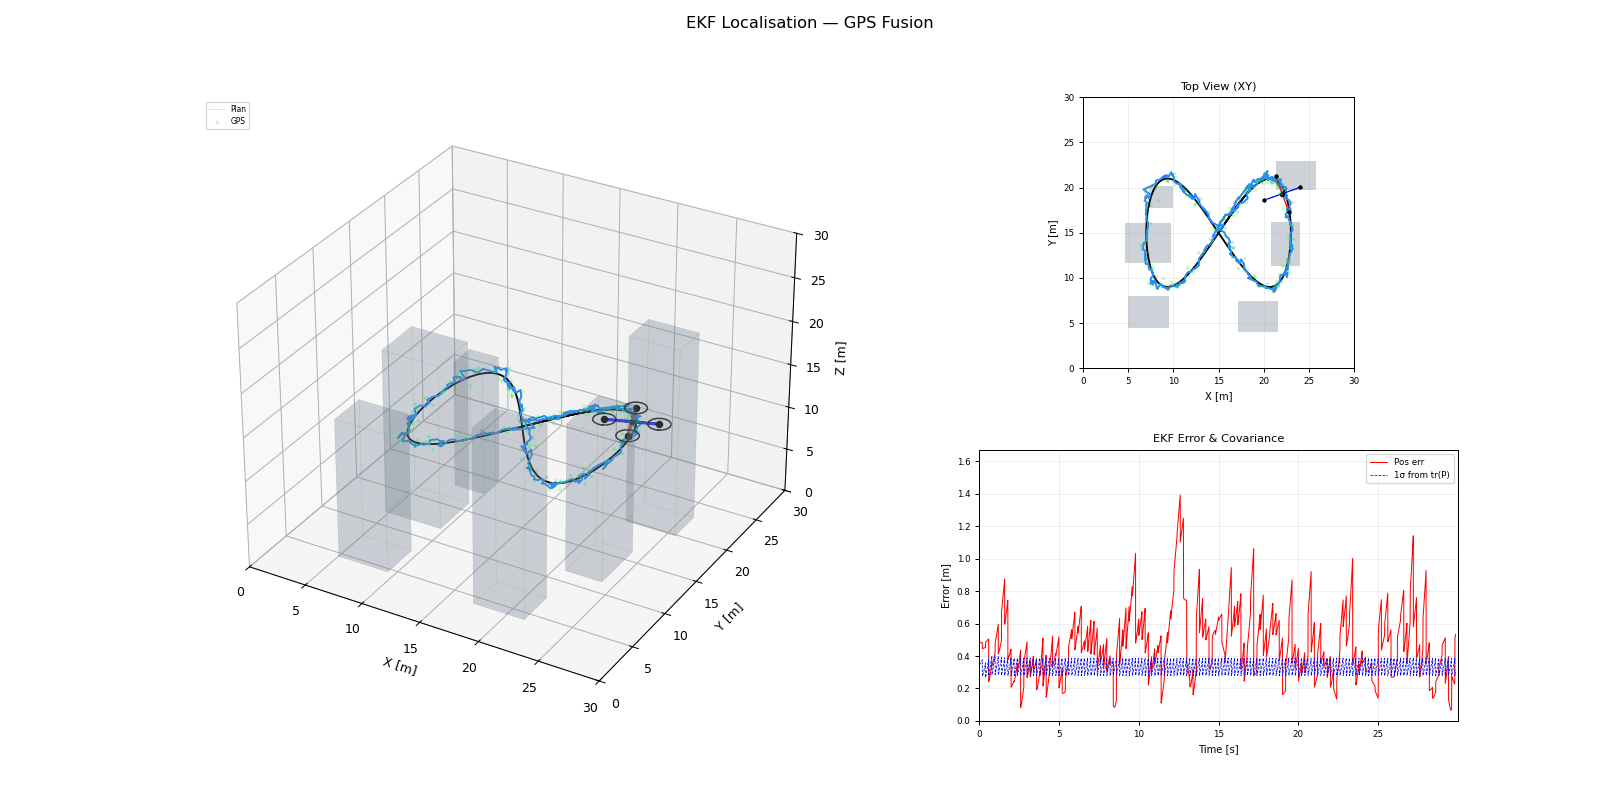 |
| Unscented Kalman filter | Open | 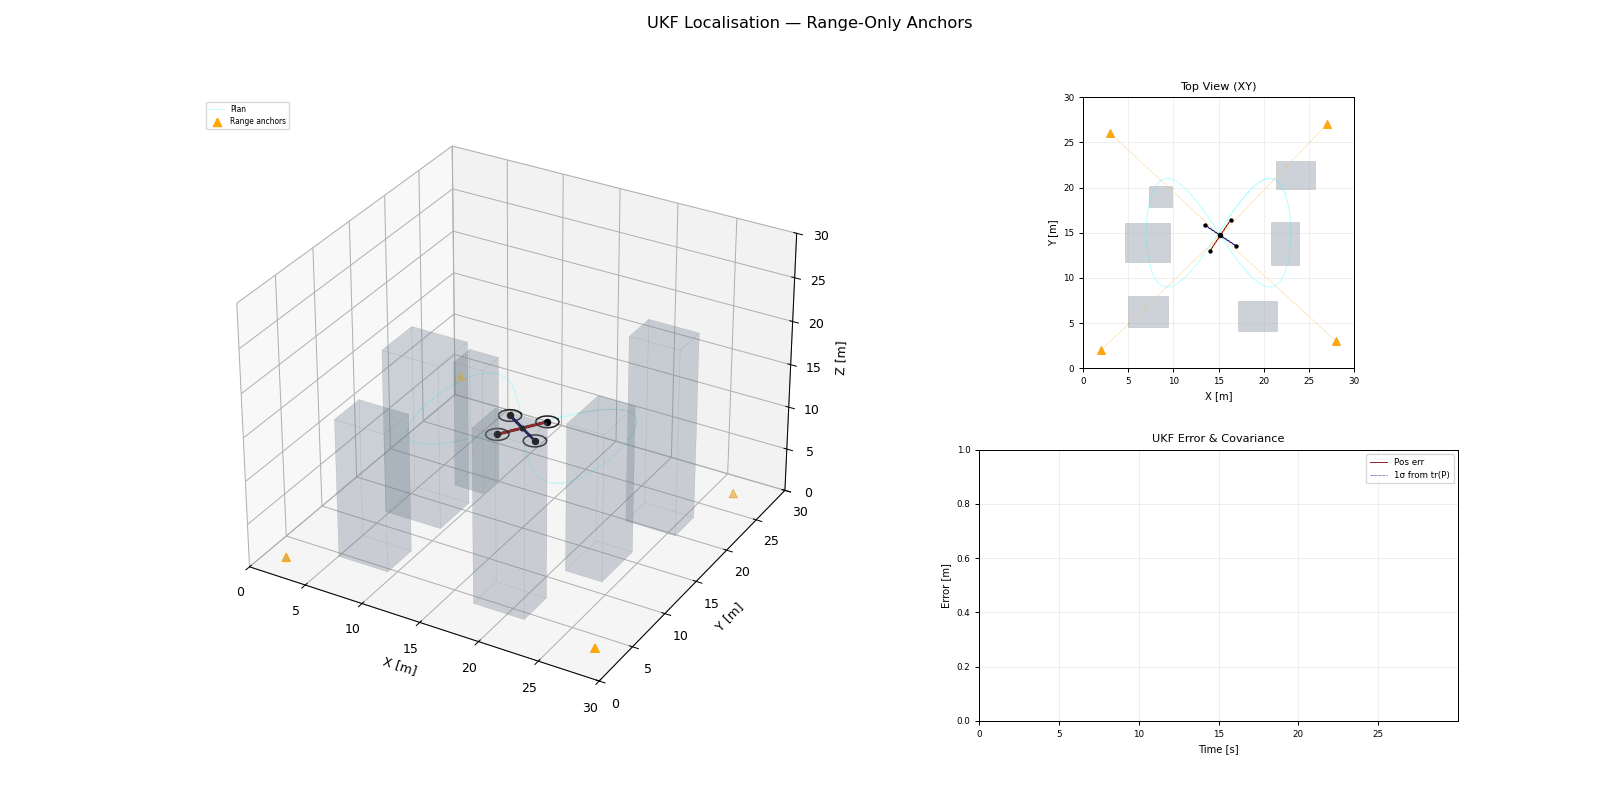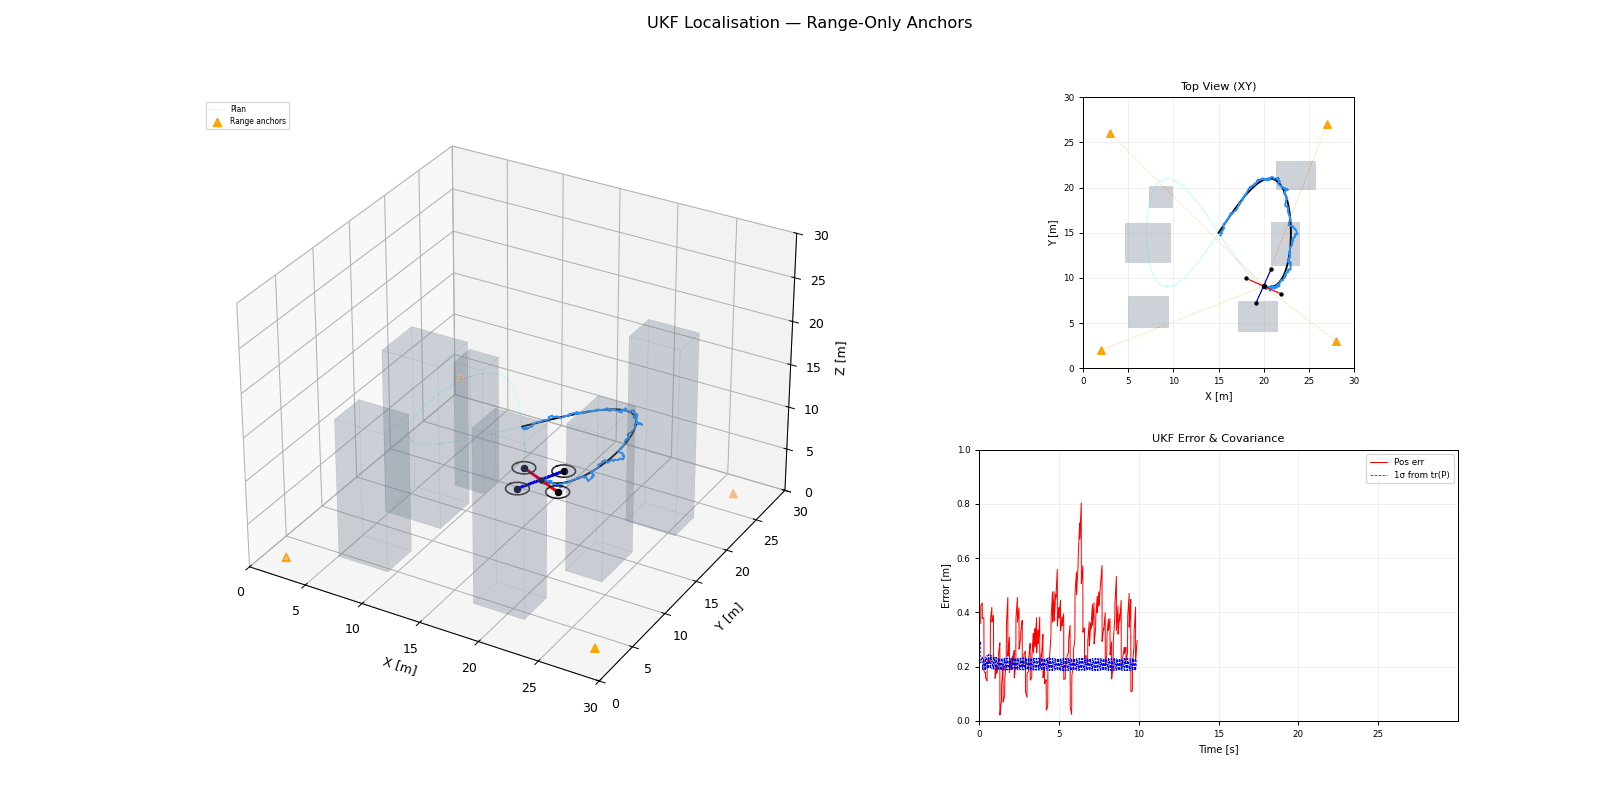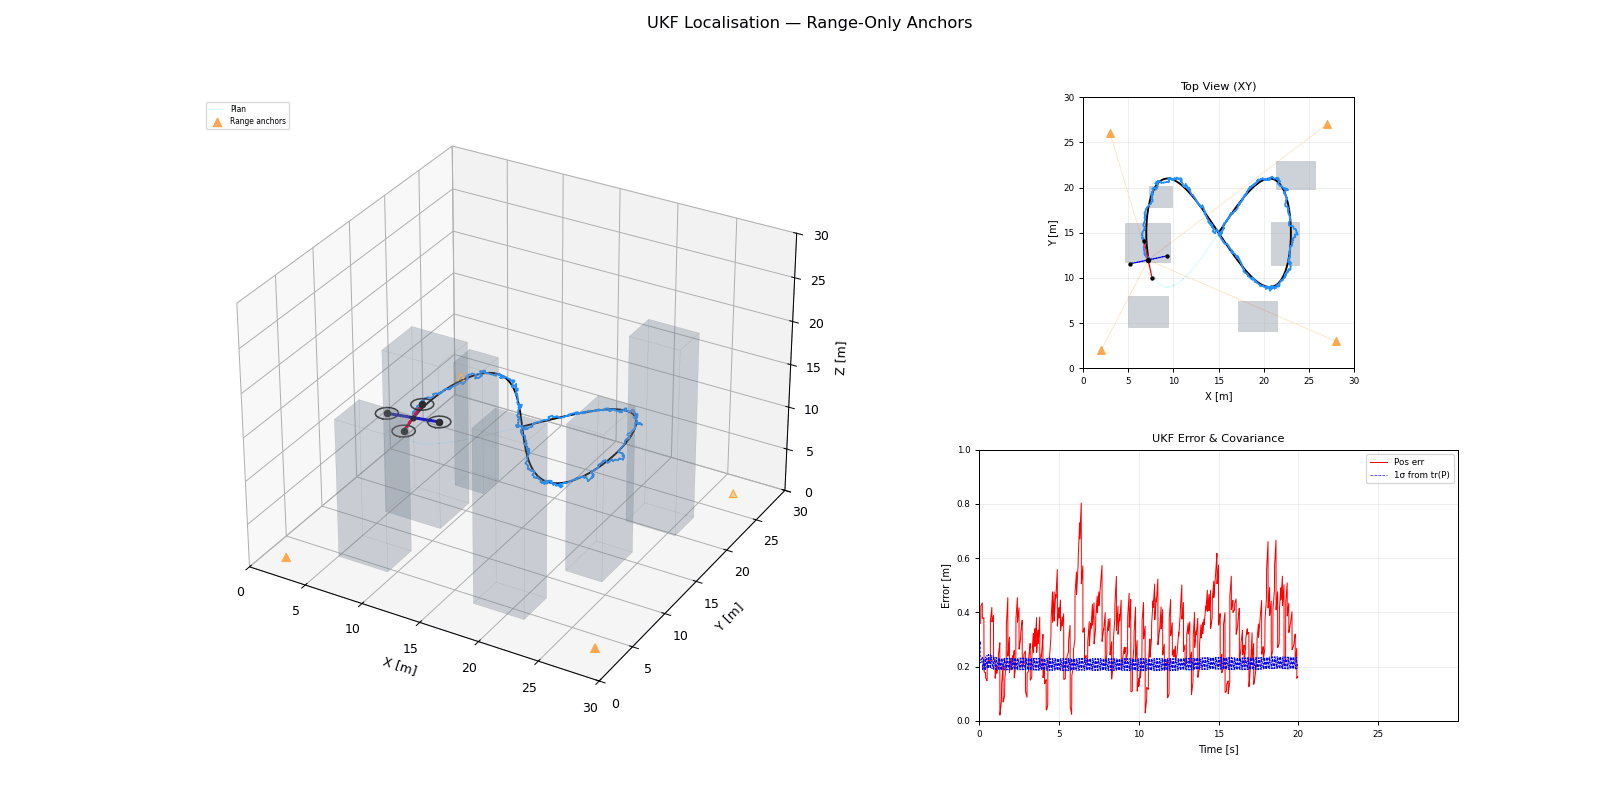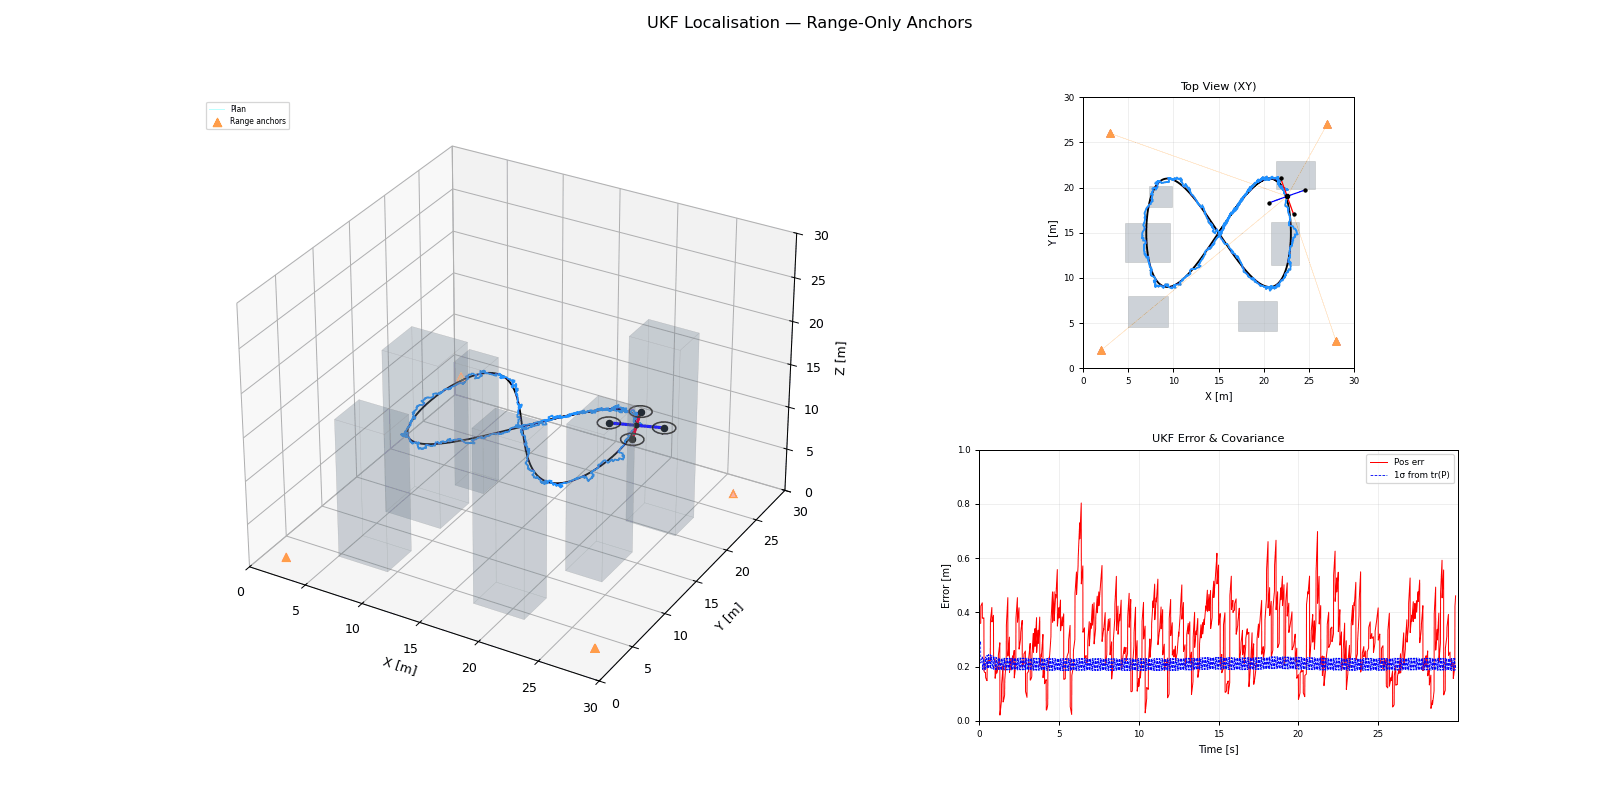 |
| GPS-IMU fusion | Open | 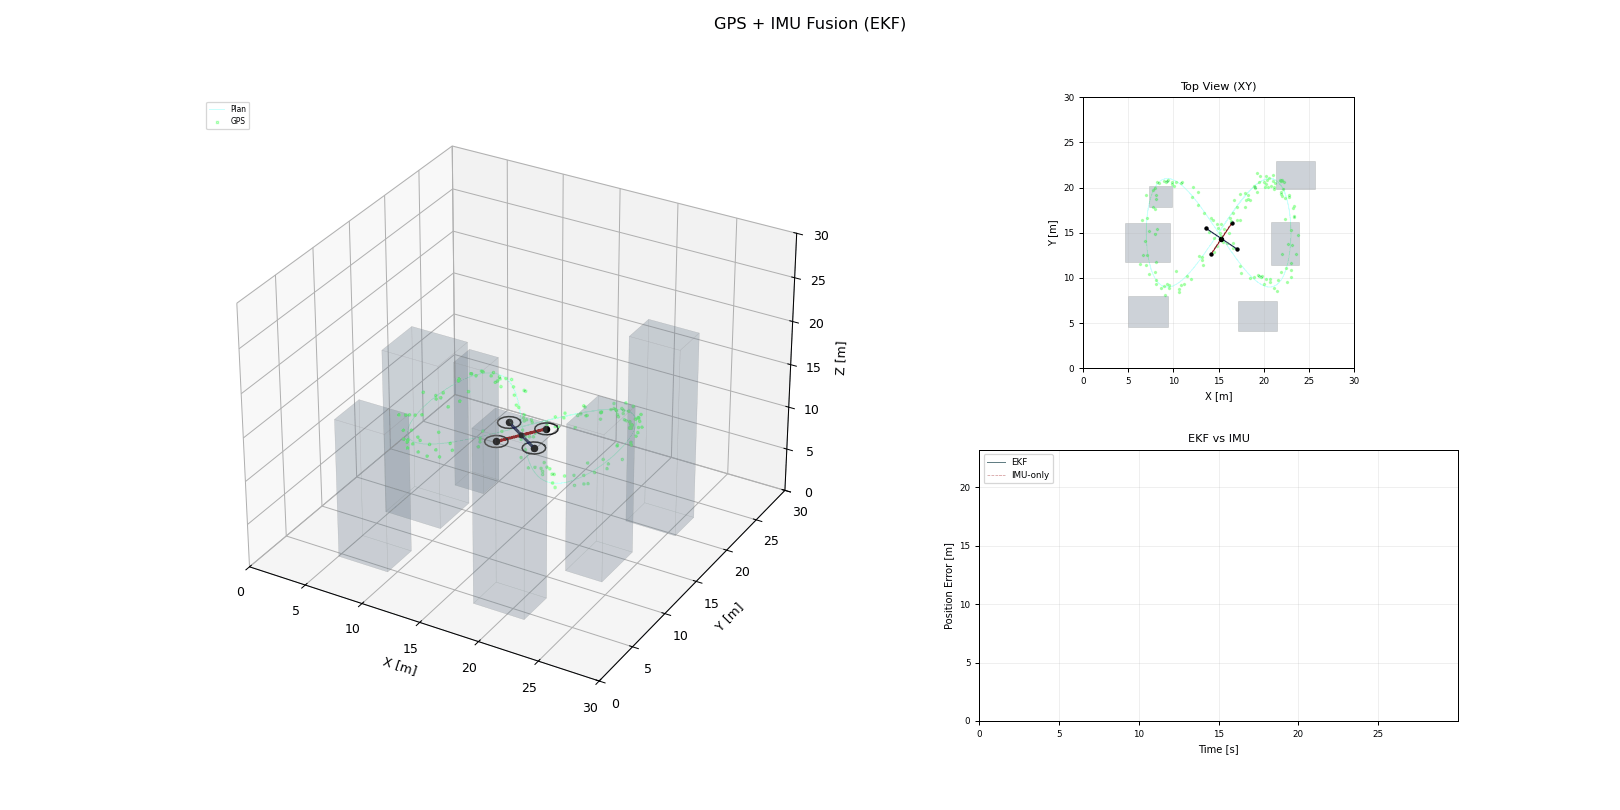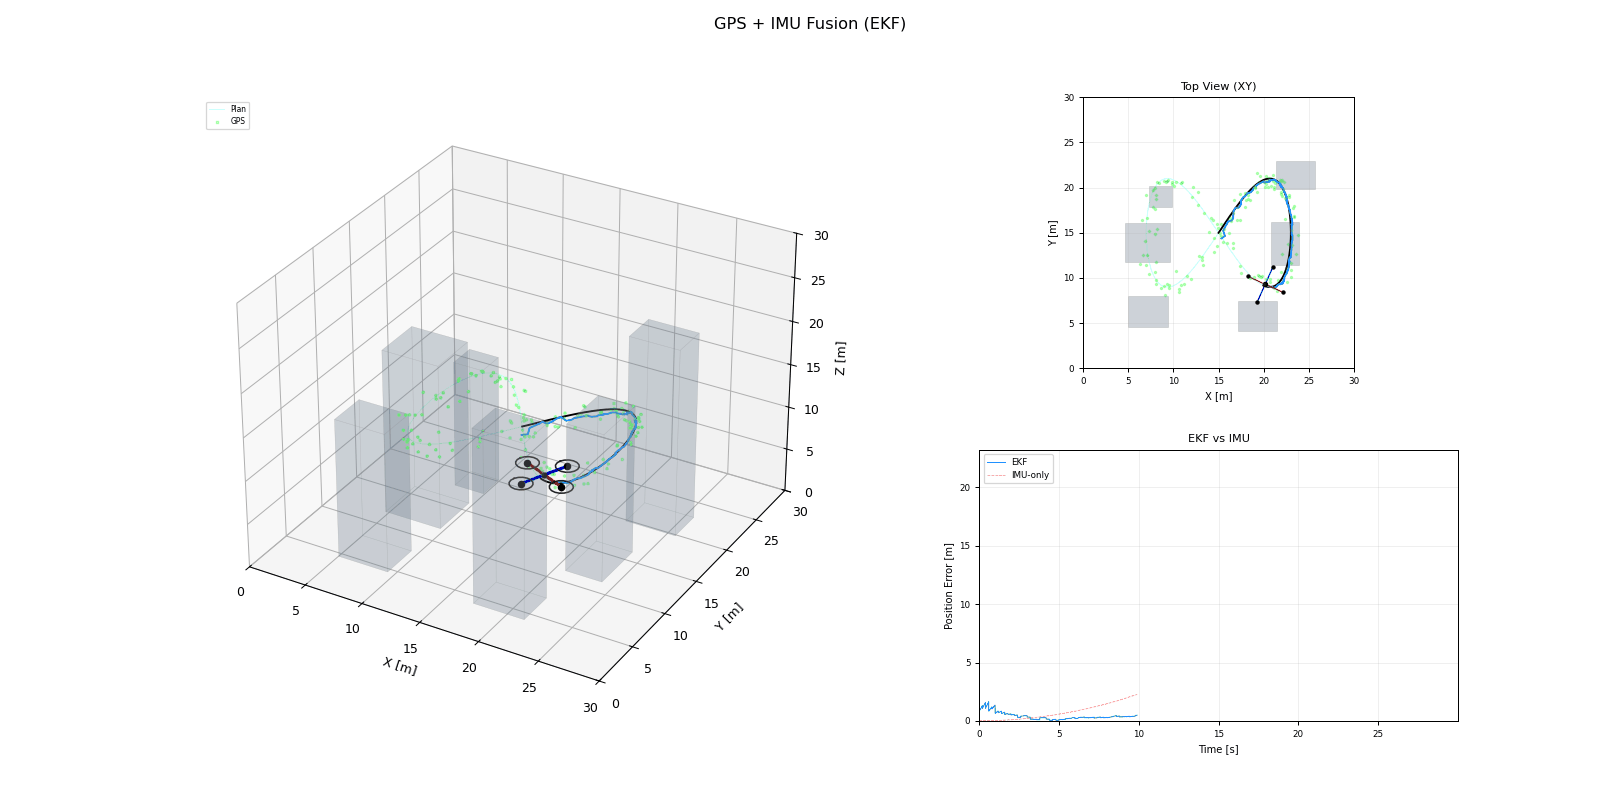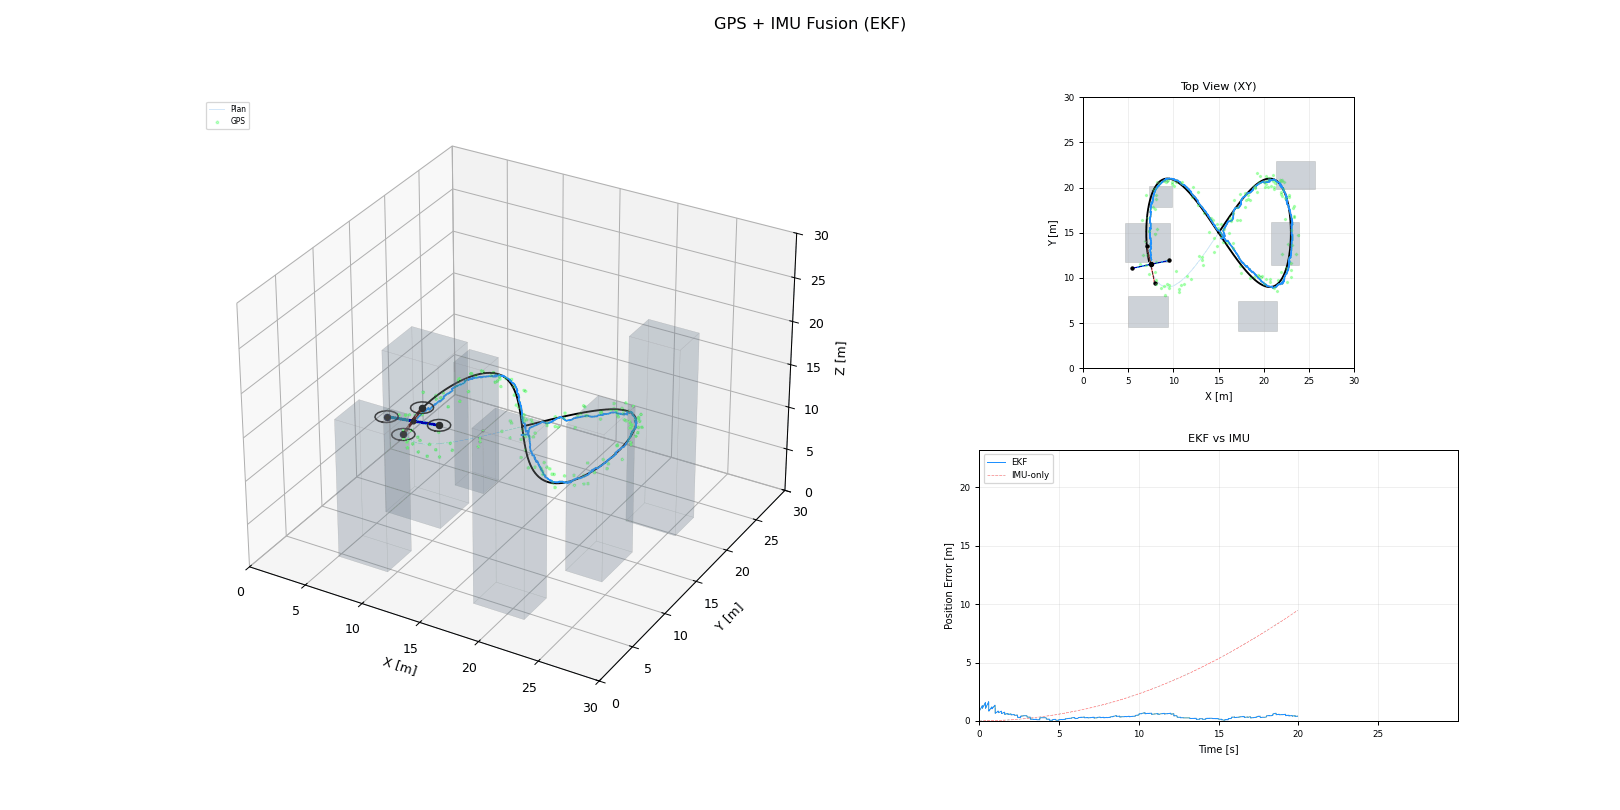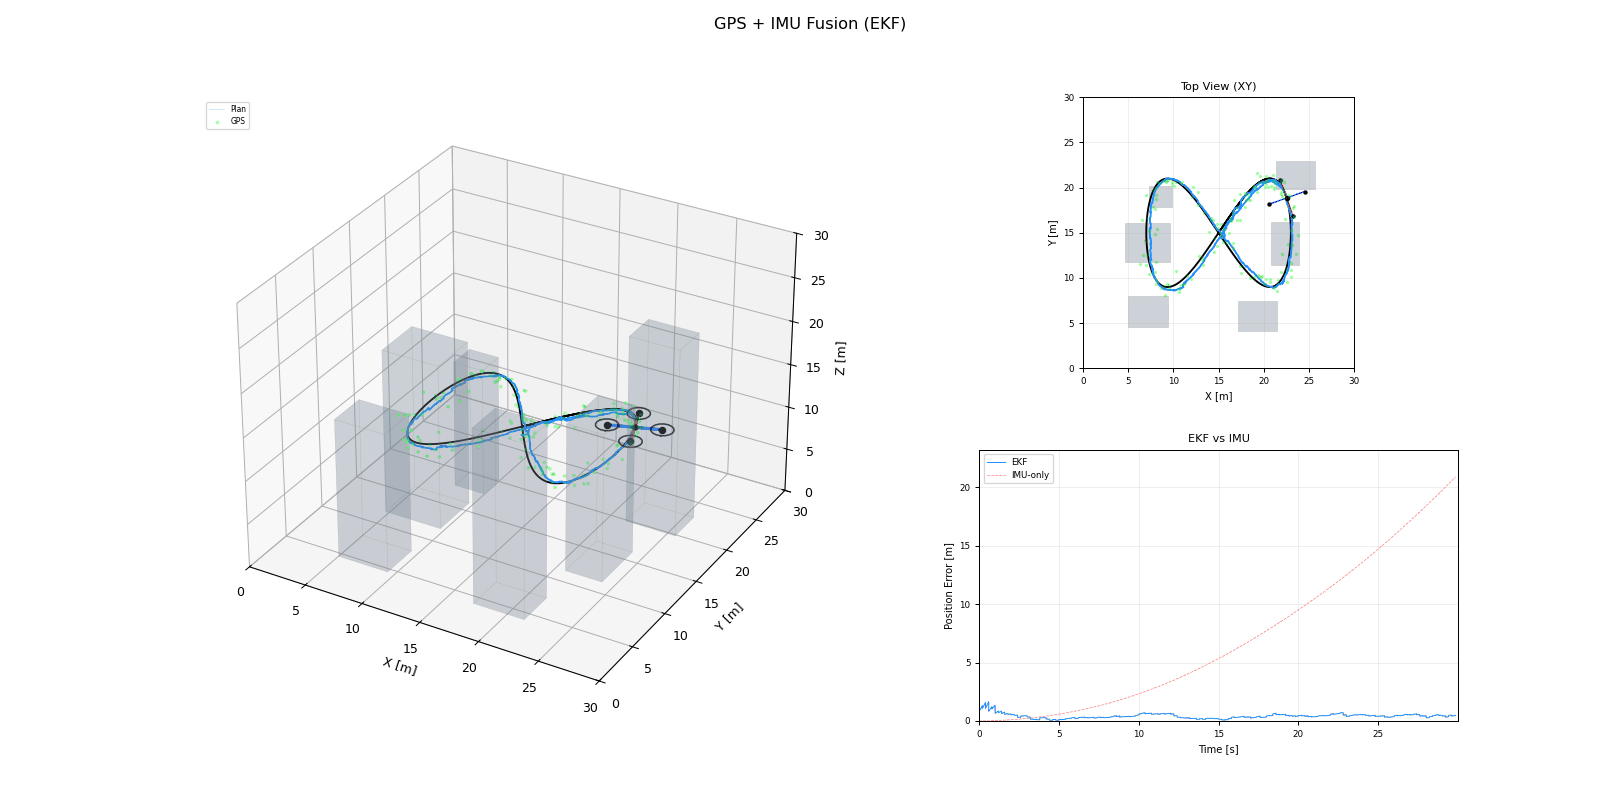 |
| Particle filter | Open | 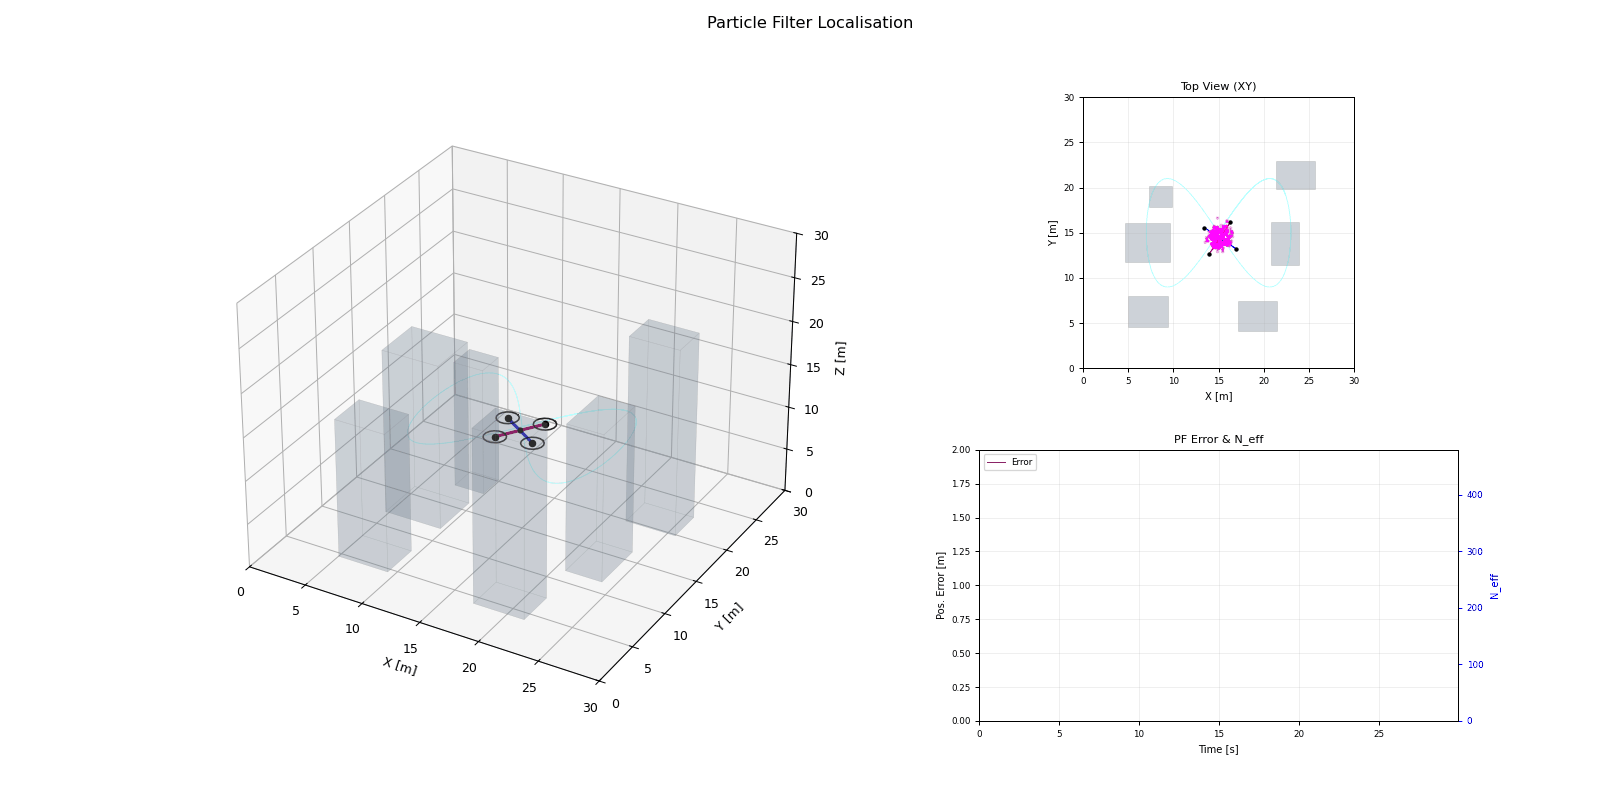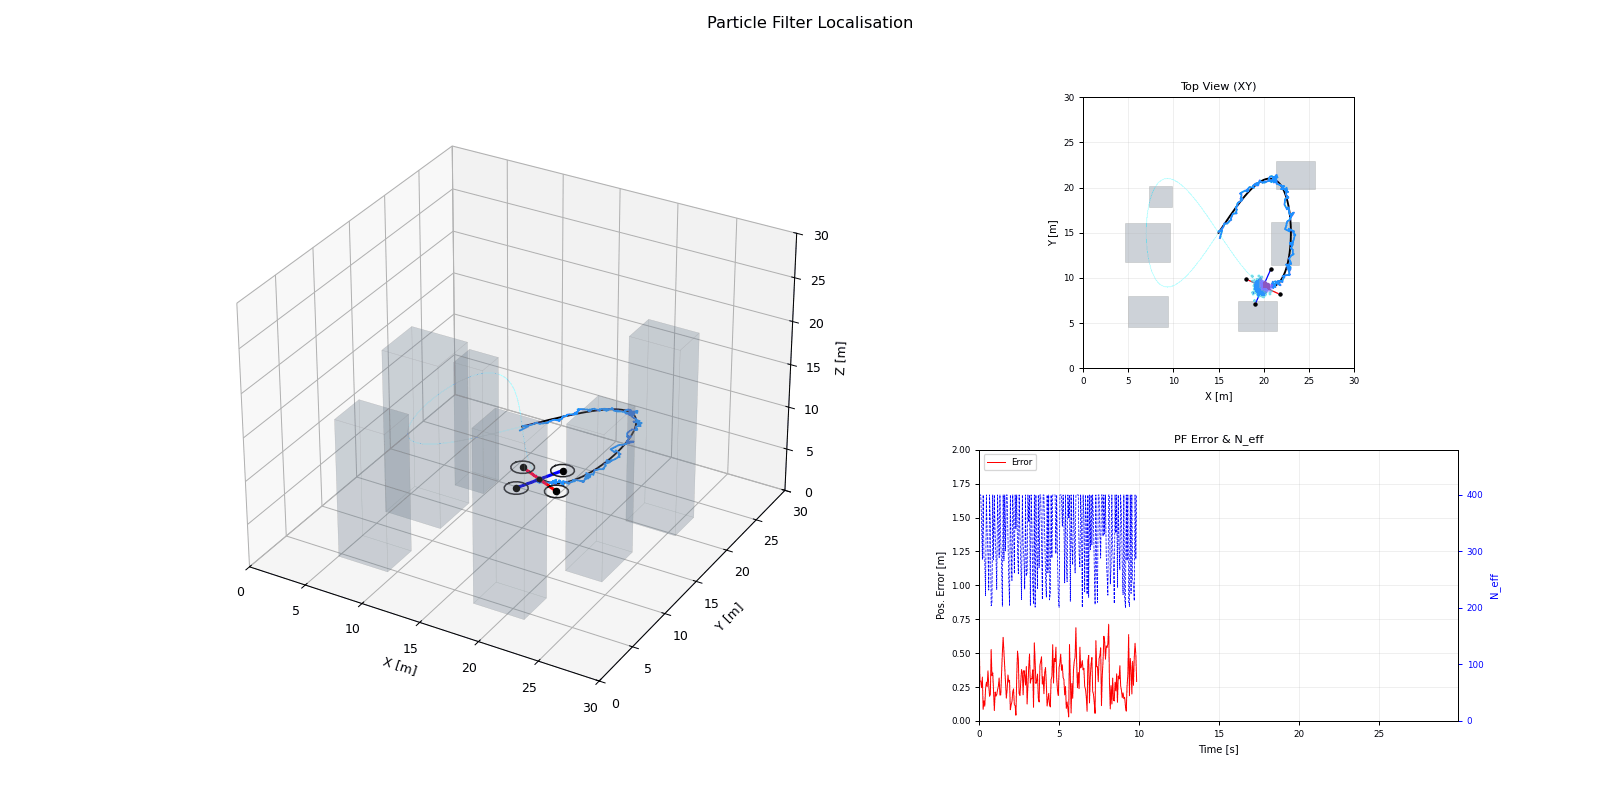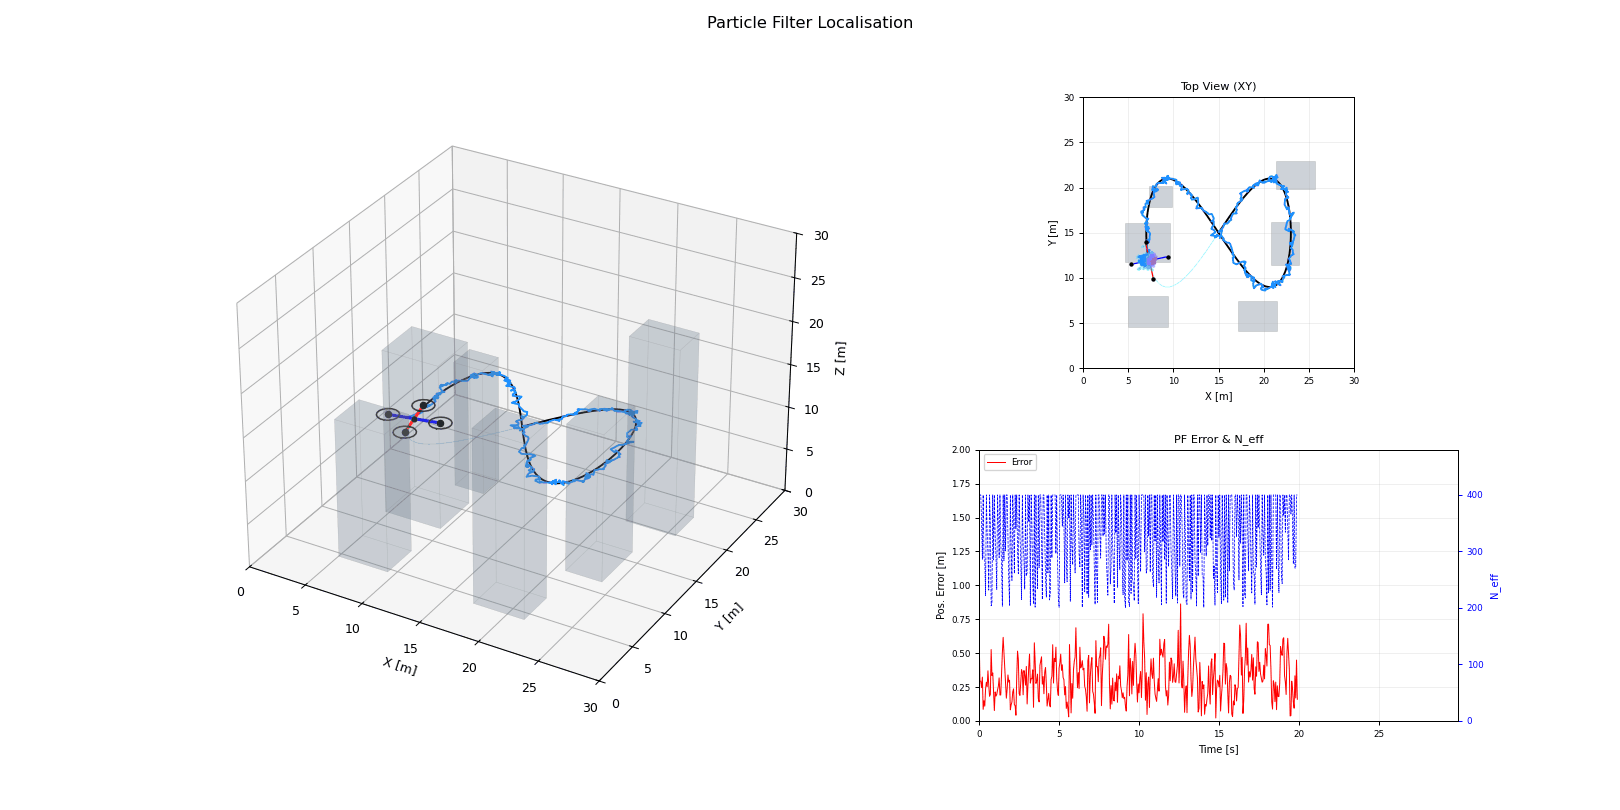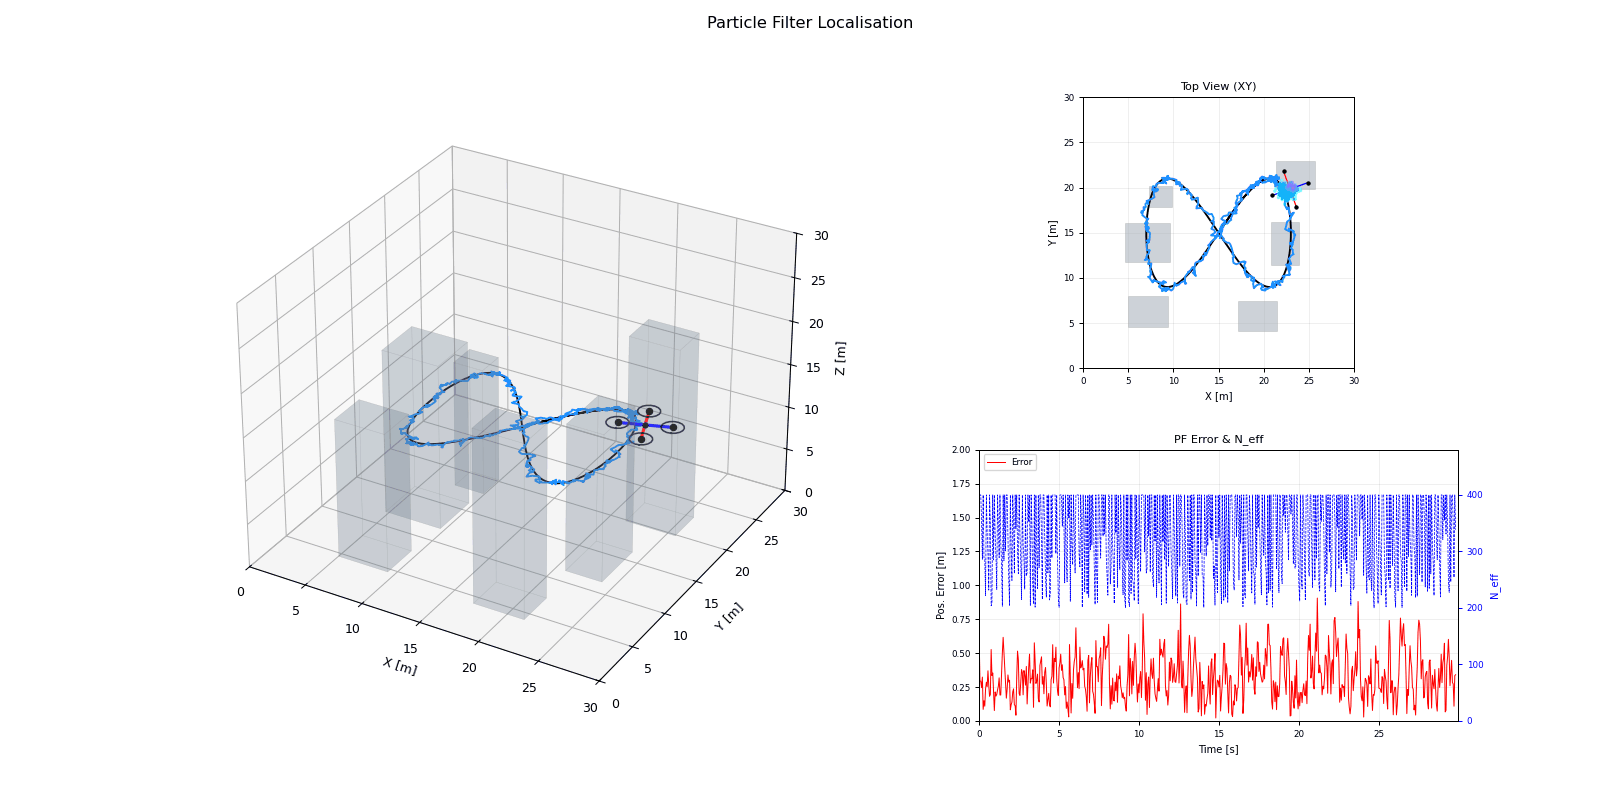 |
Control and path tracking
| Algorithm | Article | Preview |
|---|---|---|
| PID hover | Open | |
| LQR hover | Open |  |
| LQR path tracking | Open |  |
| MPC tracking | Open | 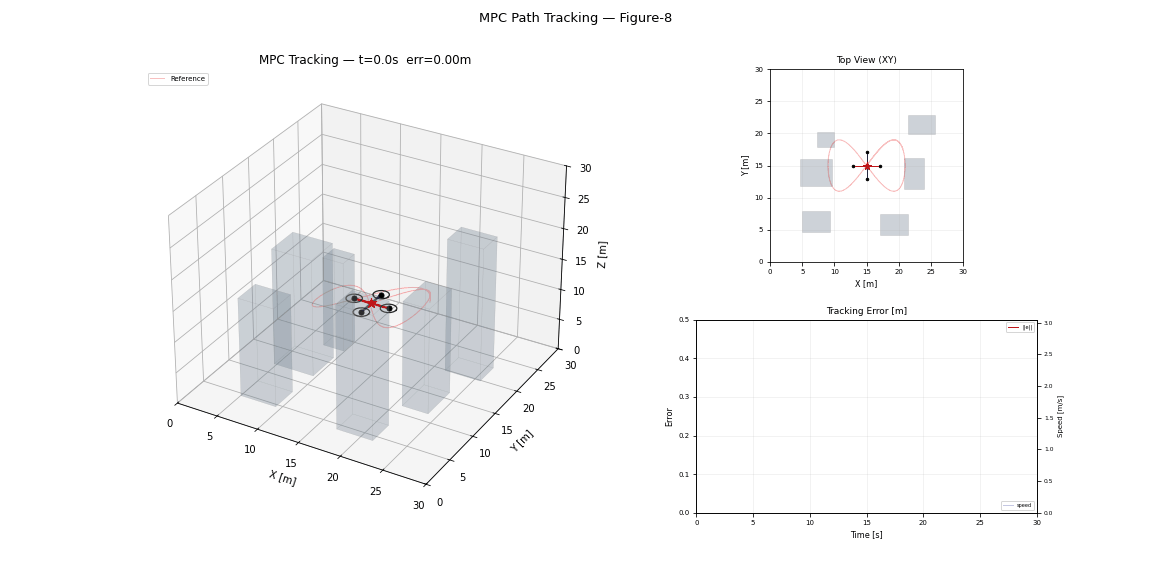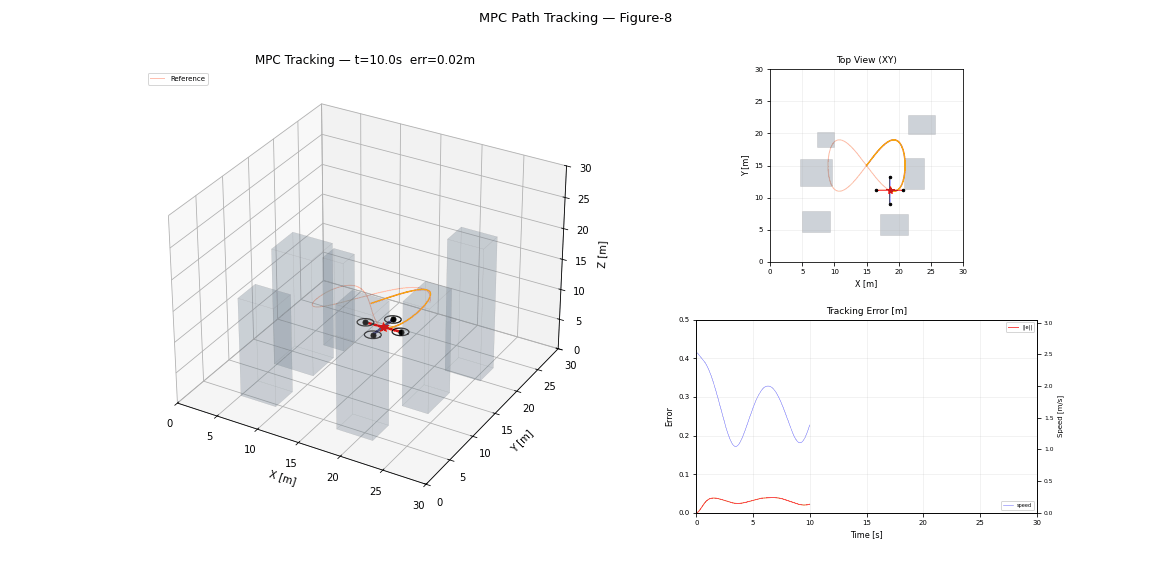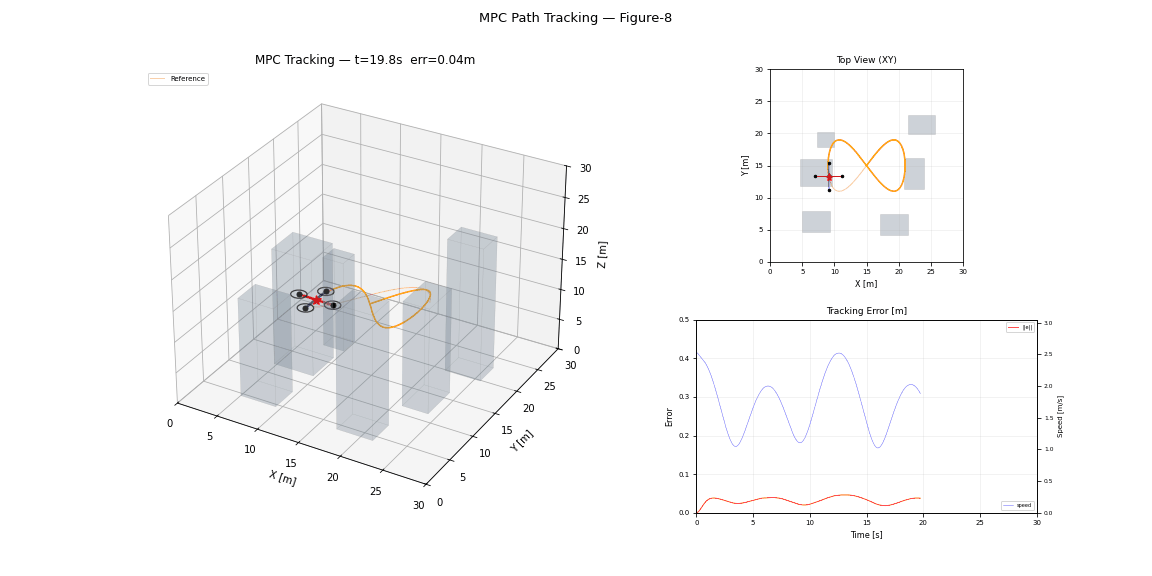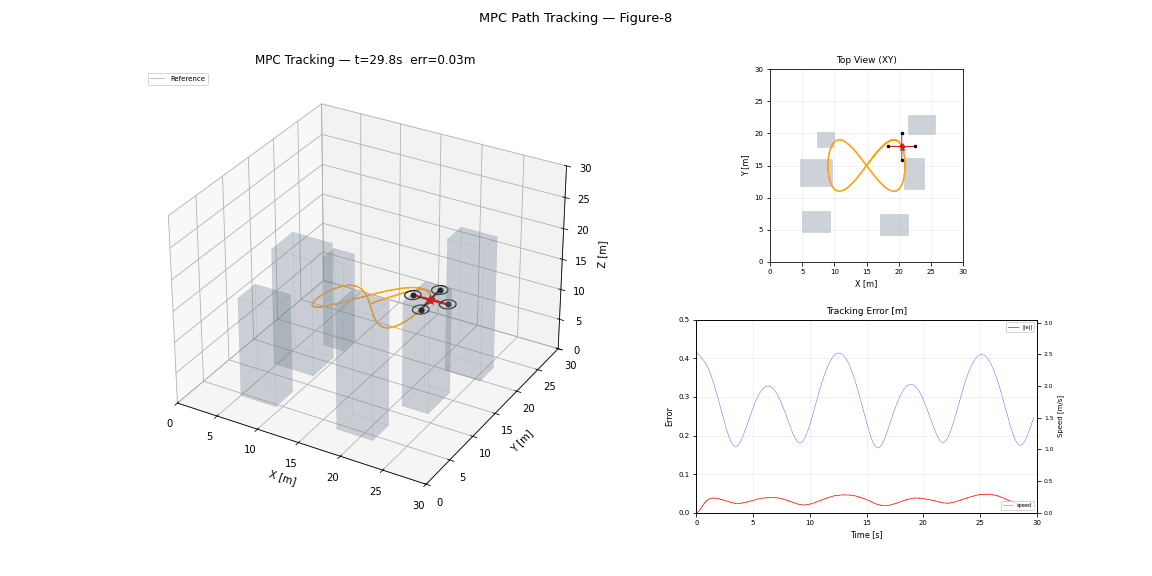 |
| Geometric SO(3) | Open |  |
| Pure pursuit 3D | Open |  |
| Path smoothing | Open |  |
| Flight operations sequence | Open |  |
| Fixed-wing mission navigation | Open |  |
Path planning
| Algorithm | Article | Preview |
|---|---|---|
| A* 3D | Open | 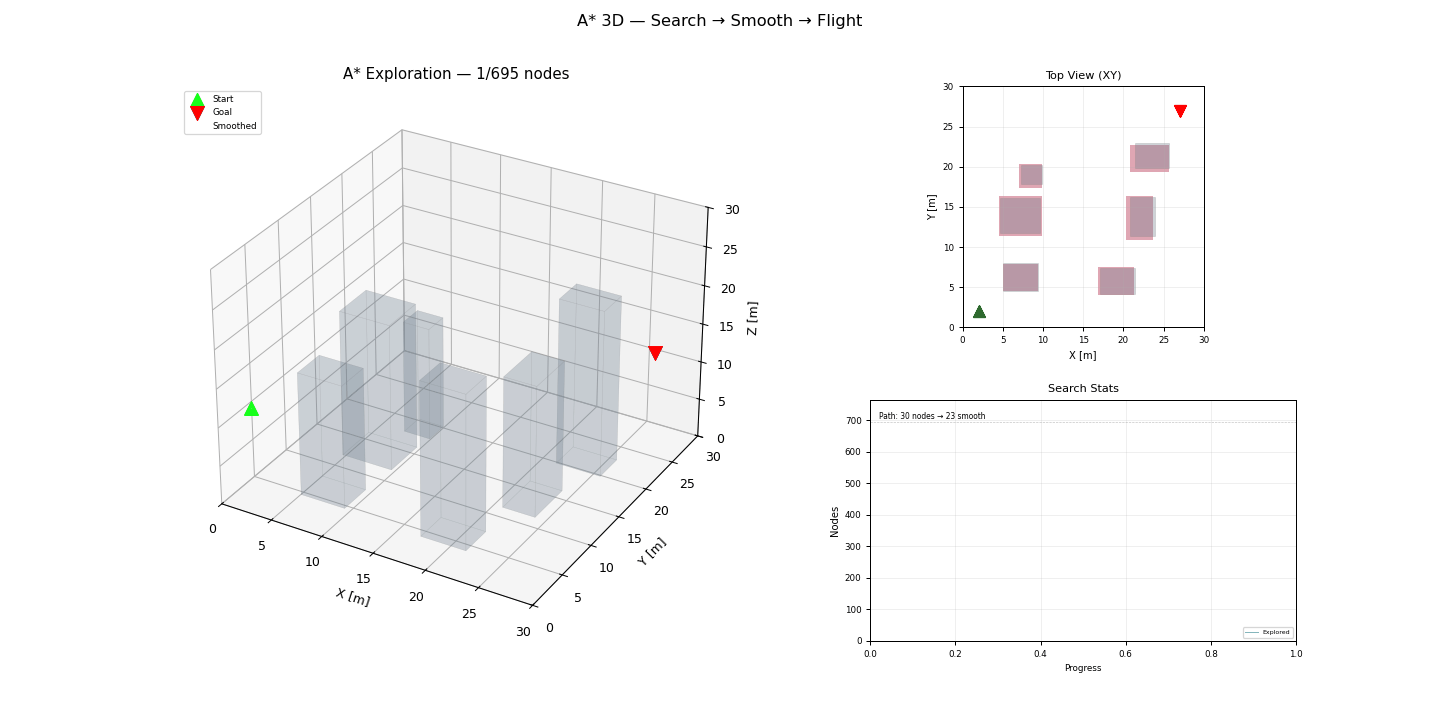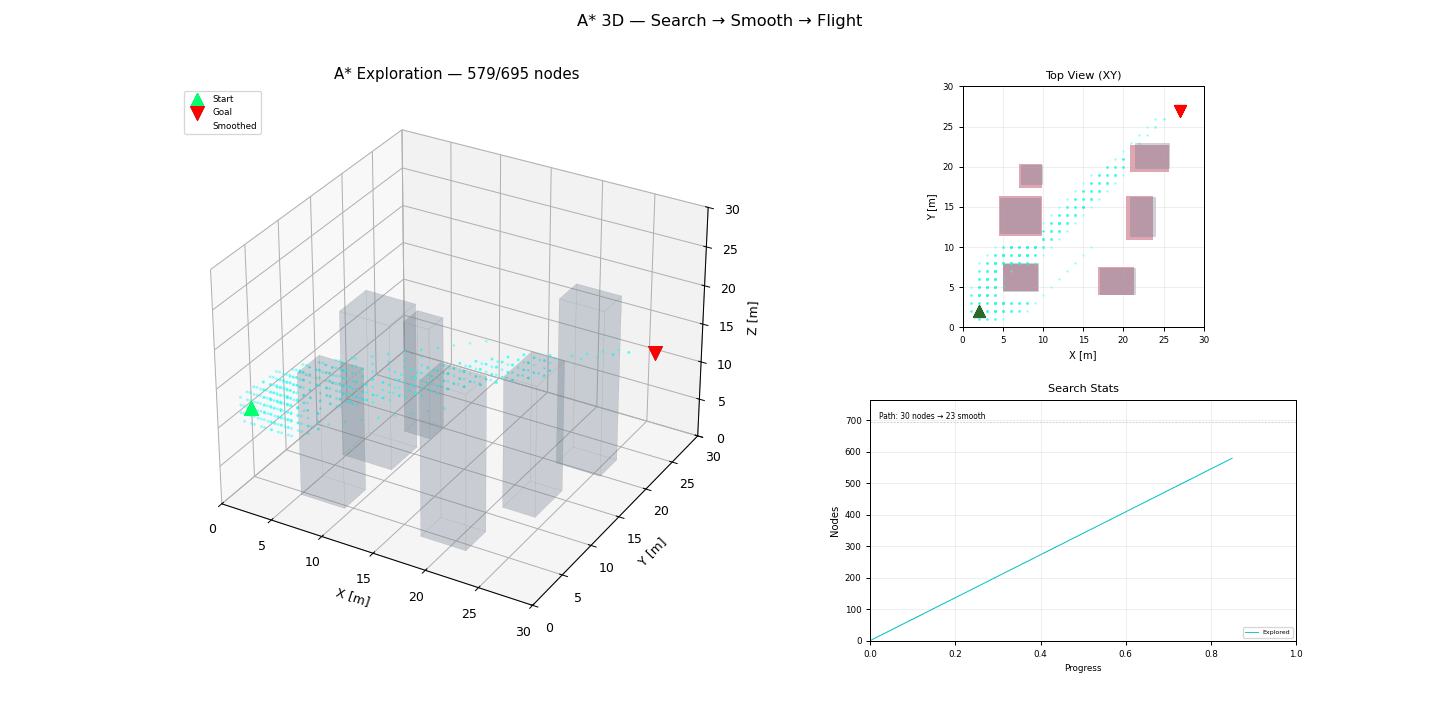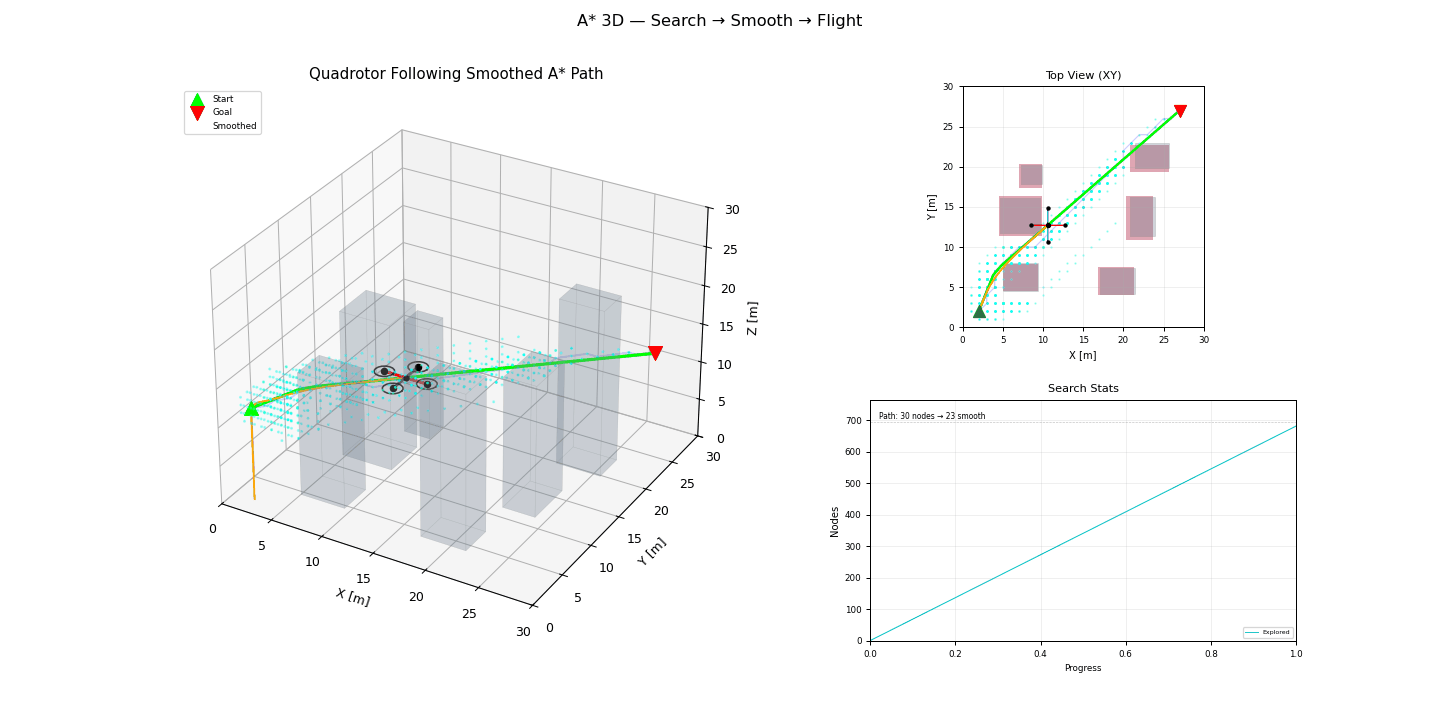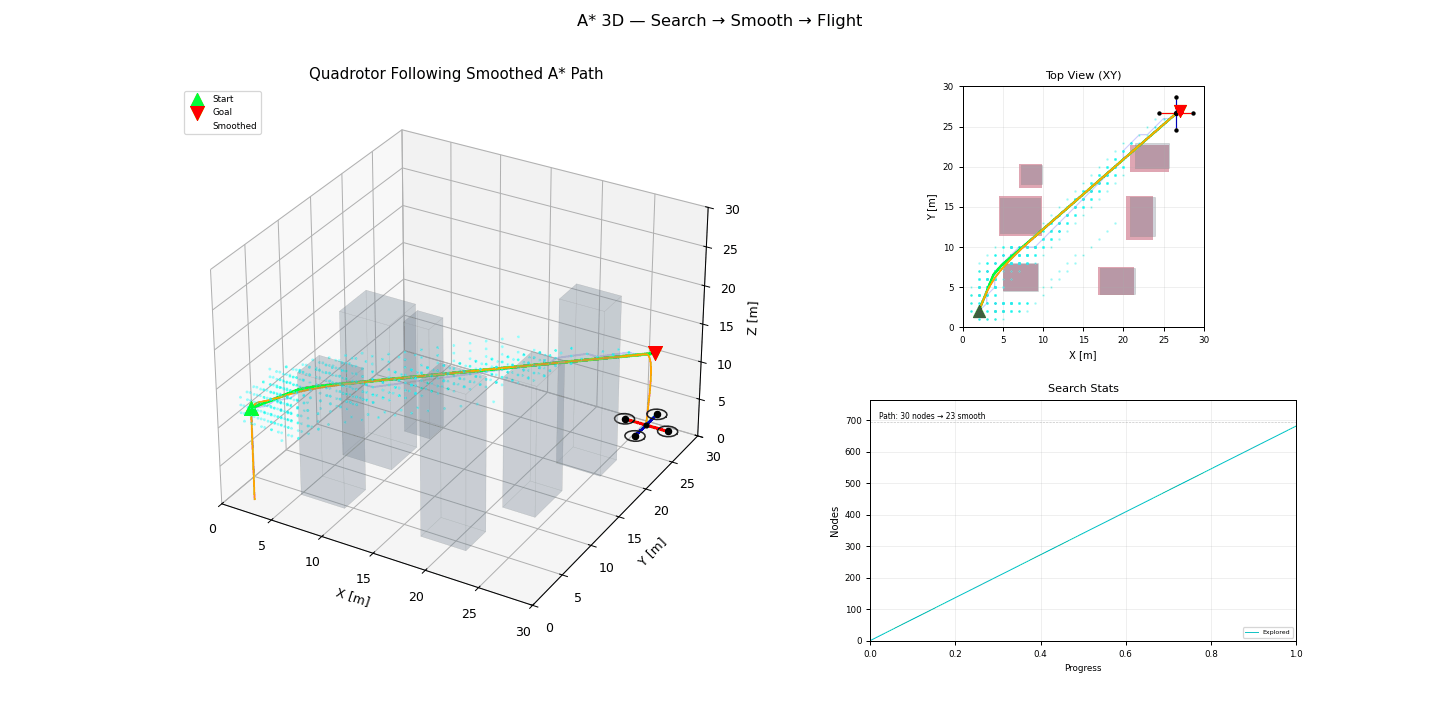 |
| RRT* 3D | Open |  |
| PRM 3D | Open | 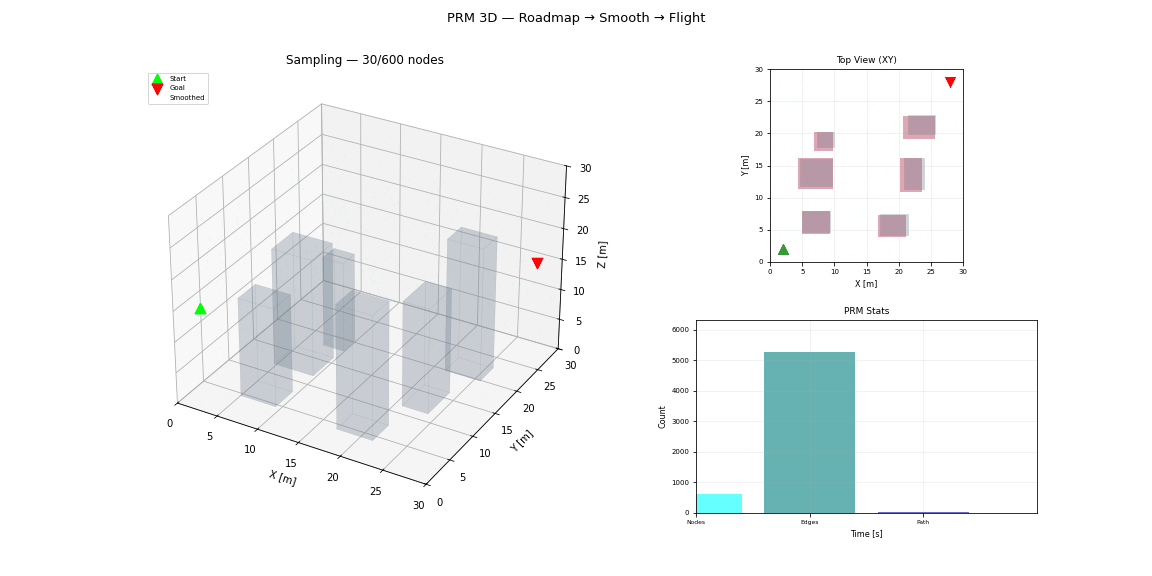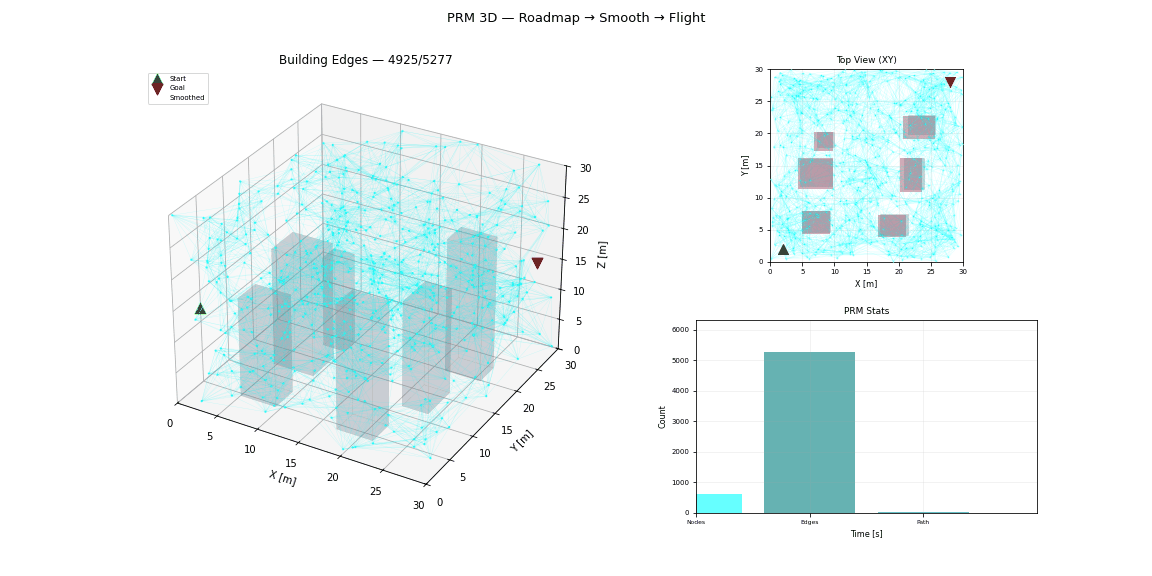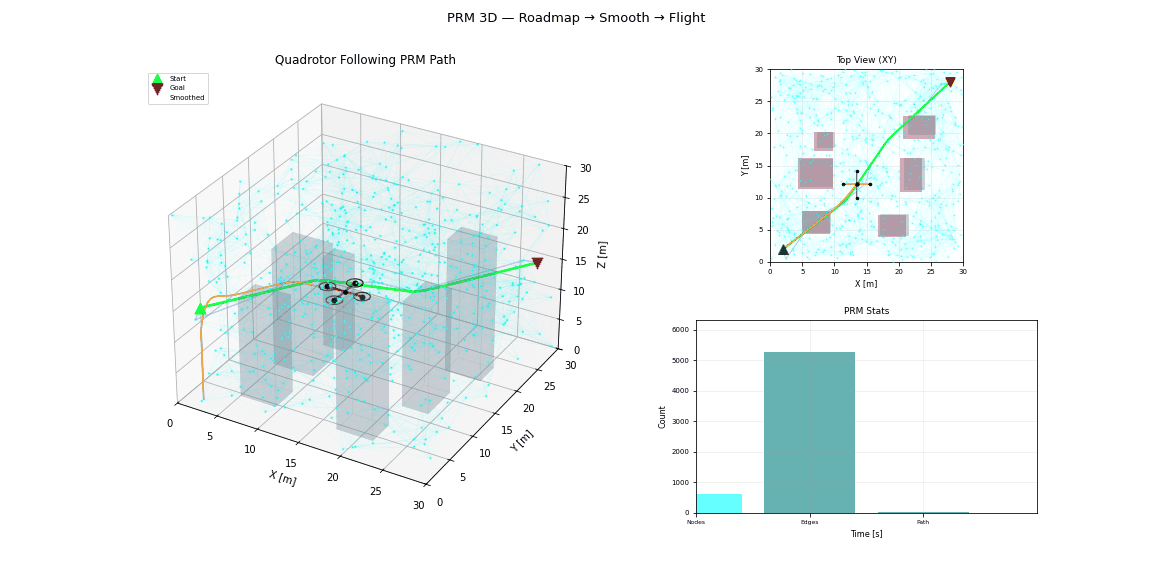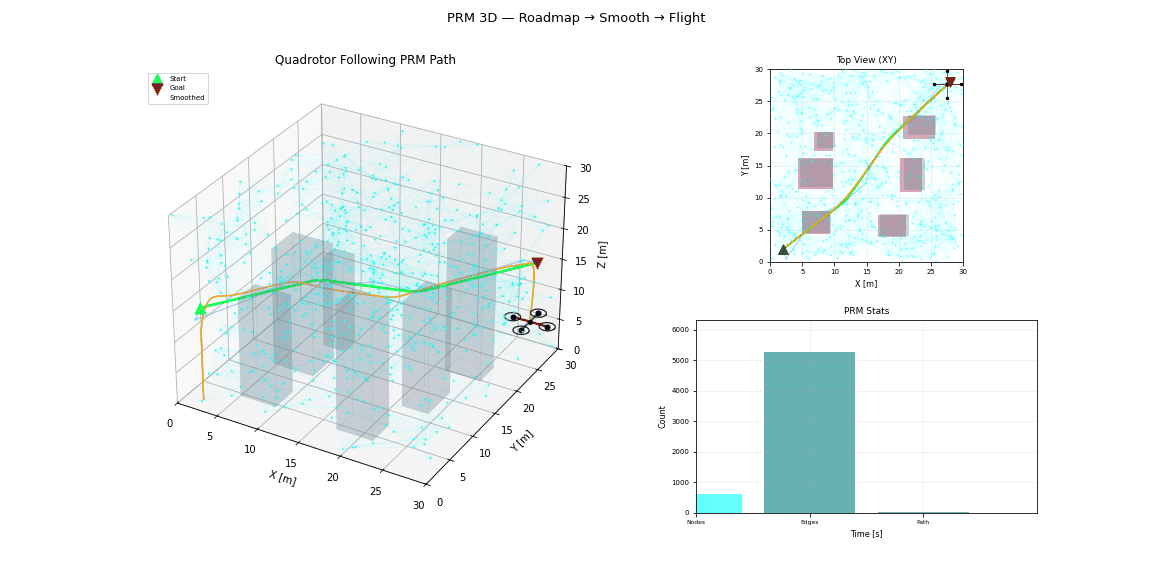 |
| Potential field 3D | Open |  |
| Coverage planning | Open |  |
Trajectory planning
| Algorithm | Article | Preview |
|---|---|---|
| Minimum snap | Open | 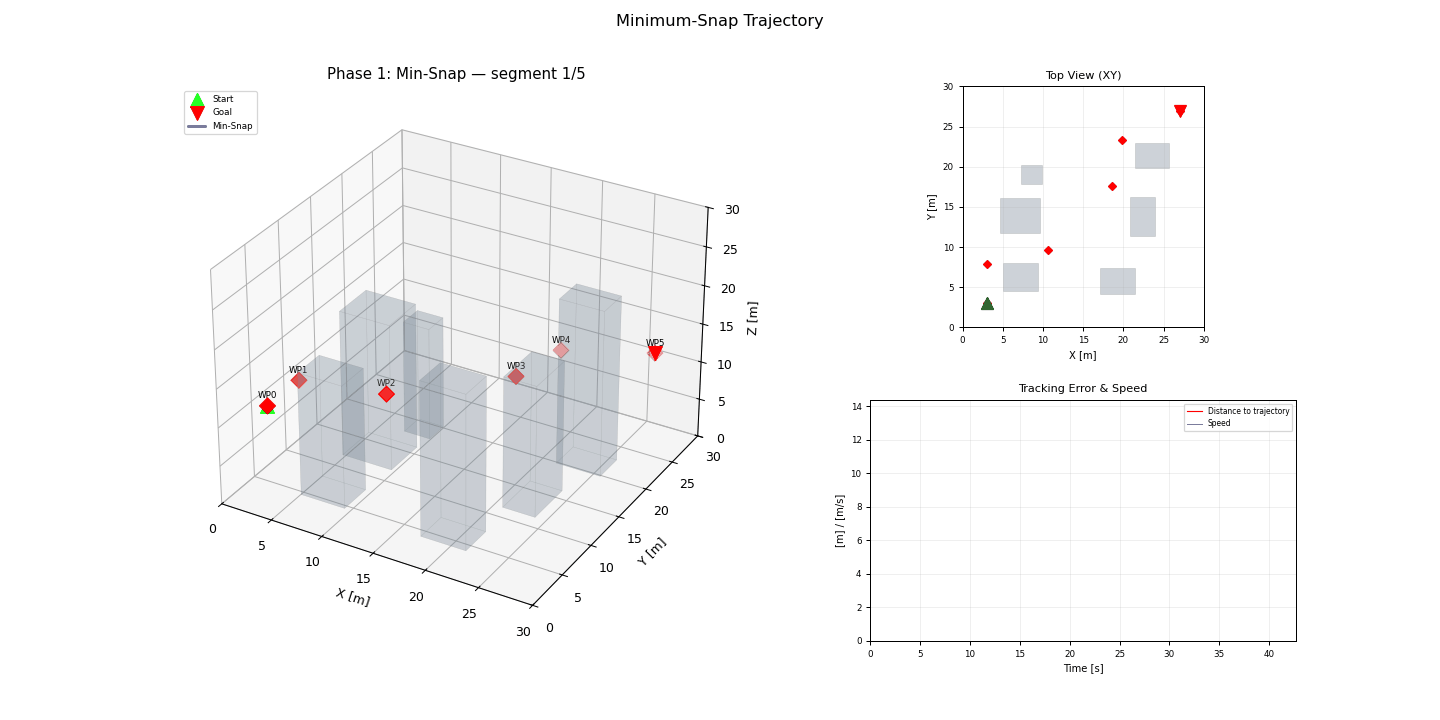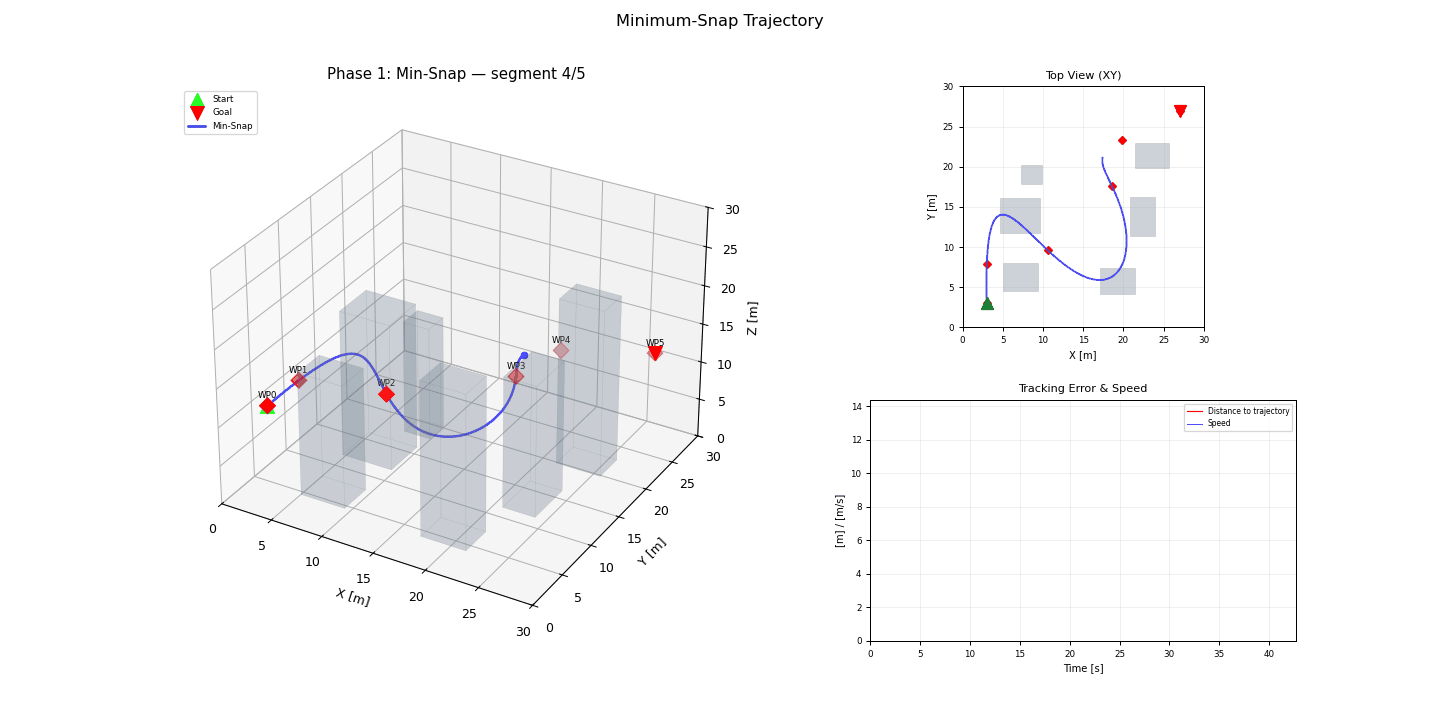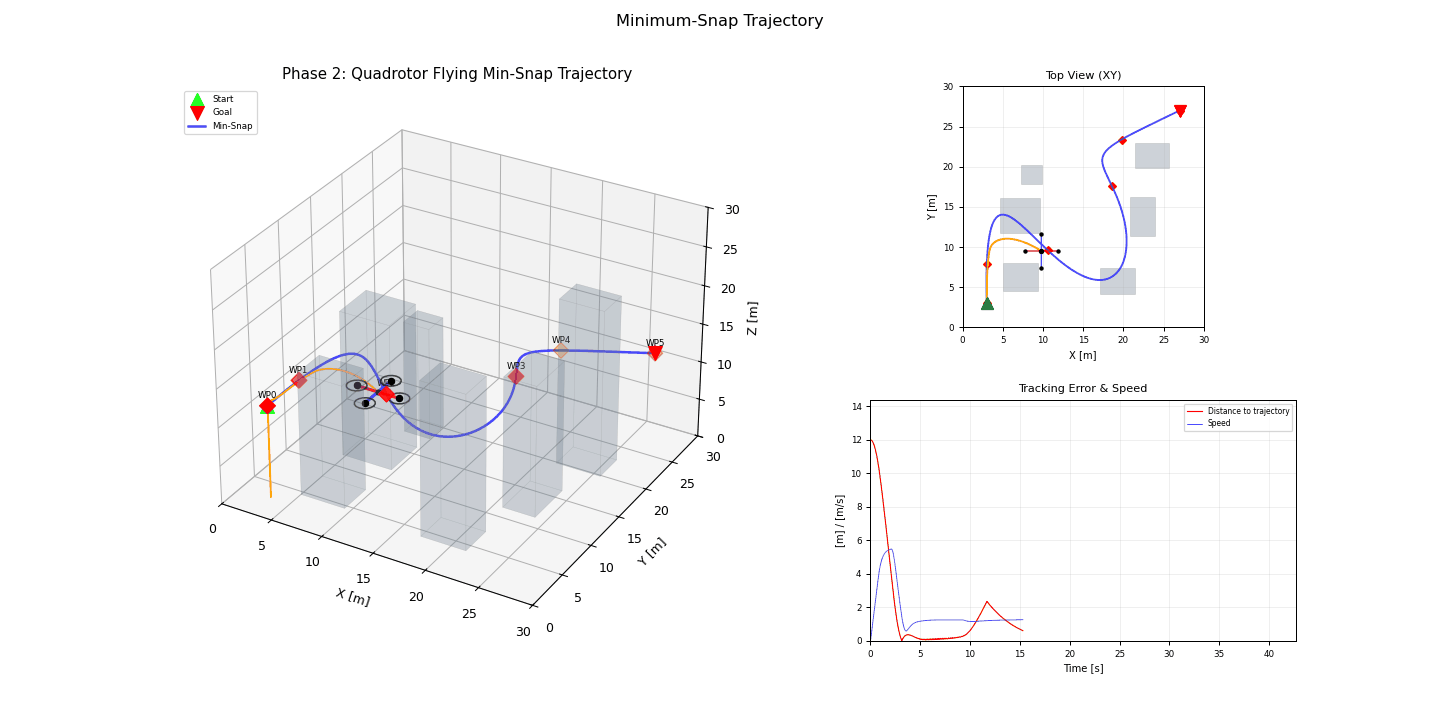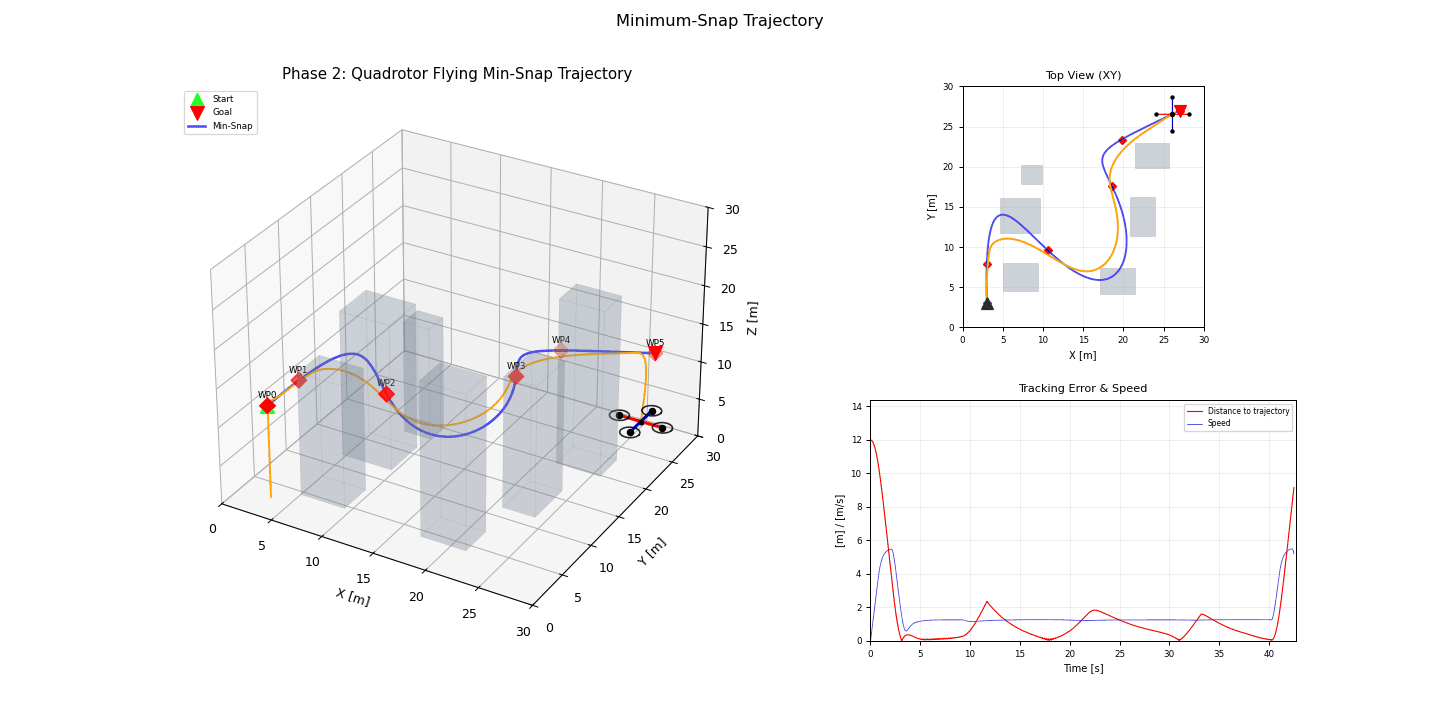 |
| Polynomial trajectory | Open |  |
| Quintic polynomial | Open |  |
| Frenet optimal | Open |  |
Trajectory tracking
| Algorithm | Article | Preview |
|---|---|---|
| Feedback linearisation | Open |  |
| NMPC | Open |  |
| MPPI | Open |  |
Perception
| Feature | Article | Preview |
|---|---|---|
| EKF-SLAM | Open |  |
| Occupancy mapping | Open |  |
| Visual servoing | Open |  |
| Sensor suite | Open |  |
Sensors
| Feature | Article | Preview |
|---|---|---|
| Gimbal FOV tracking | Open |  |
| Gimbal bounding-box tracking | Open |  |
Environment and costmaps
| Feature | Article | Preview |
|---|---|---|
| Dynamic costmap navigation | Open | 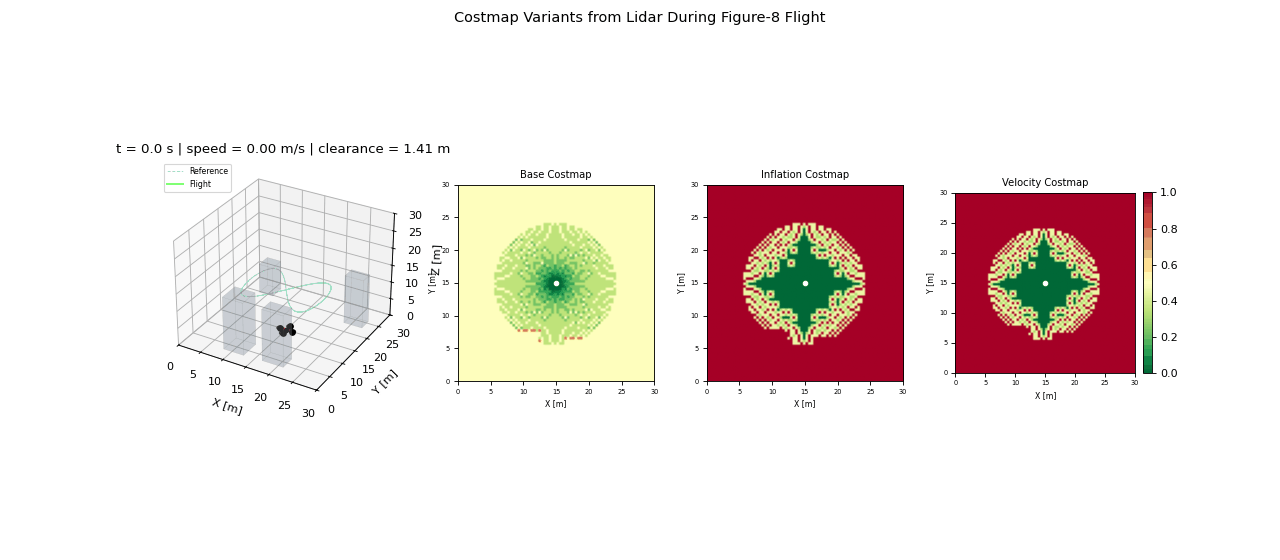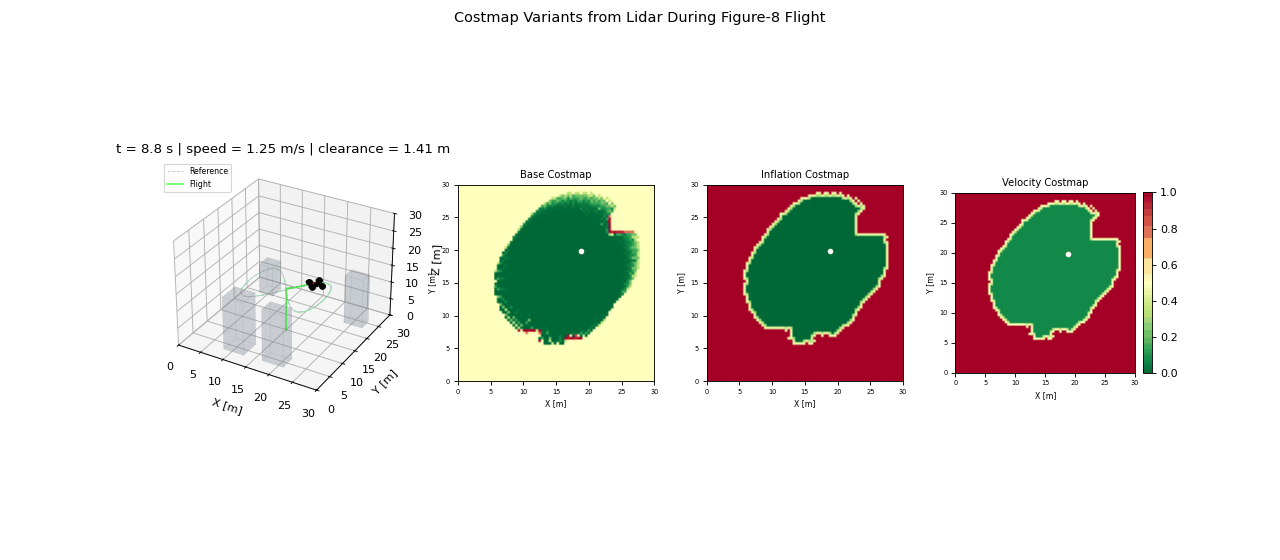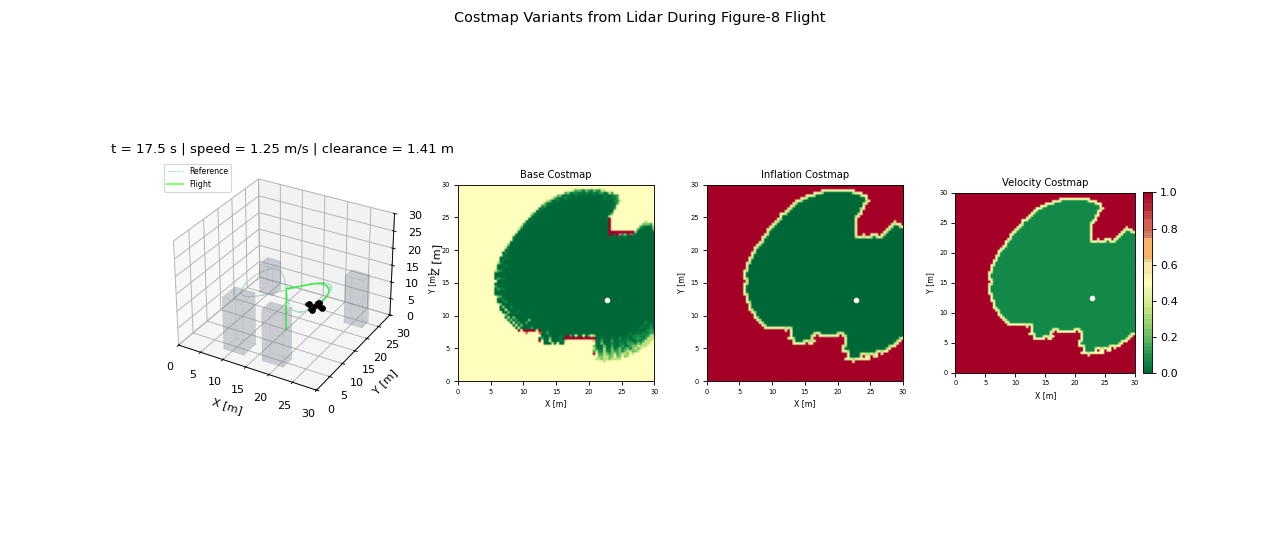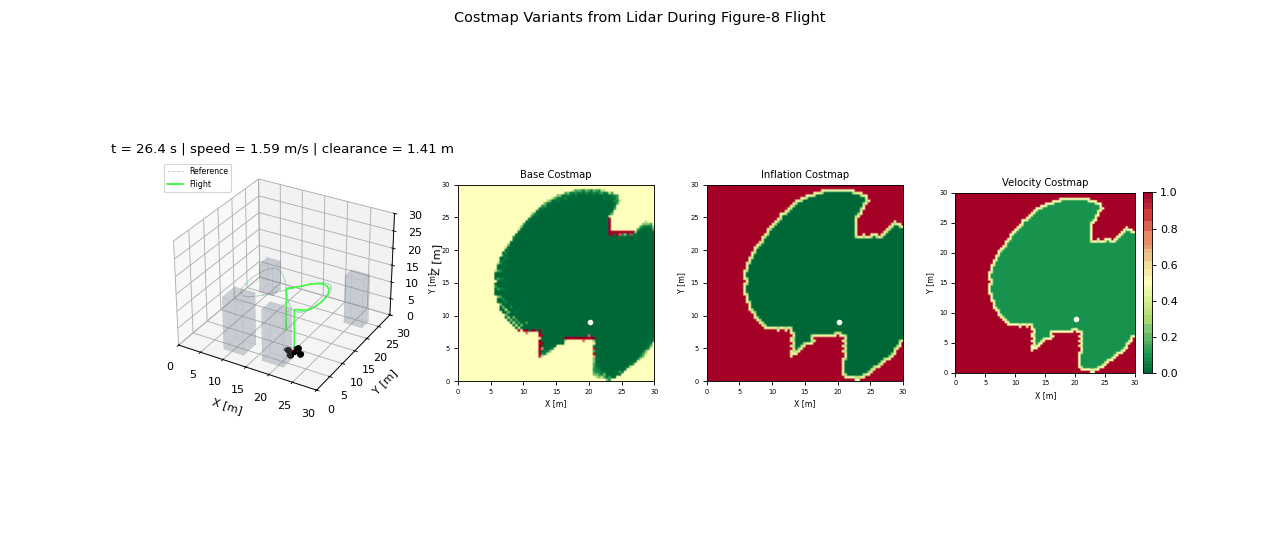 |
Swarm
| Algorithm | Article | Preview |
|---|---|---|
| Reynolds flocking | Open |  |
| Consensus formation | Open |  |
| Virtual structure | Open | 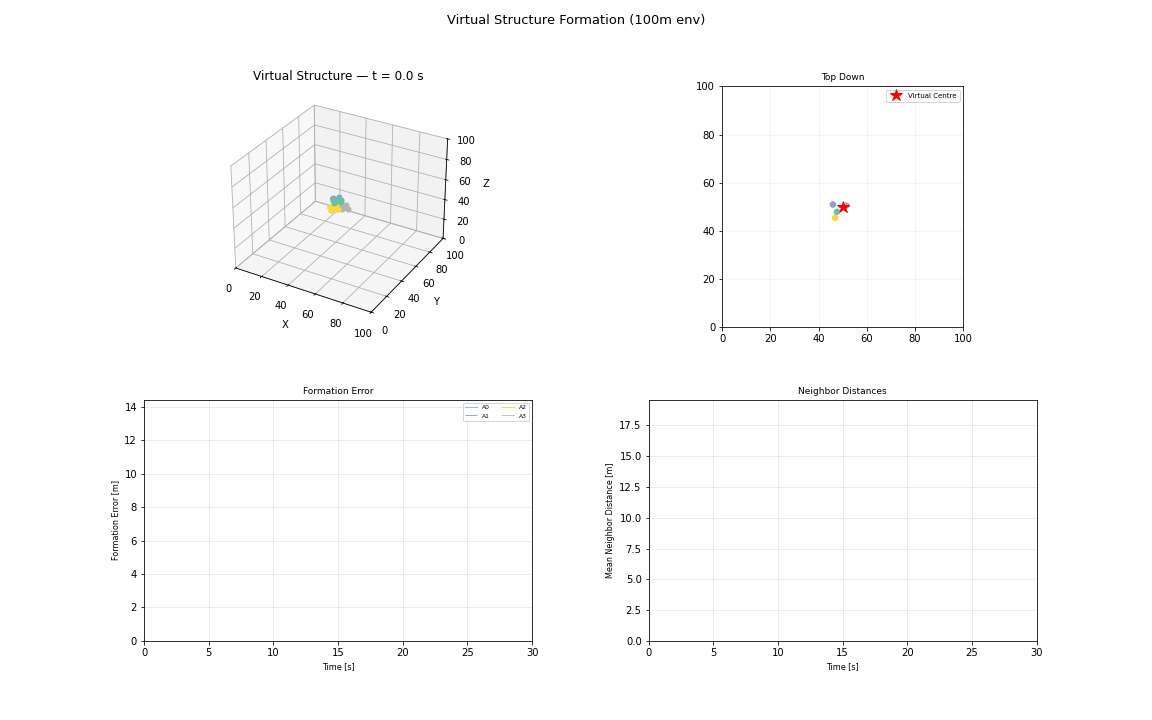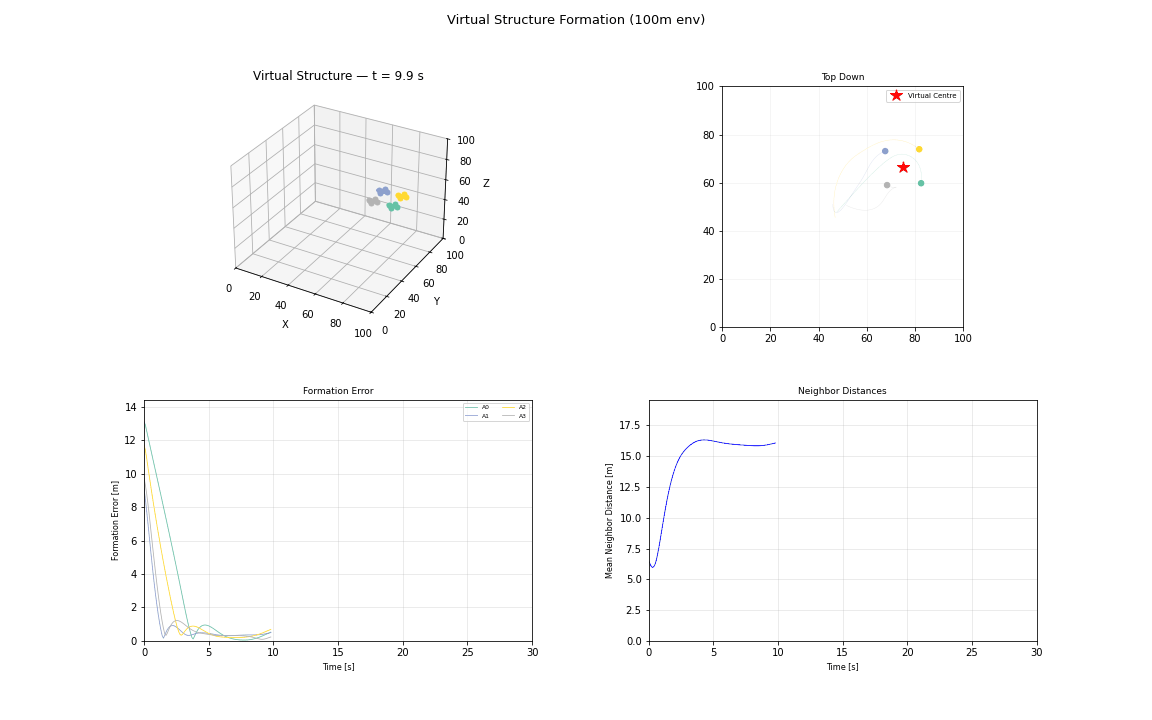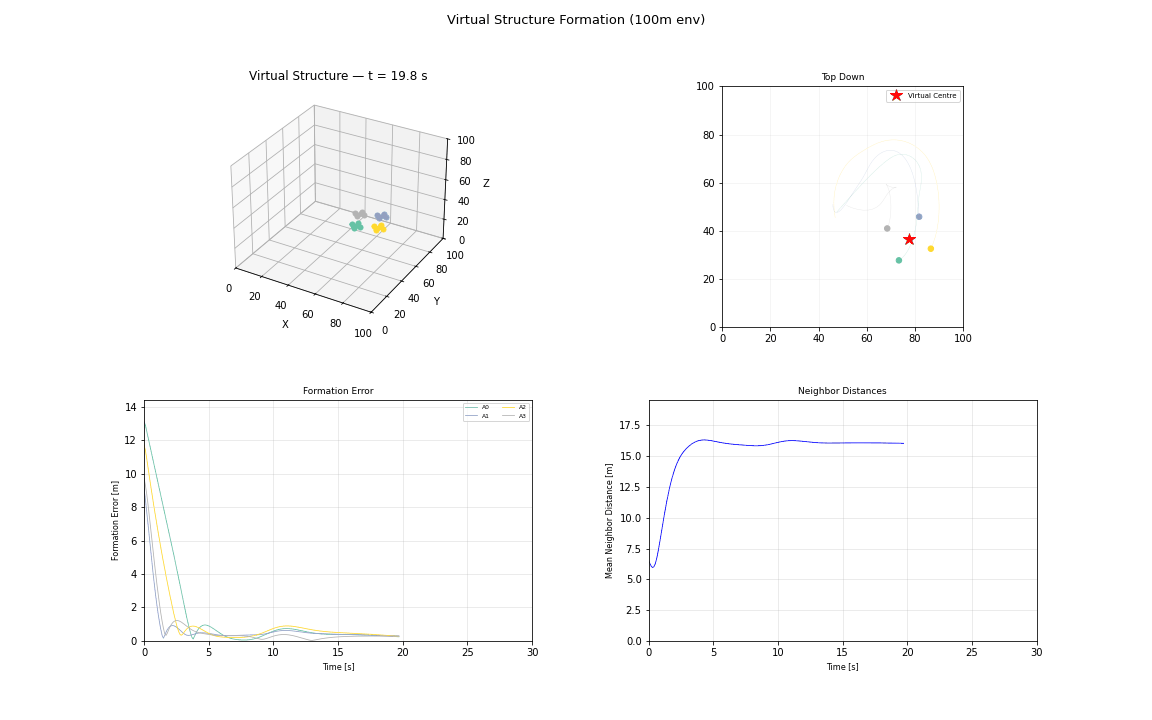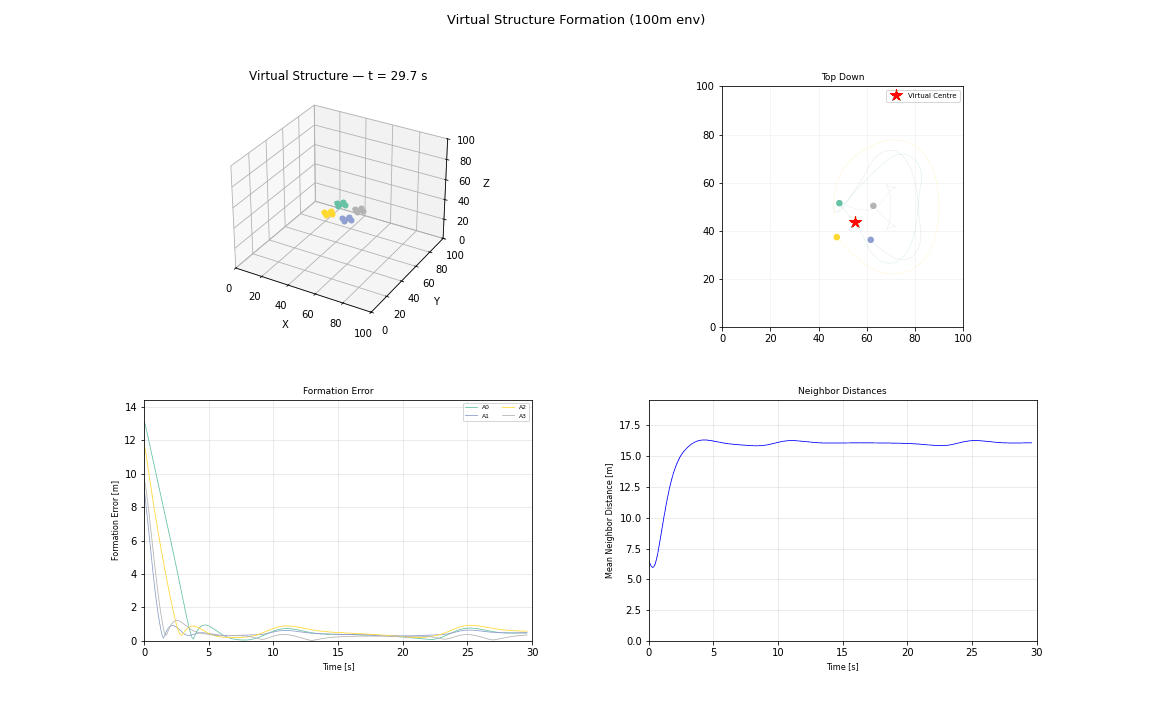 |
| Leader-follower | Open | 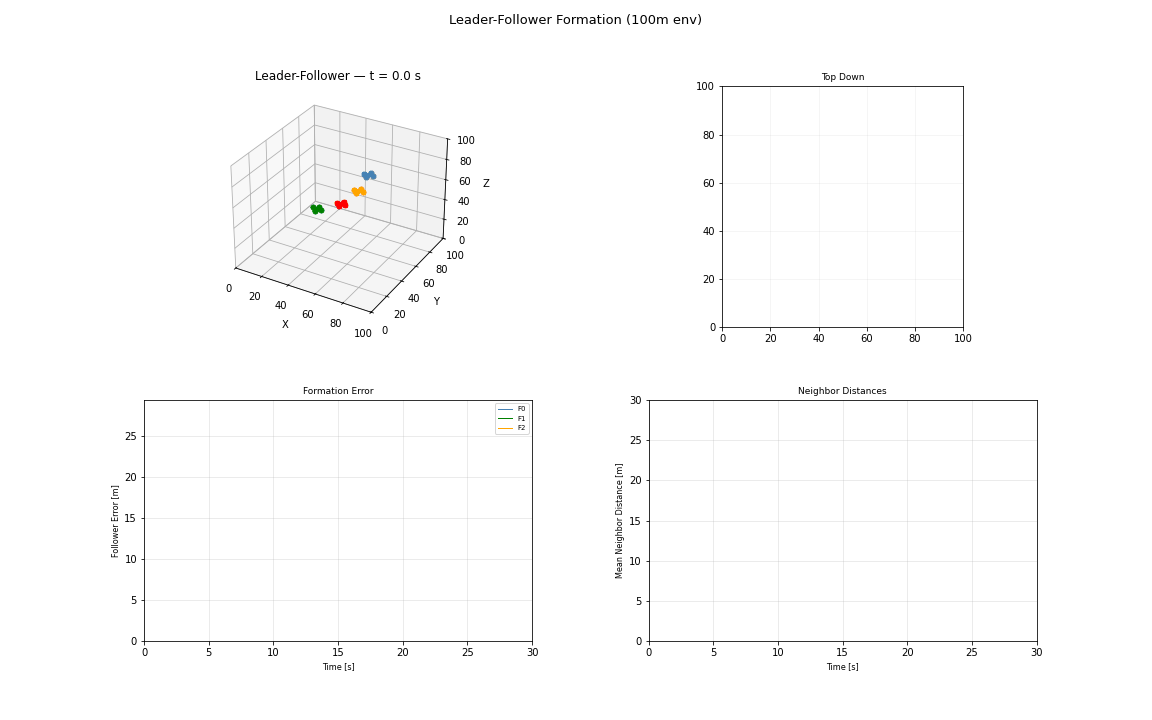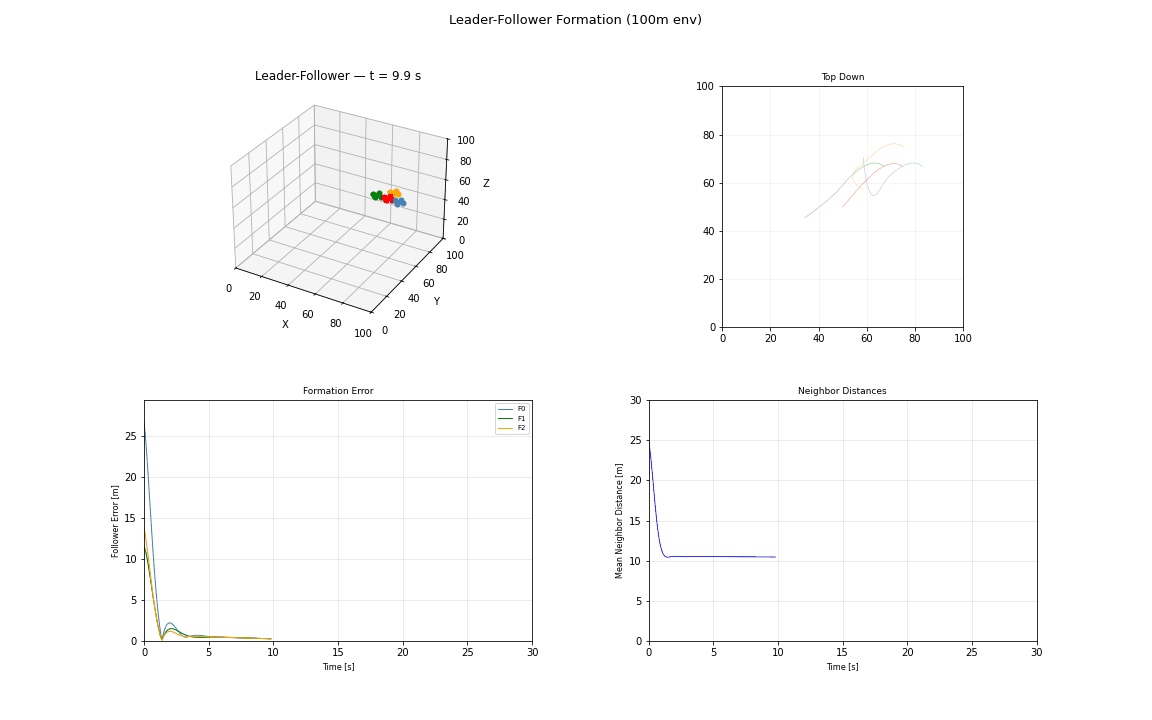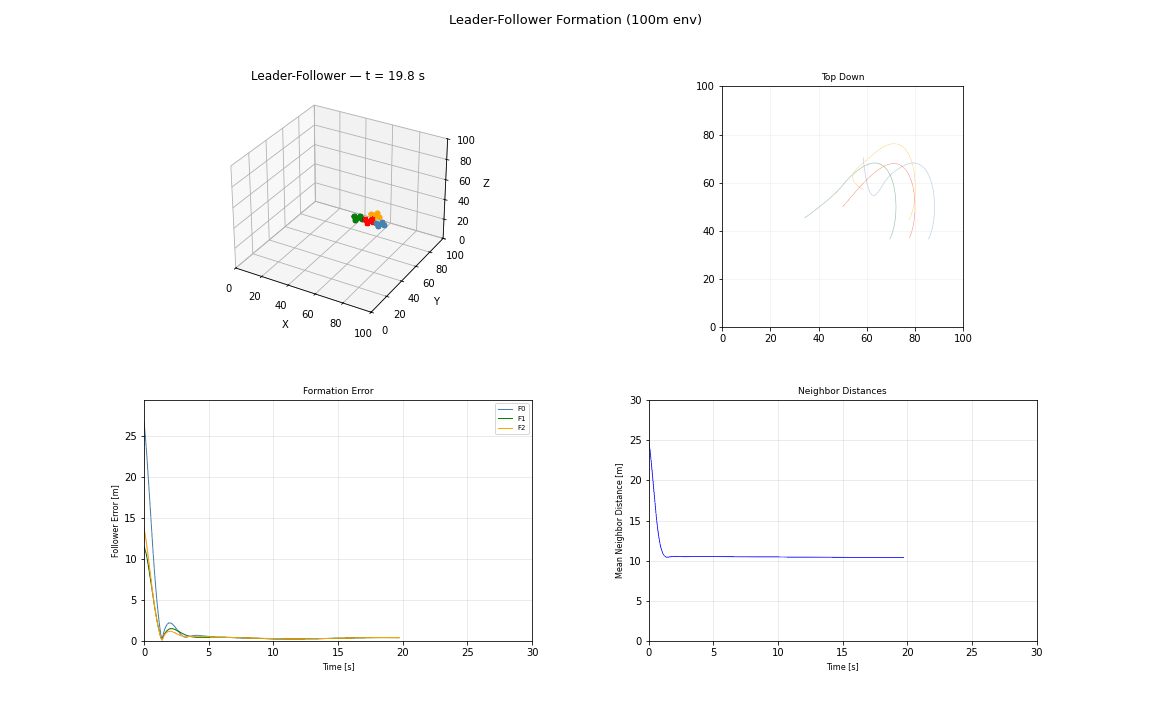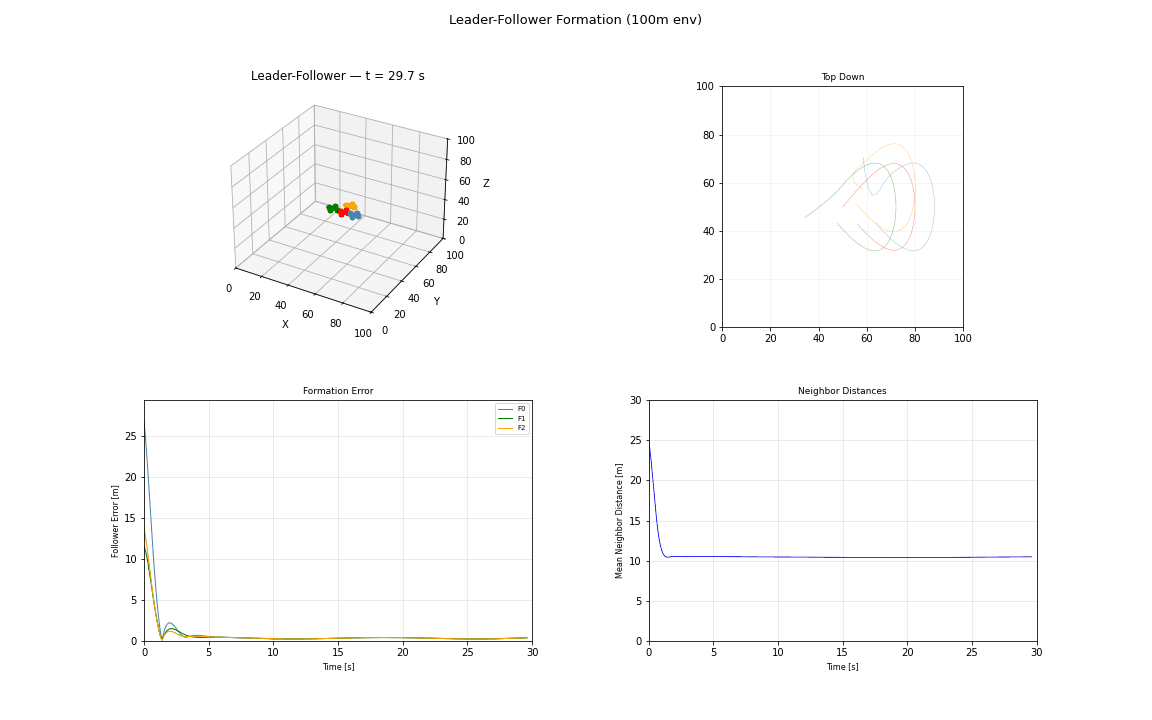 |
| Potential swarm | Open |  |
| Voronoi coverage | Open |  |
Communications
The radio network as part of the plant rather than an assumption.
| Algorithm | Article | Preview |
|---|---|---|
| Connectivity maintenance | Open | 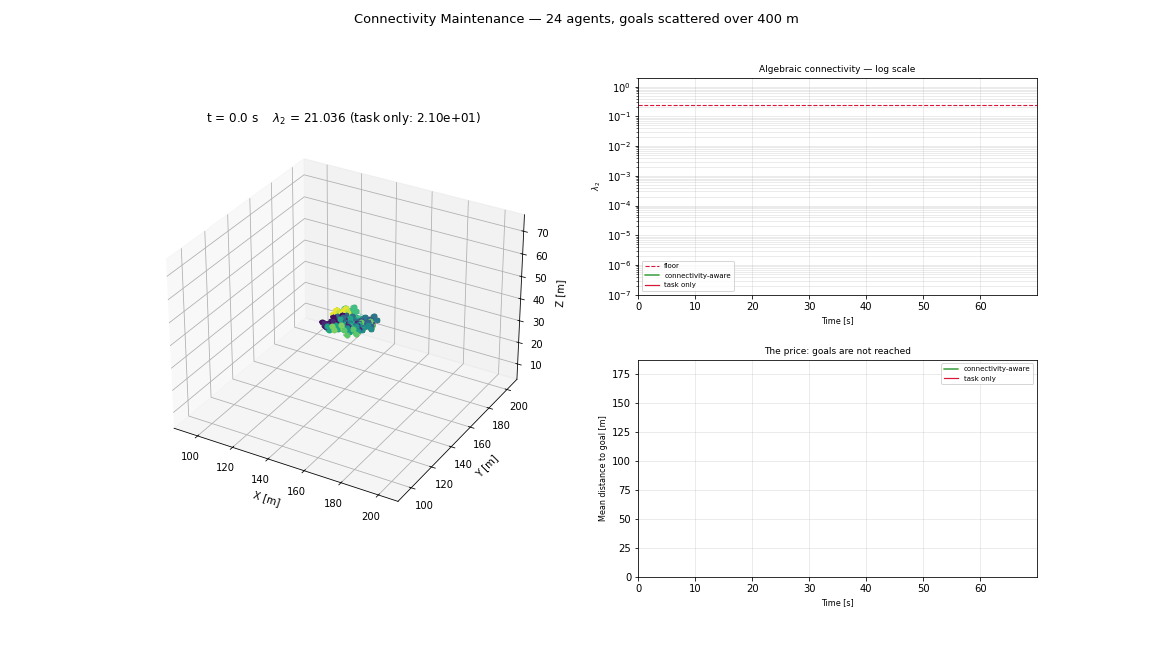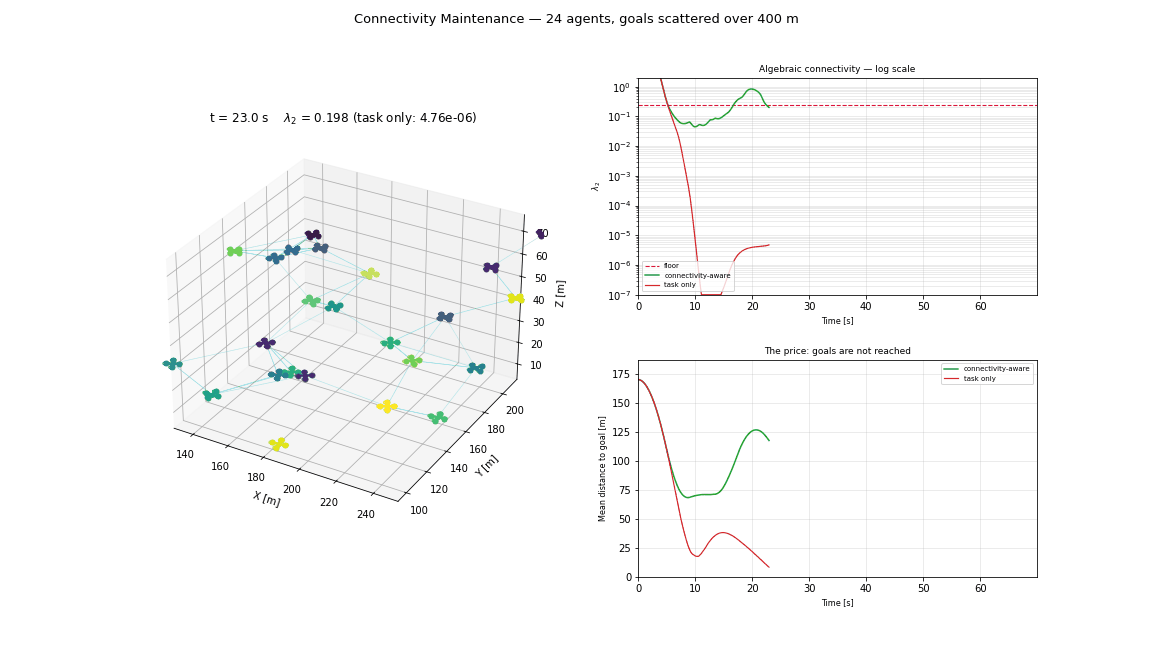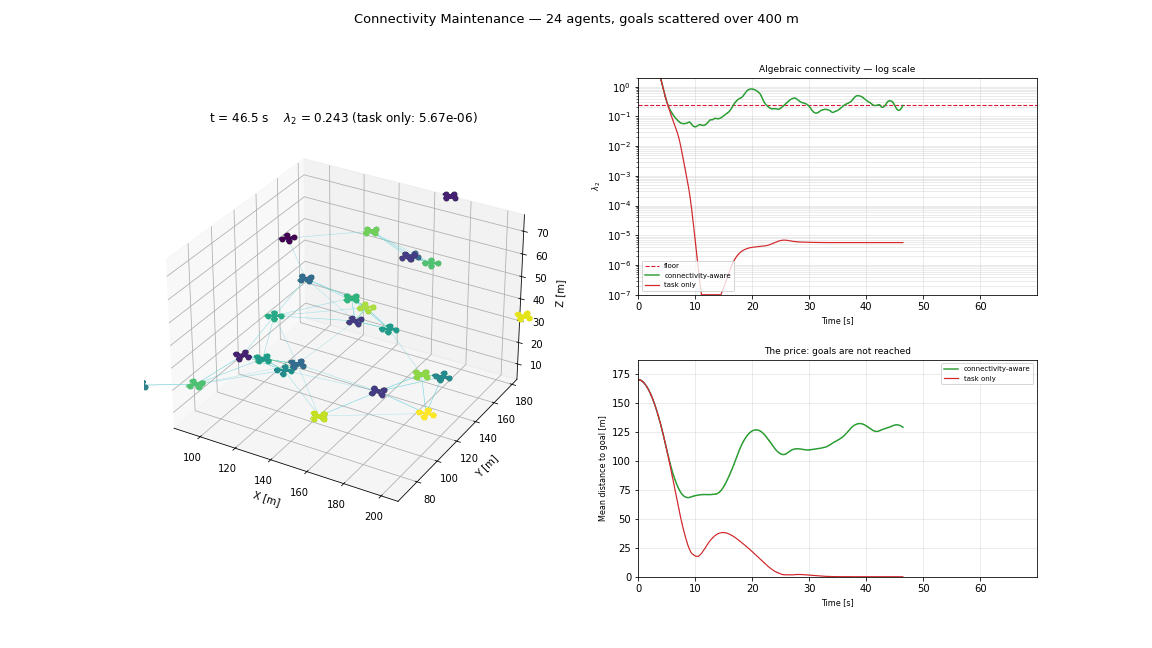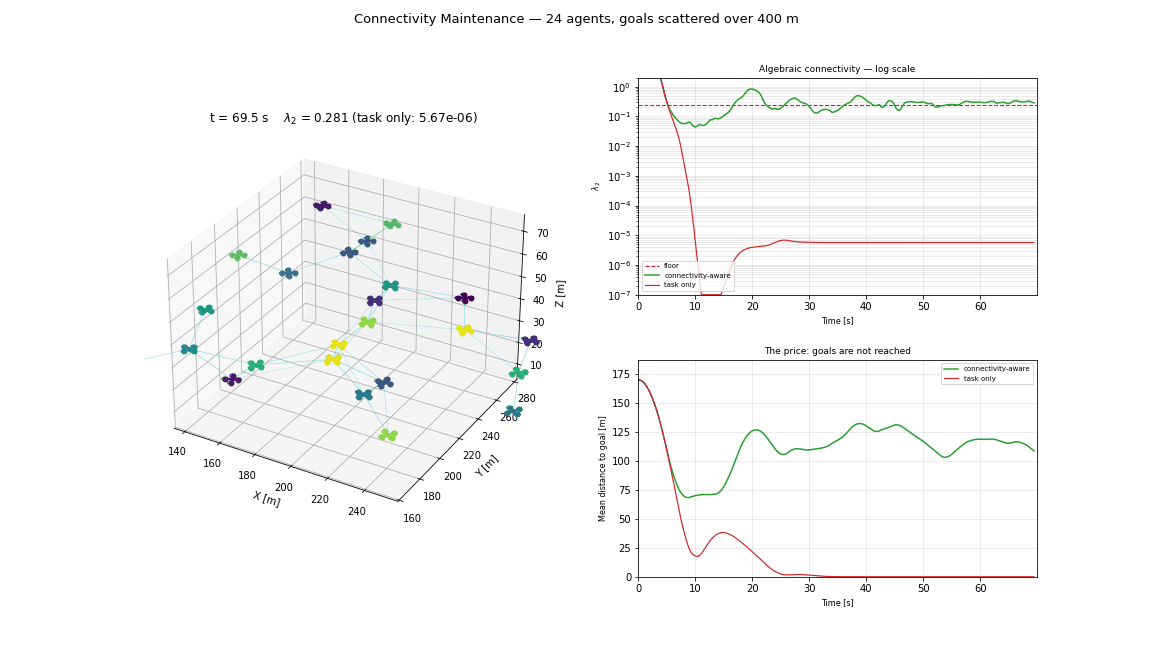 |
| Relay coverage | Open | 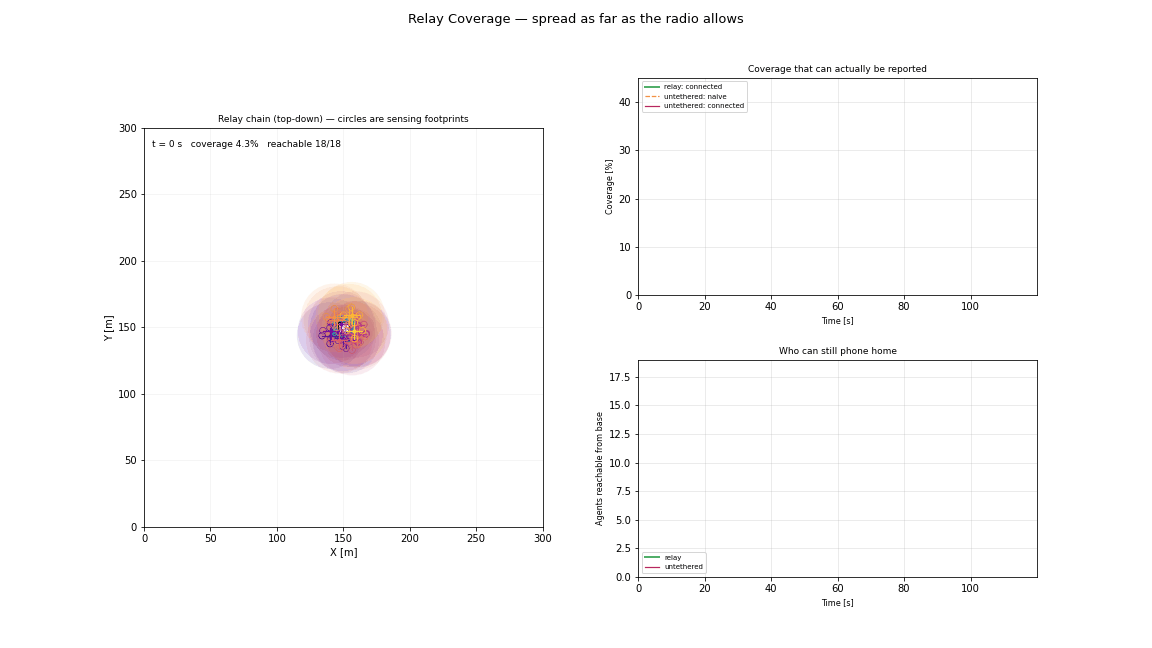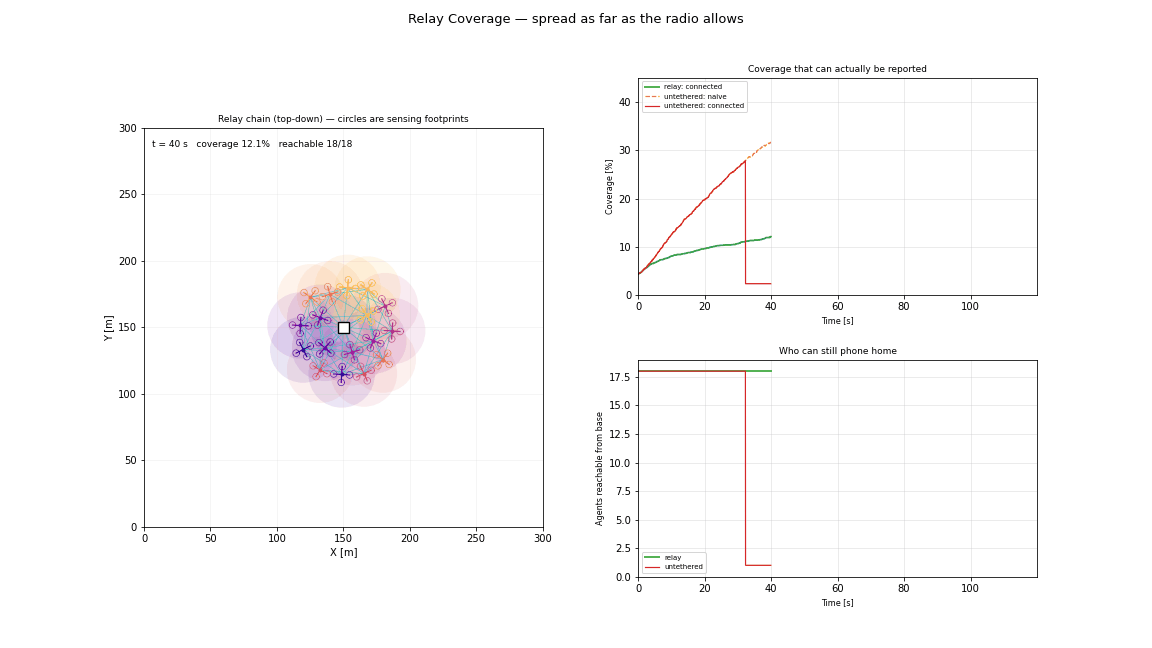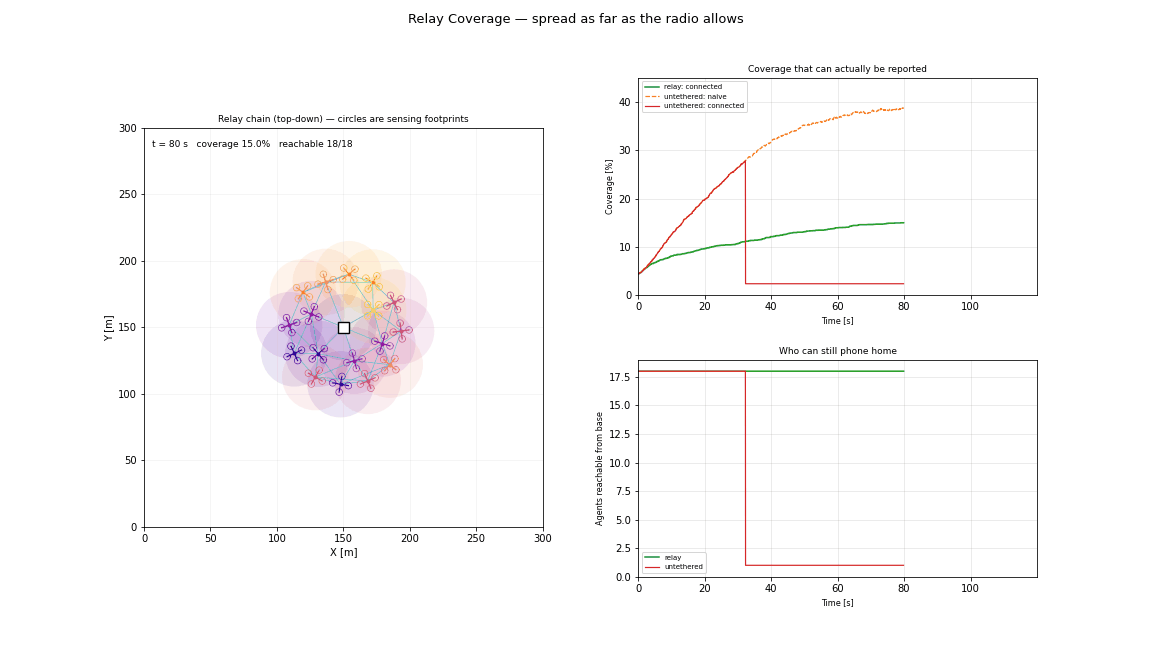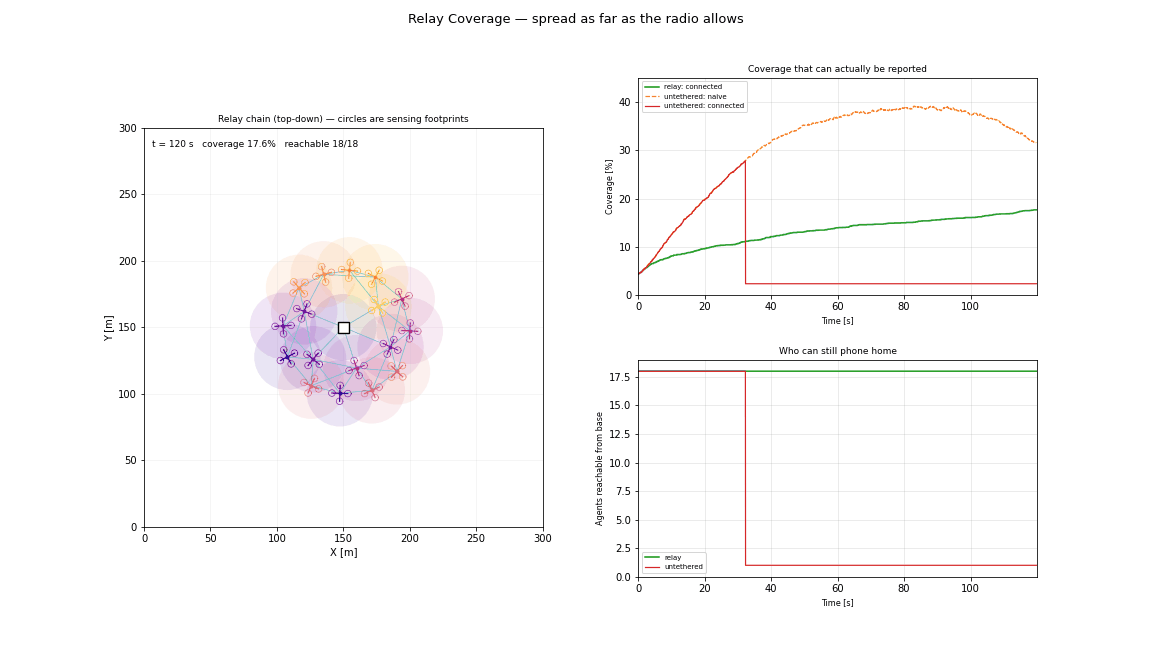 |
| Resilient mesh | Open | 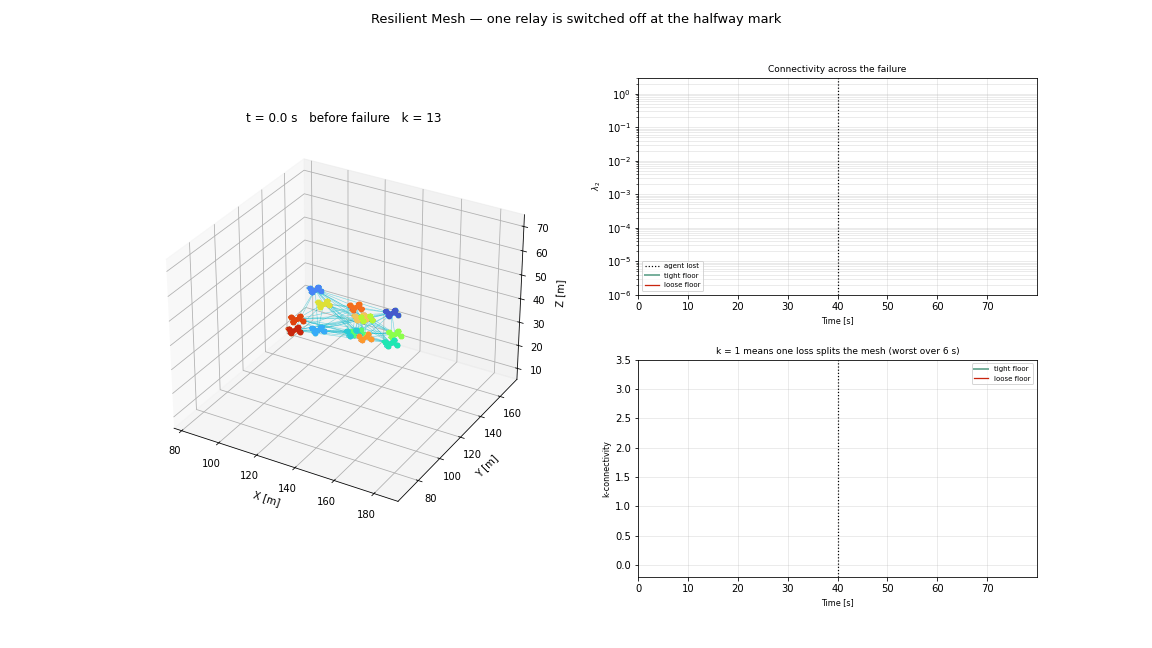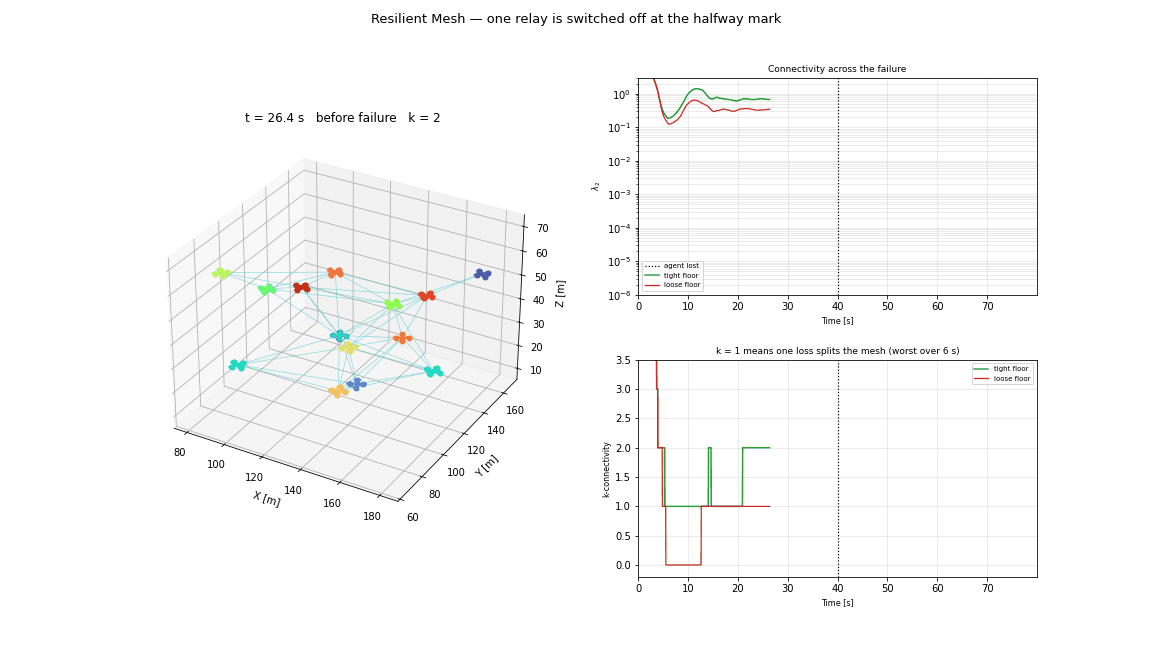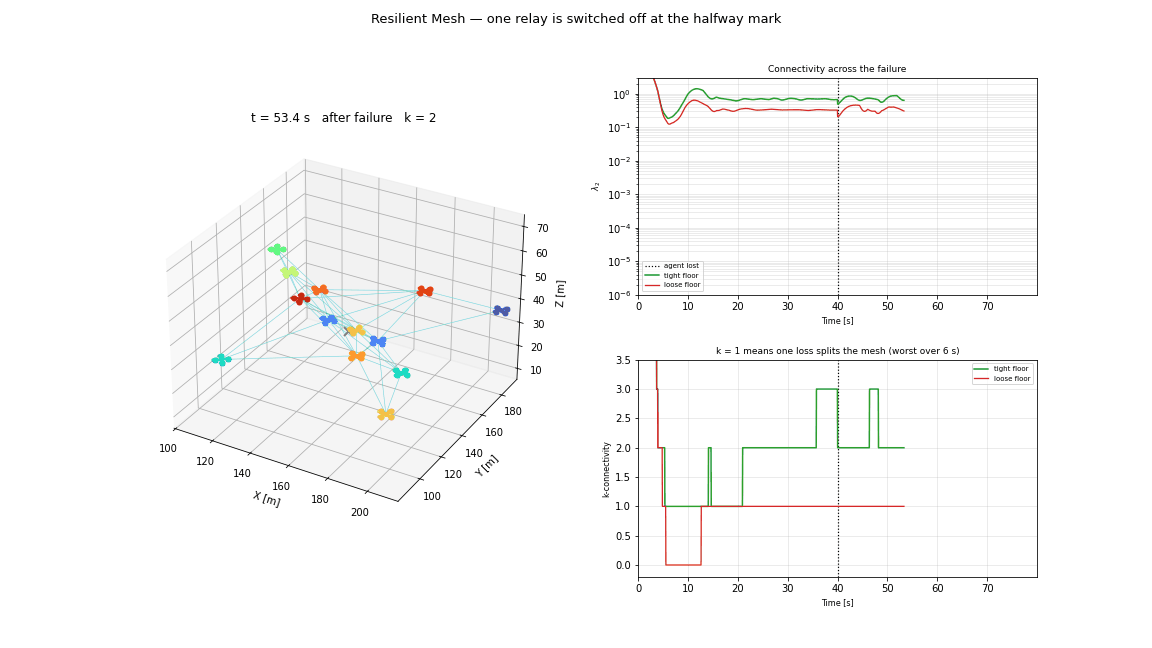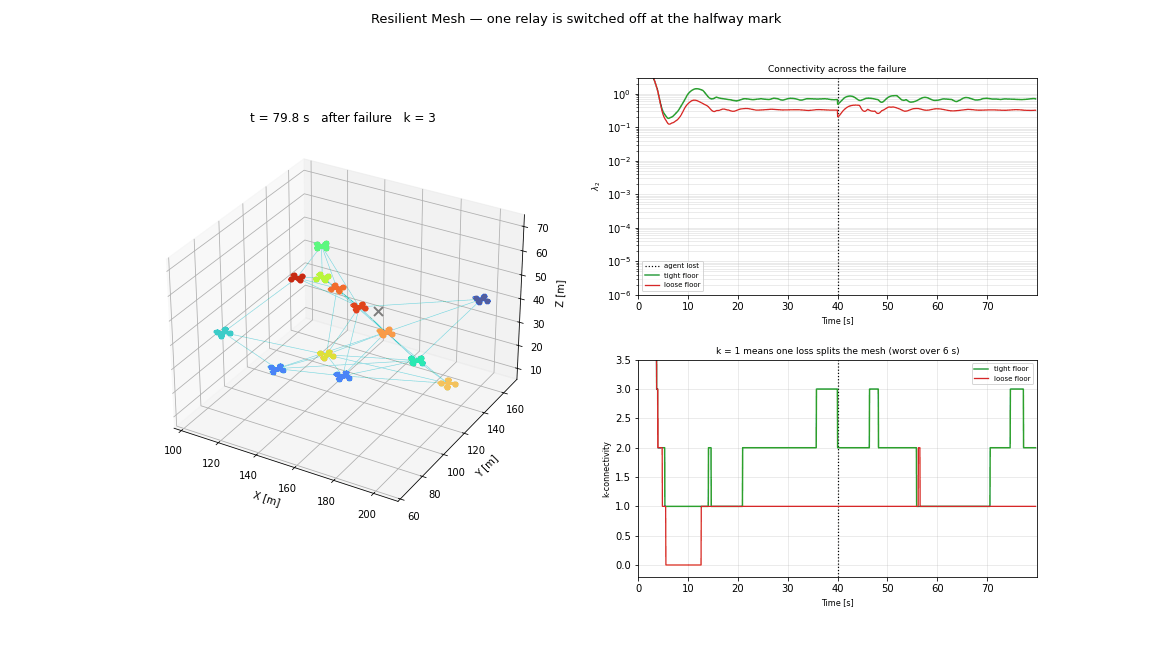 |
| Link budget | Open |  |
| Convoy escort | Open | 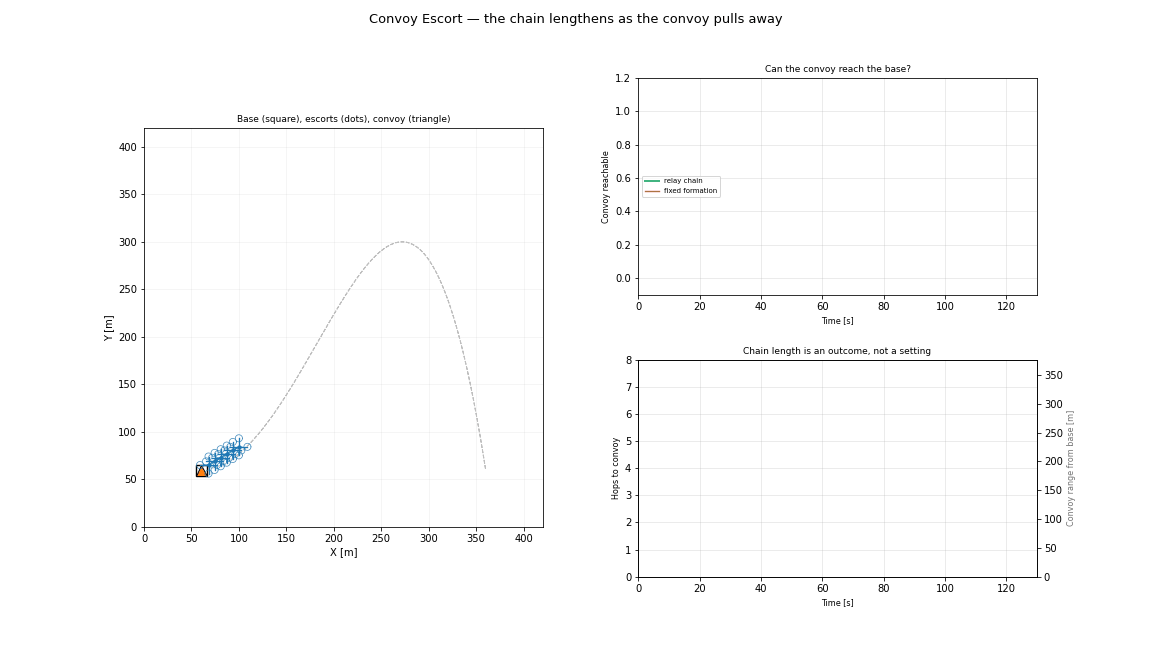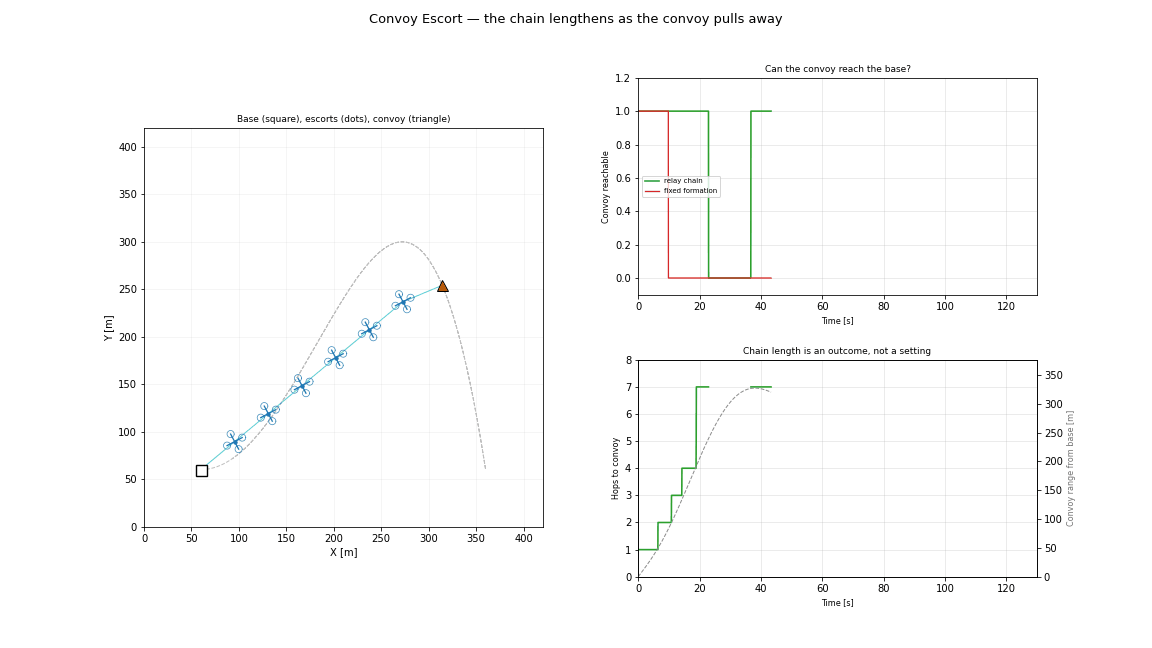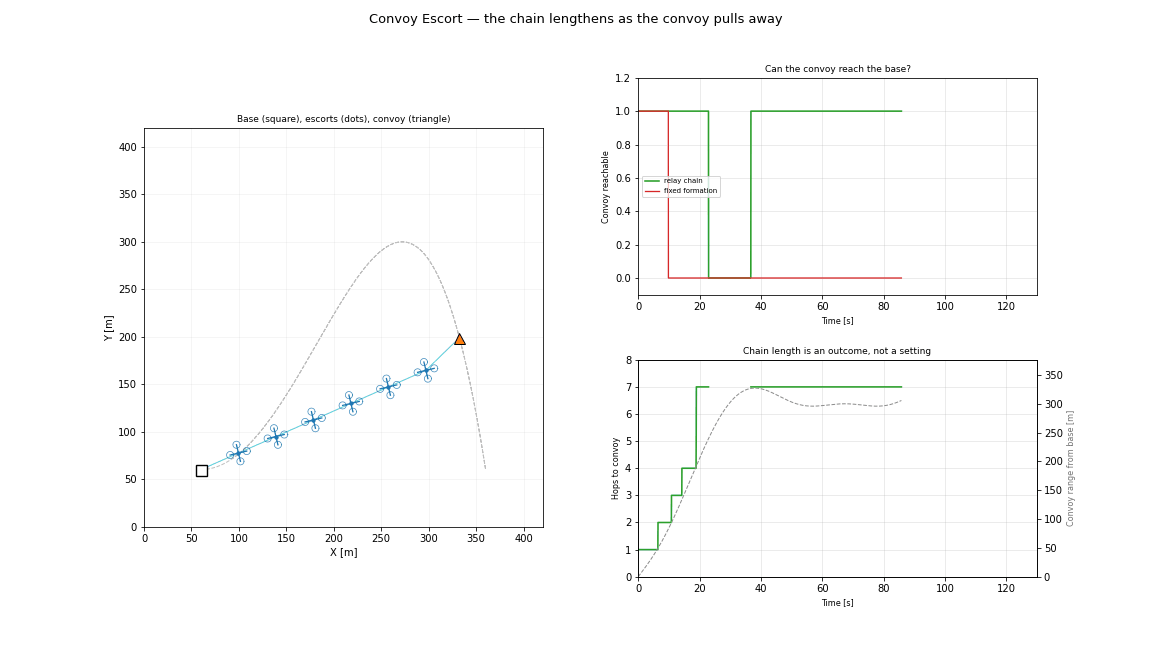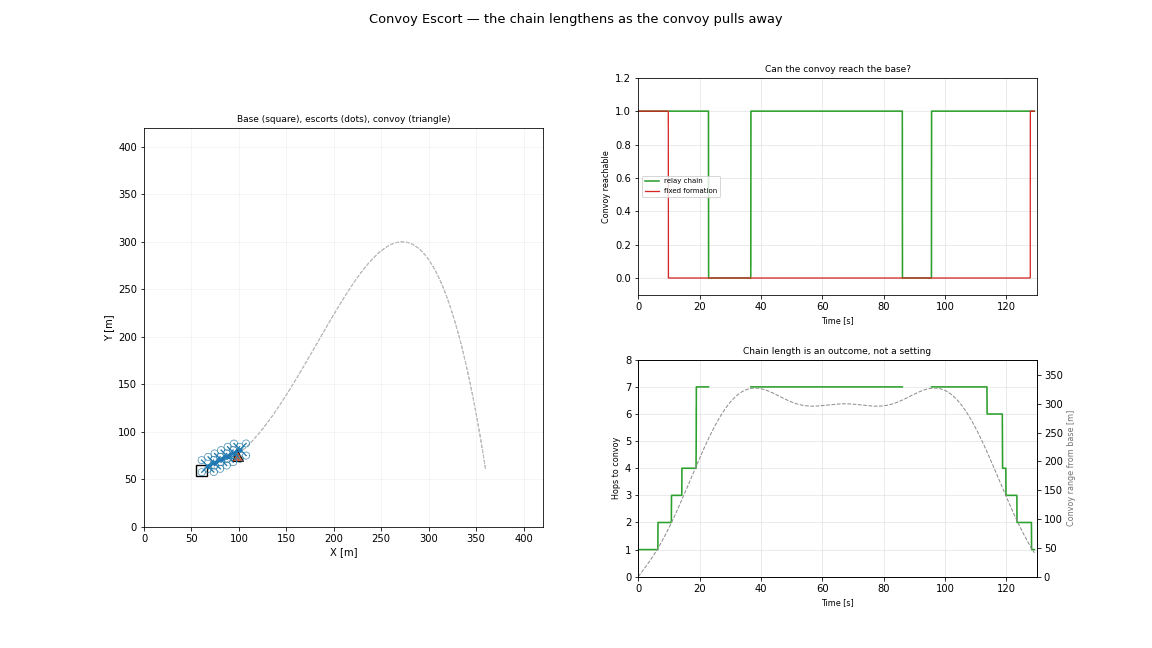 |
Safety
Barriers that edit a controller's command rather than replacing it.
| Algorithm | Article | Preview |
|---|---|---|
| Position exchange (CBF) | Open | 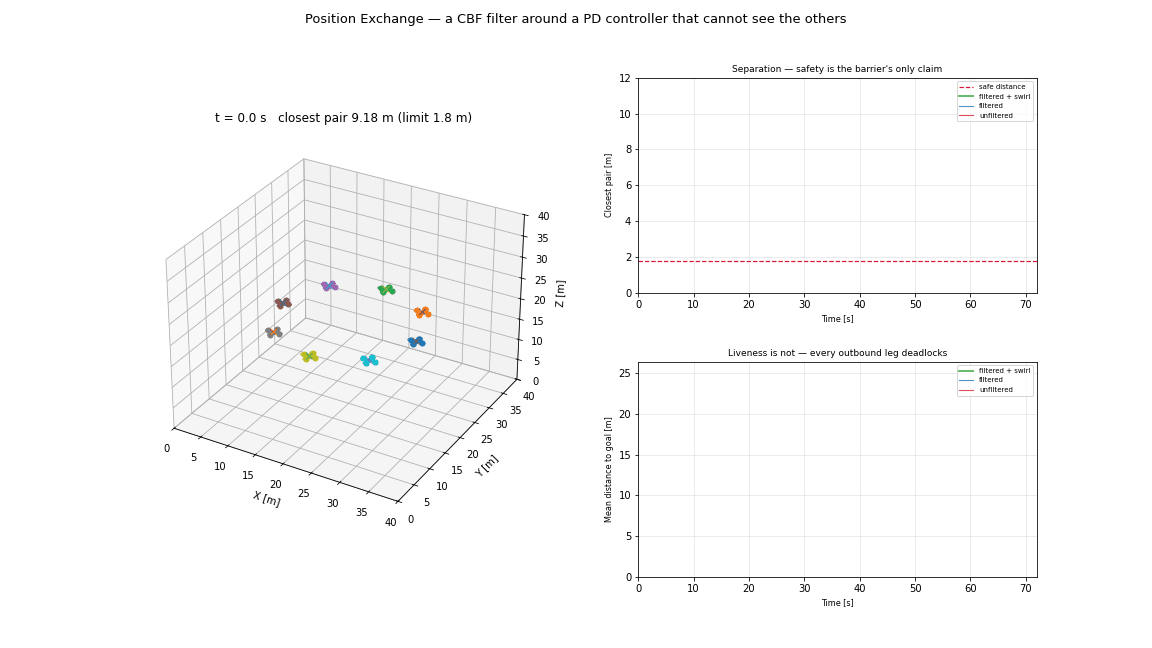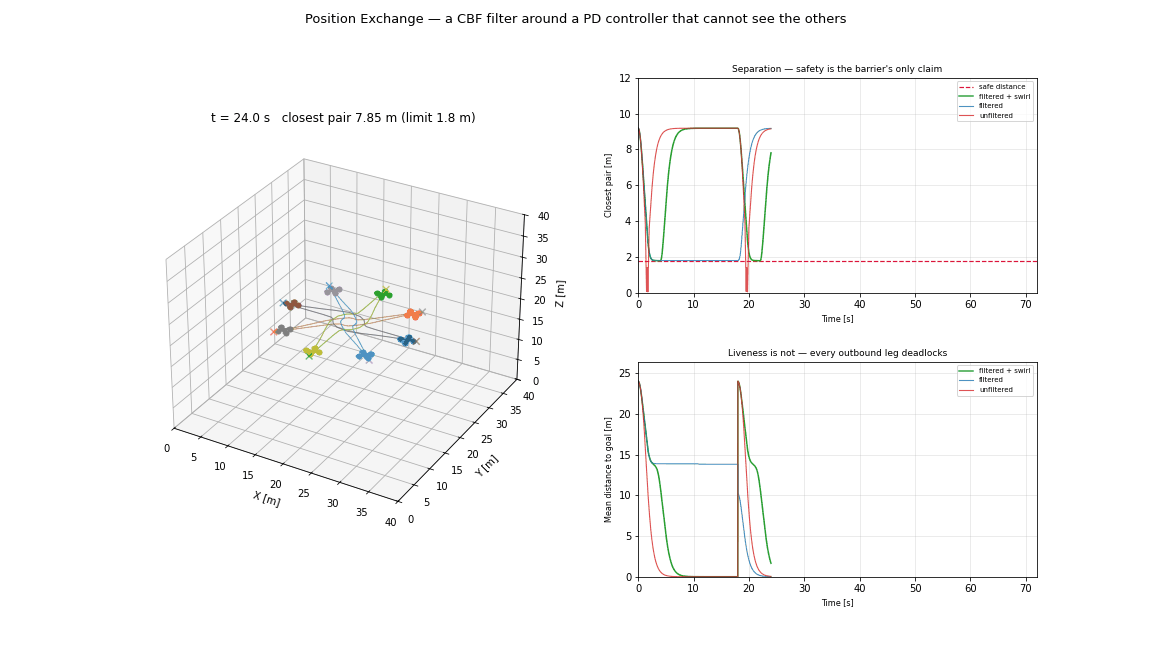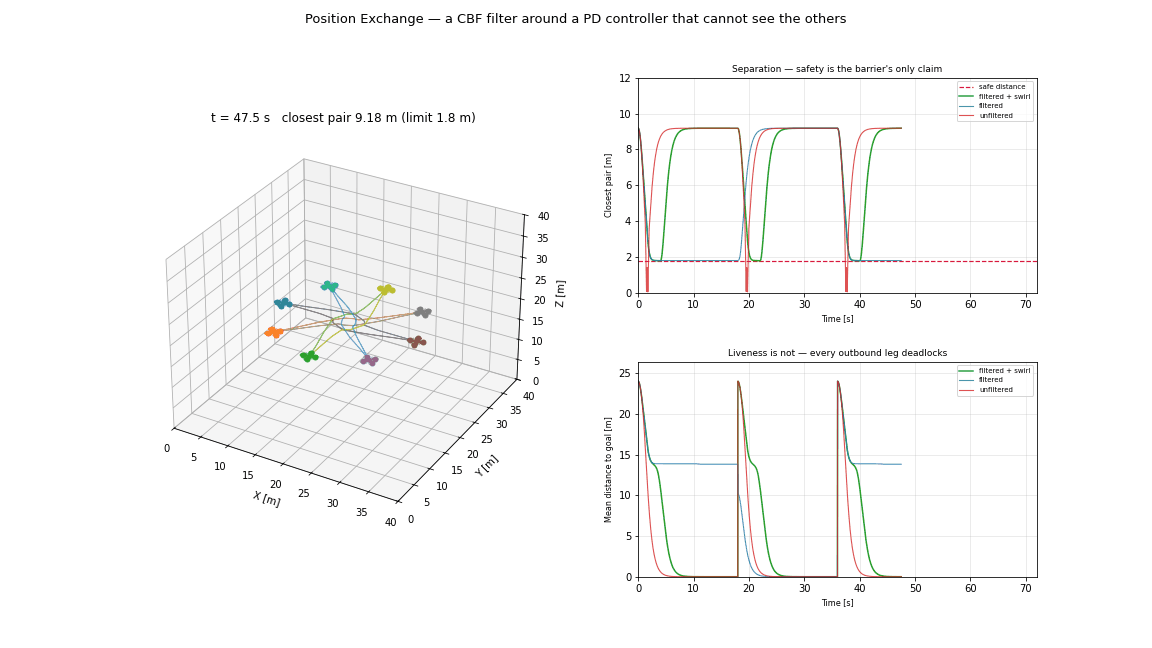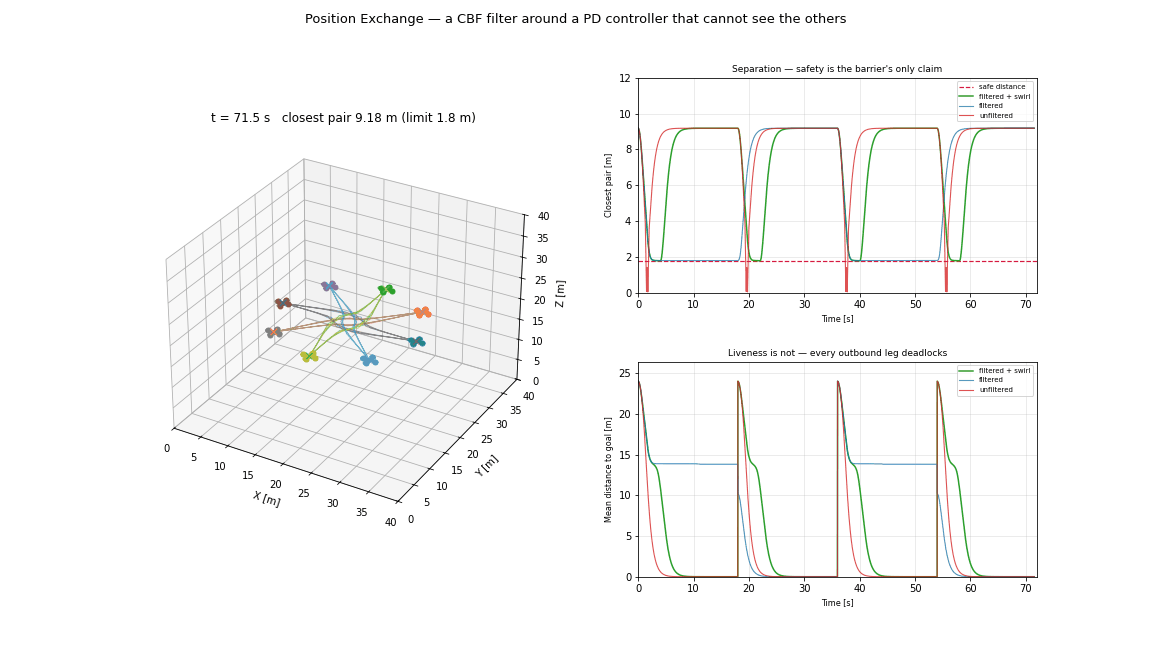 |
| Obstacle slalom | Open | 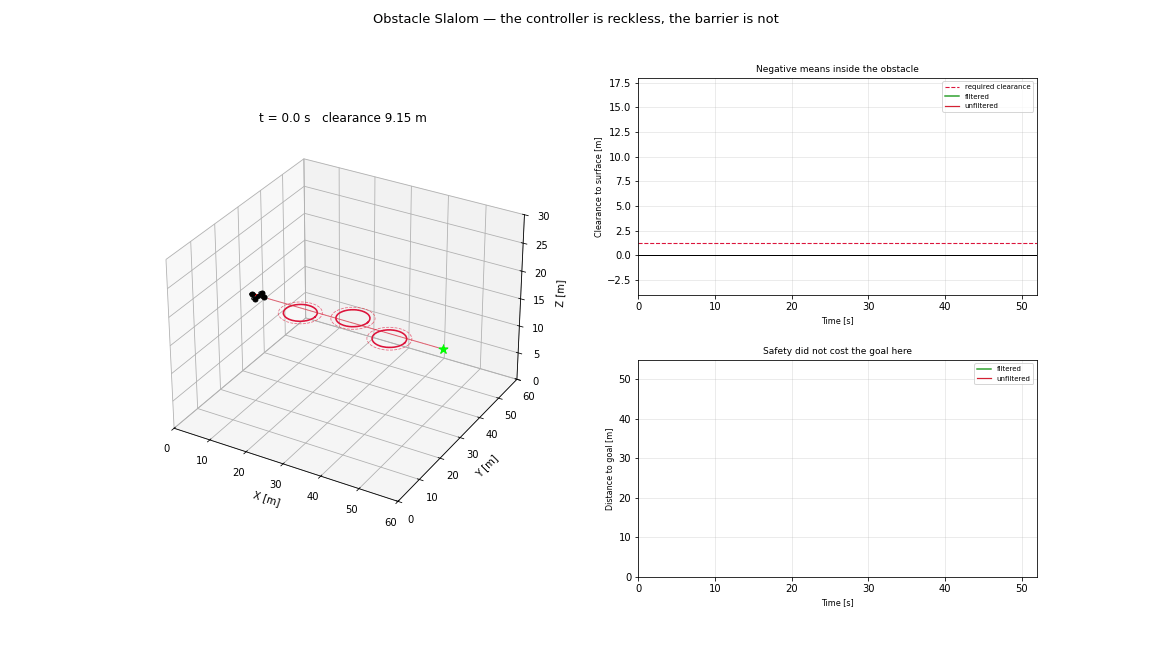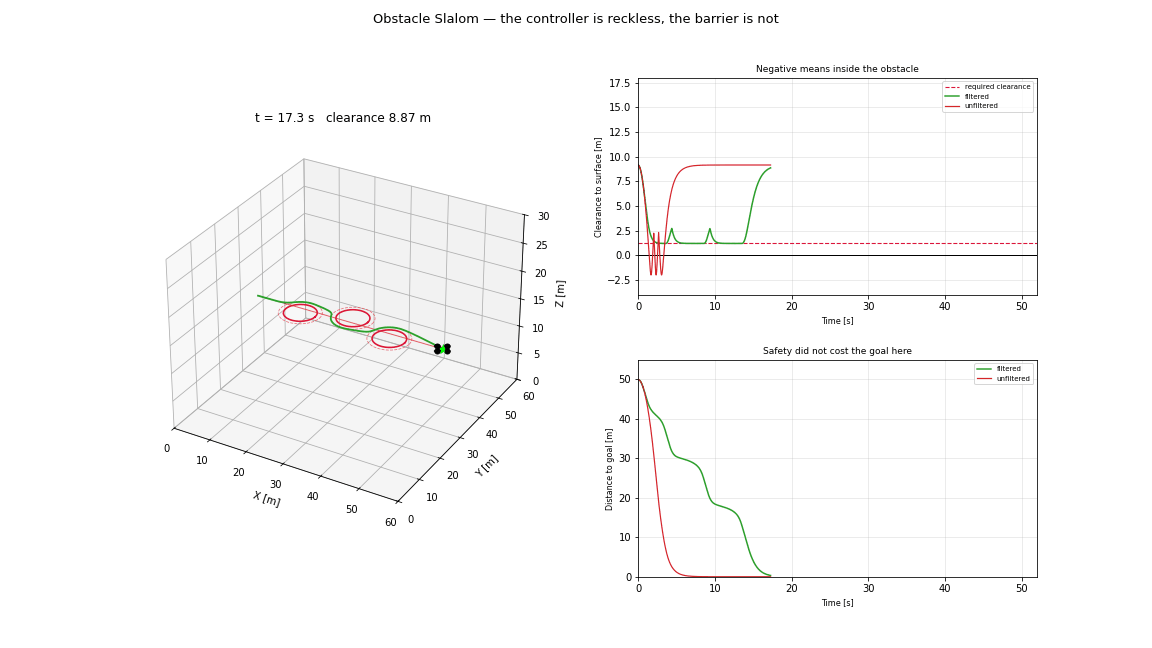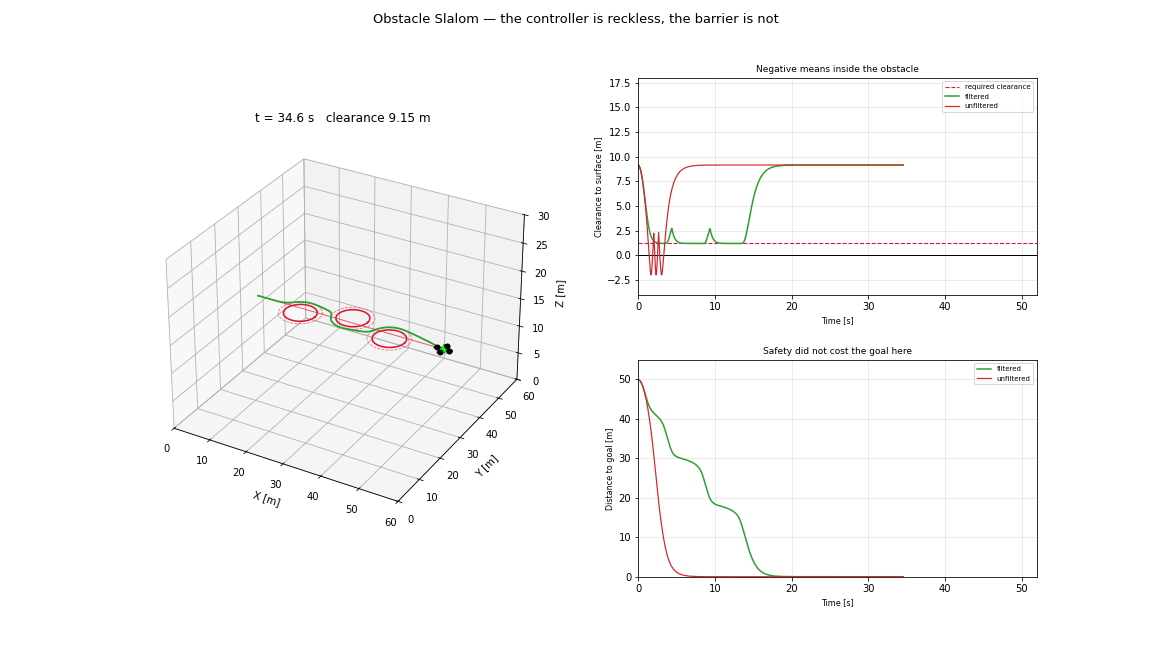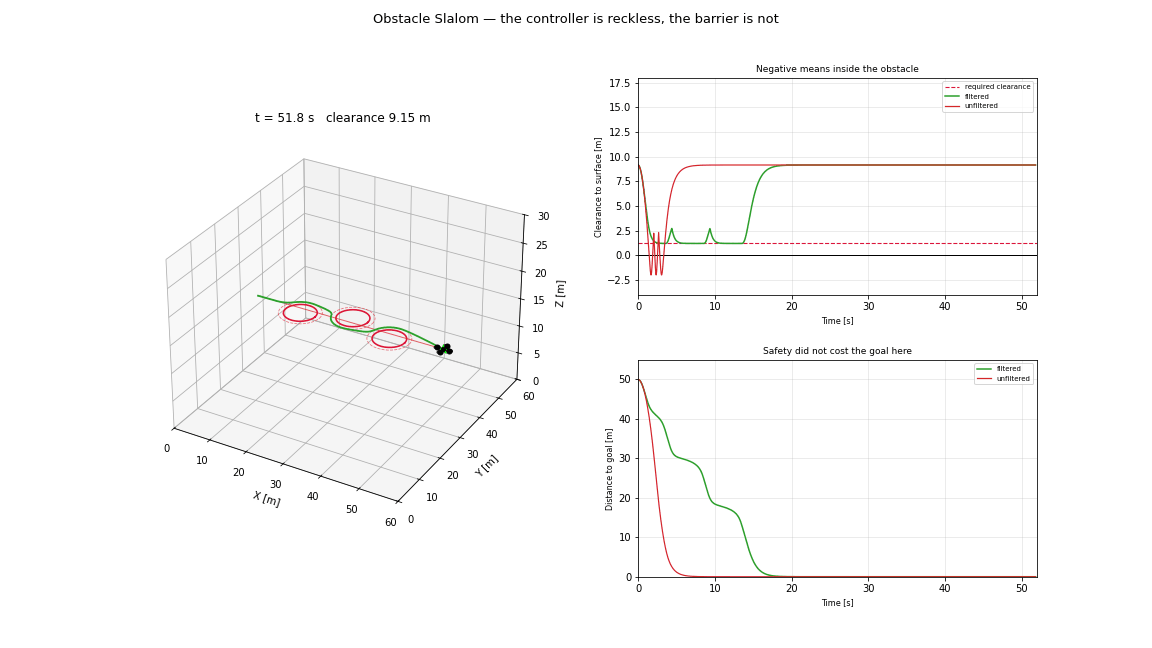 |
| Connectivity annulus | Open |  |
| Geofence and floor | Open |  |
Reinforcement learning
Not simulations but environments — see Reinforcement learning for the six tasks and the trainer.
Notes on the previews
Preview GIFs are stored in Git LFS and served through media.githubusercontent.com. Regenerate any of them locally with flybots run <name>; they are written next to the simulation's run.py.