
Potential Field 3D
Problem Statement
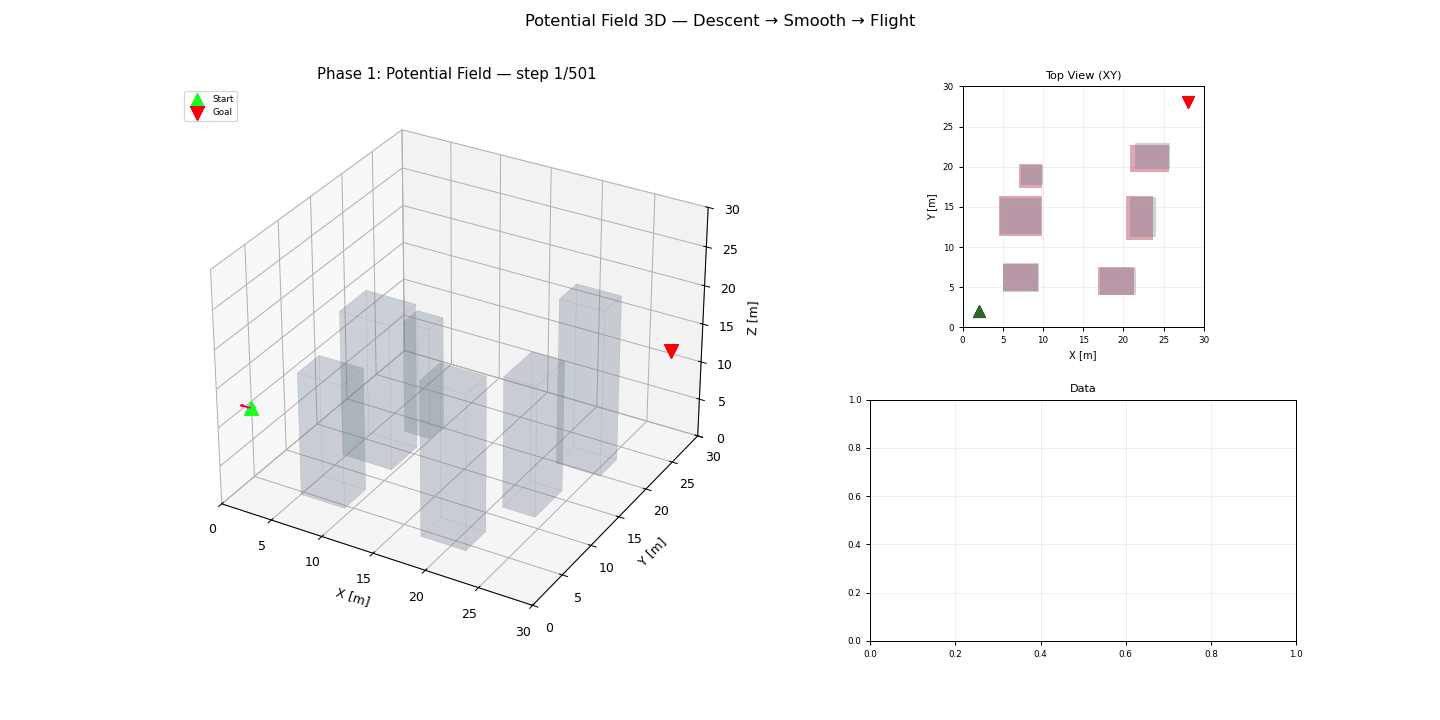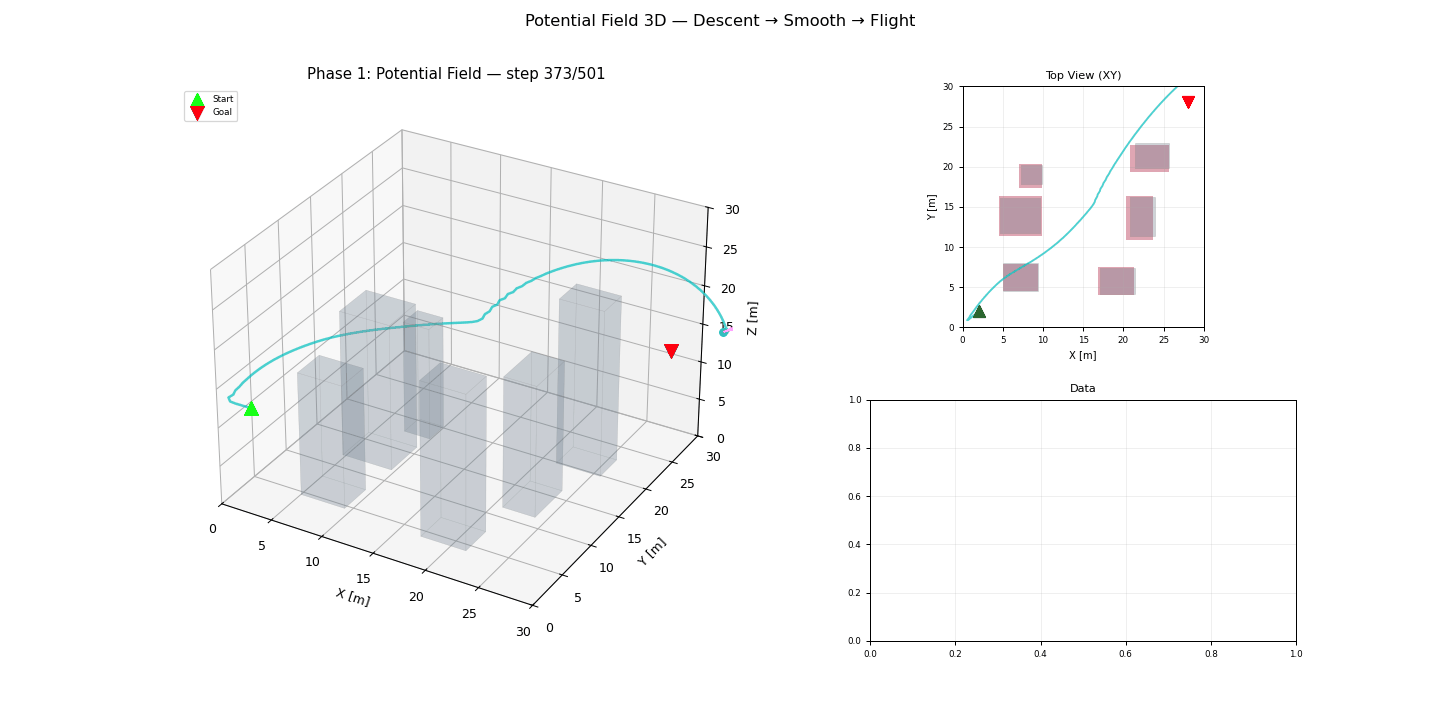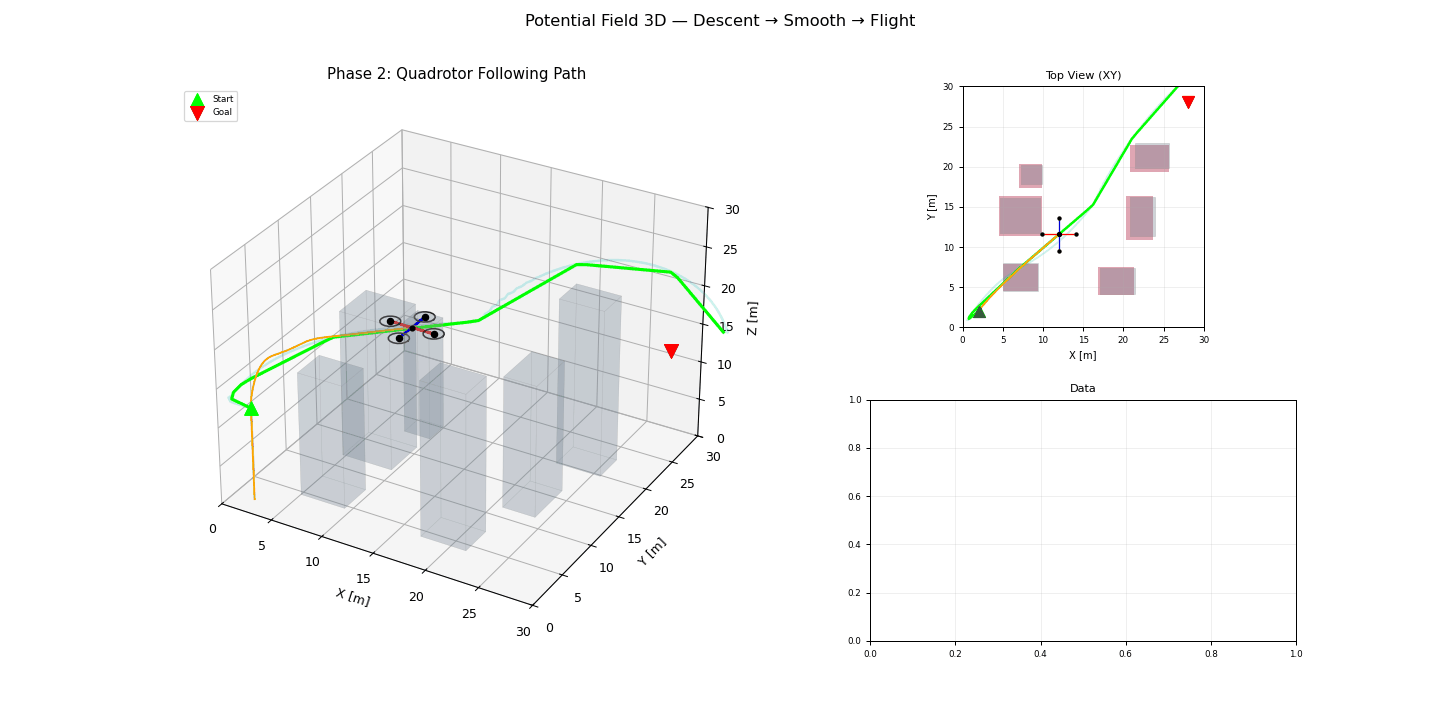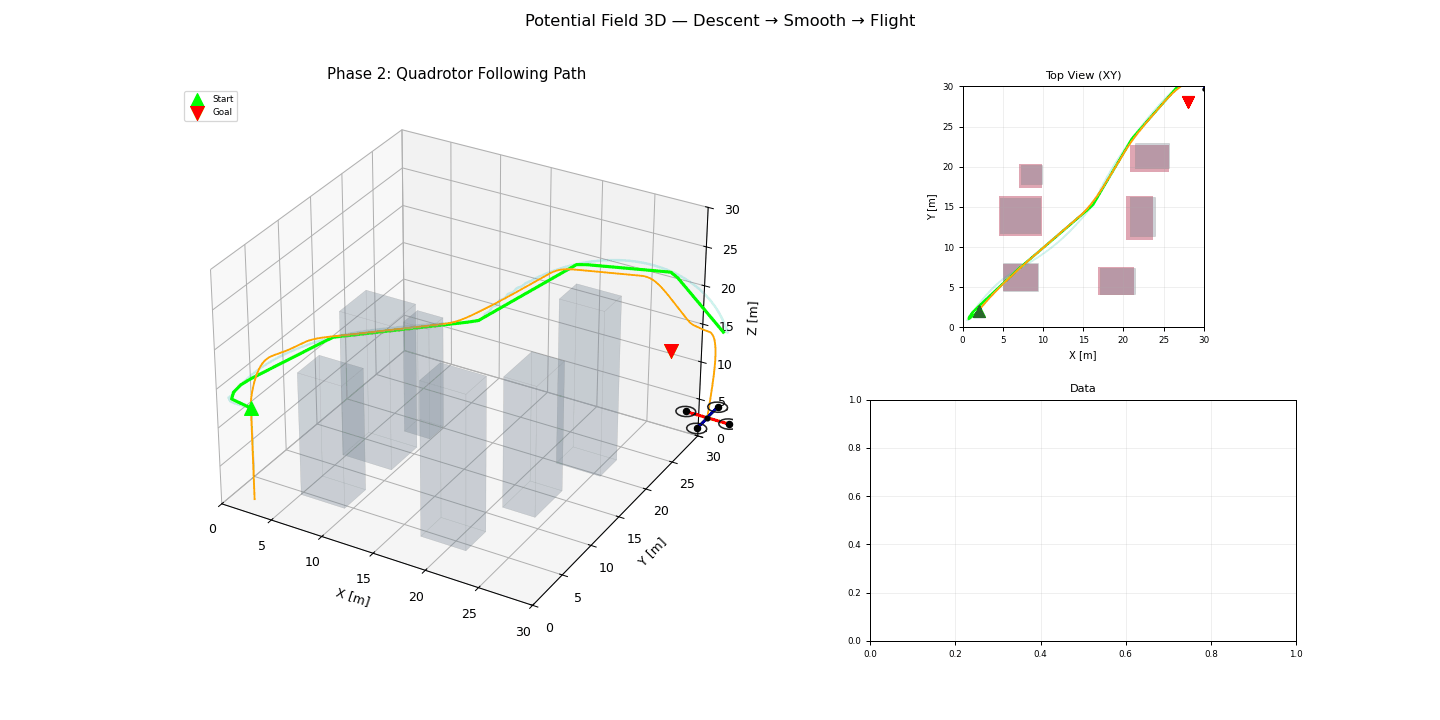
Potential-field planning computes motion by descending a synthetic scalar field that attracts toward goals and repels from obstacles.
Model and Formulation
Total potential:
Motion command:
Practical Notes
- Very fast and simple for local navigation.
- Sensitive to local minima in cluttered environments.
- Often combined with global planners for robust deployment.
Implementation and Execution
bash
python -m flybots.simulations.path_planning.potential_field_3dEvidence
References
- Khatib, Real-Time Obstacle Avoidance for Manipulators and Mobile Robots (1986)
- Ge and Cui, Dynamic Motion Planning for Mobile Robots Using Potential Field Method