
Coverage Planning
Problem Statement
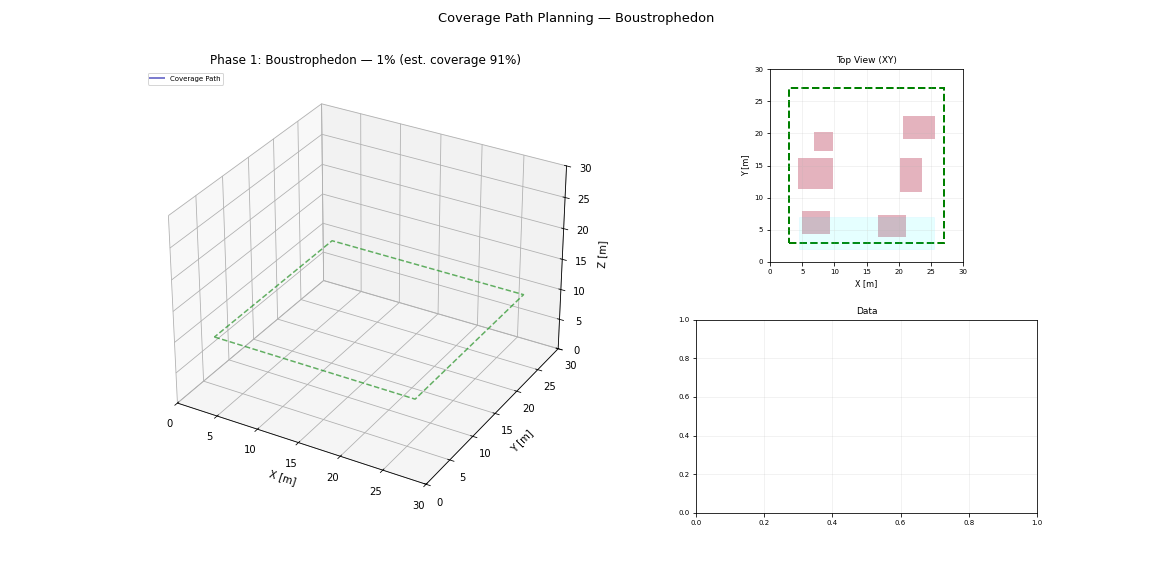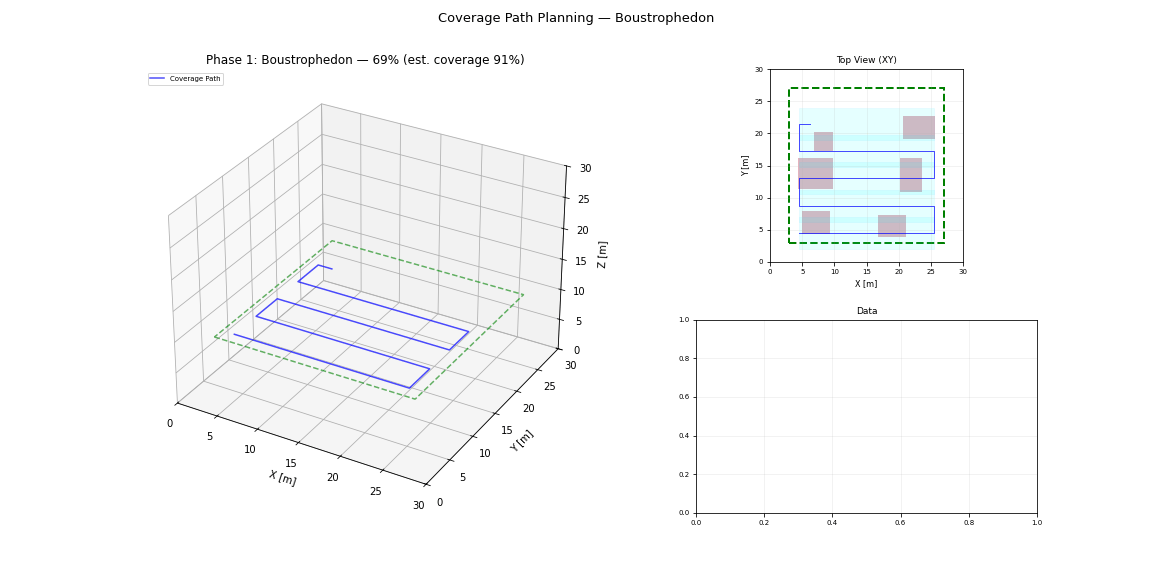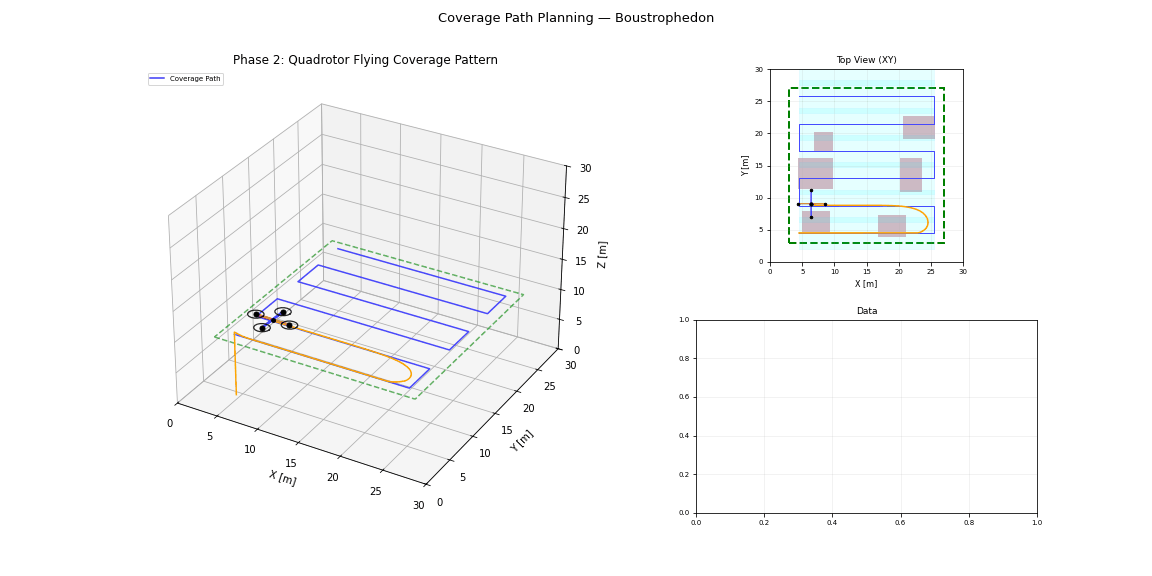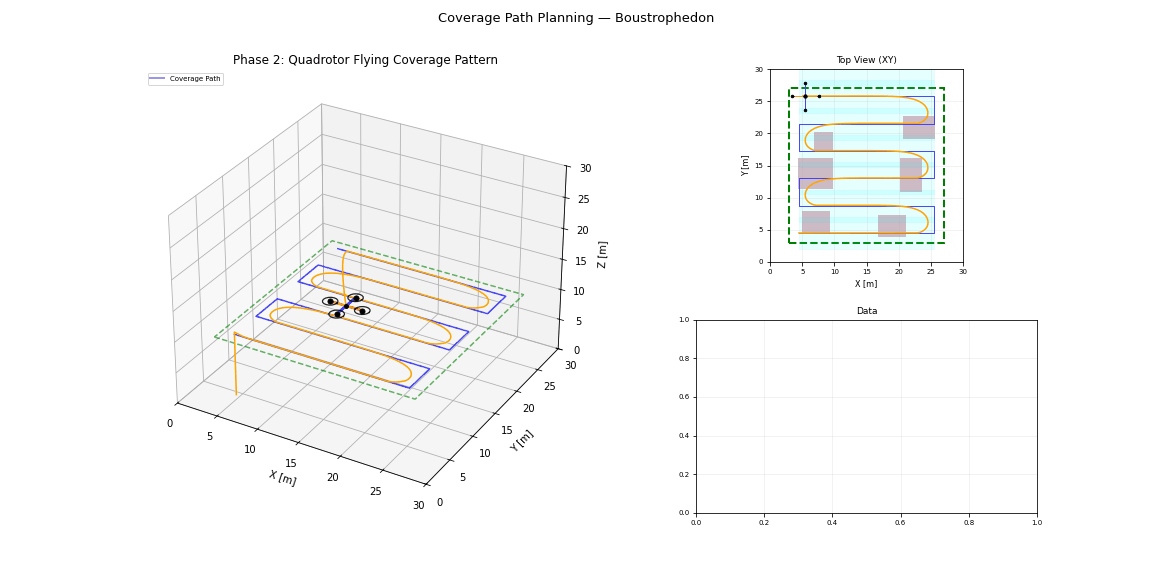
Coverage planning generates paths that guarantee spatial visitation for inspection, mapping, or search missions.
Model and Formulation
Coverage objective:
subject to vehicle dynamics, footprint size, and mission-time constraints.
Practical Notes
- Common decompositions include boustrophedon and grid sweep methods.
- Turn penalties should be considered for fixed-wing platforms.
- Map uncertainty can trigger adaptive revisitation.
Implementation and Execution
bash
python -m flybots.simulations.path_planning.coverage_planningEvidence
References
- Choset, Coverage for Robotics: A Survey (2001)
- Galceran and Carreras, A Survey on Coverage Path Planning for Robotics (2013)